

Product Description
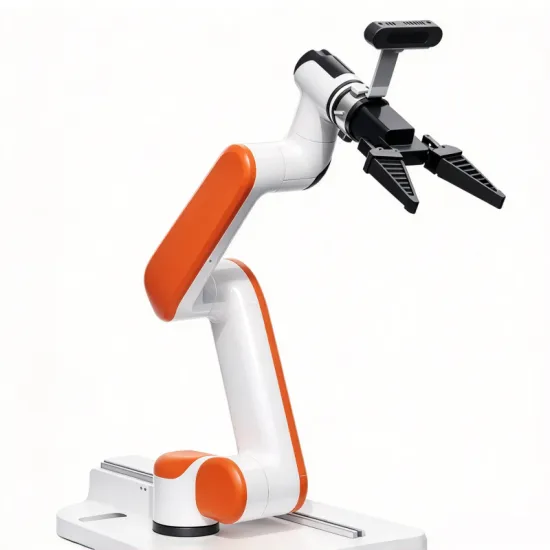
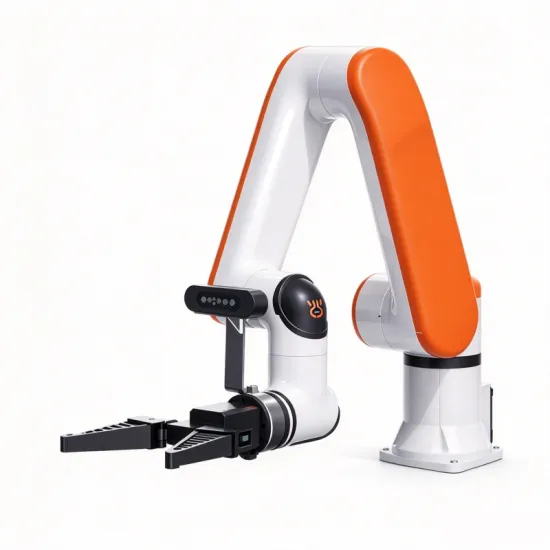
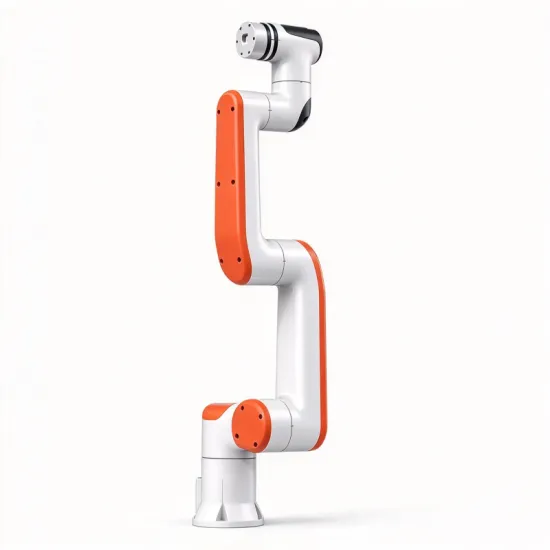
ECO65-6F
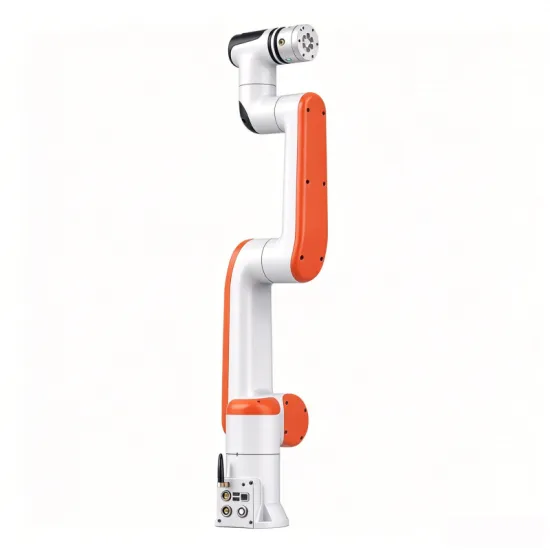
a 6-DOF six-axis force economy robot arm from RealMan.
Arm (incl. controller) weight: 7.9 kg | Rated payload: 5 kg | Working radius: 638.5 mm | Repeatability: ±0.05 mm |
Functional Features
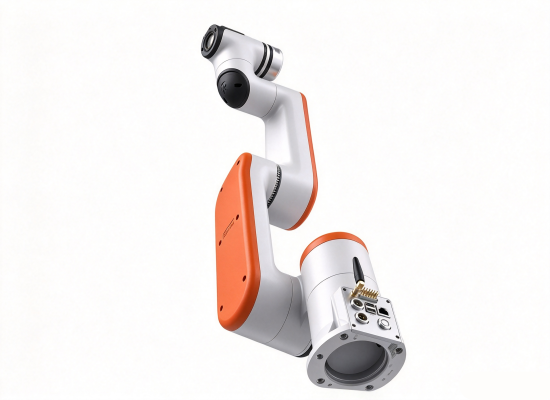
The ECO65-6F is a 6-DOF robot arm independently developed and manufactured by RealMan.
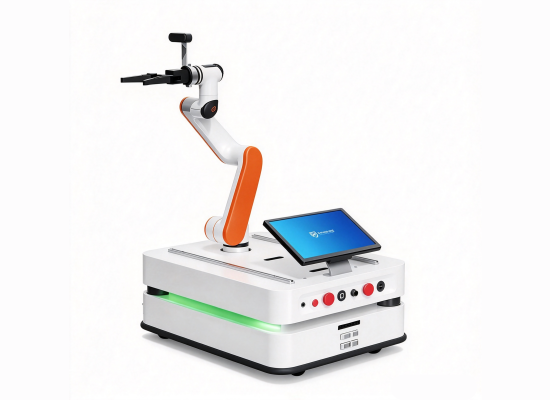
With an integrated control cabinet and a total weight of 7.9 kg, it delivers a 5 kg rated payload (up to 9 kg peak) over a 638.5 mm working radius.
Ontology Parameters
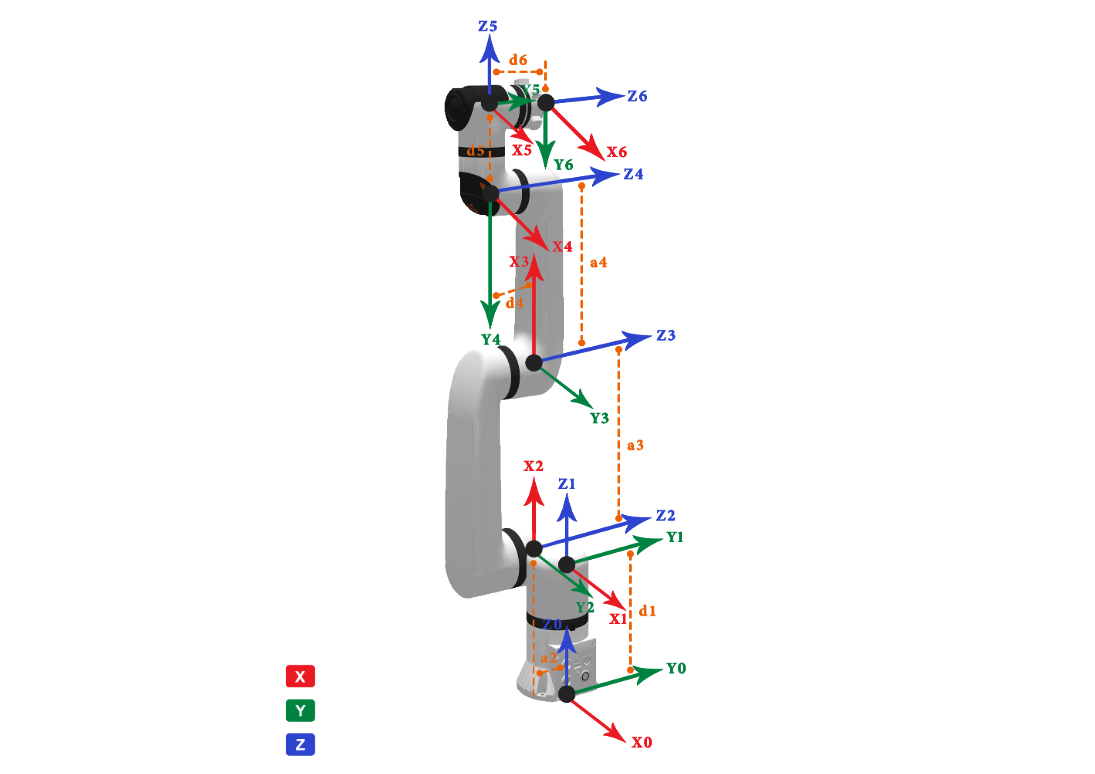
MDH Model Coordinate System
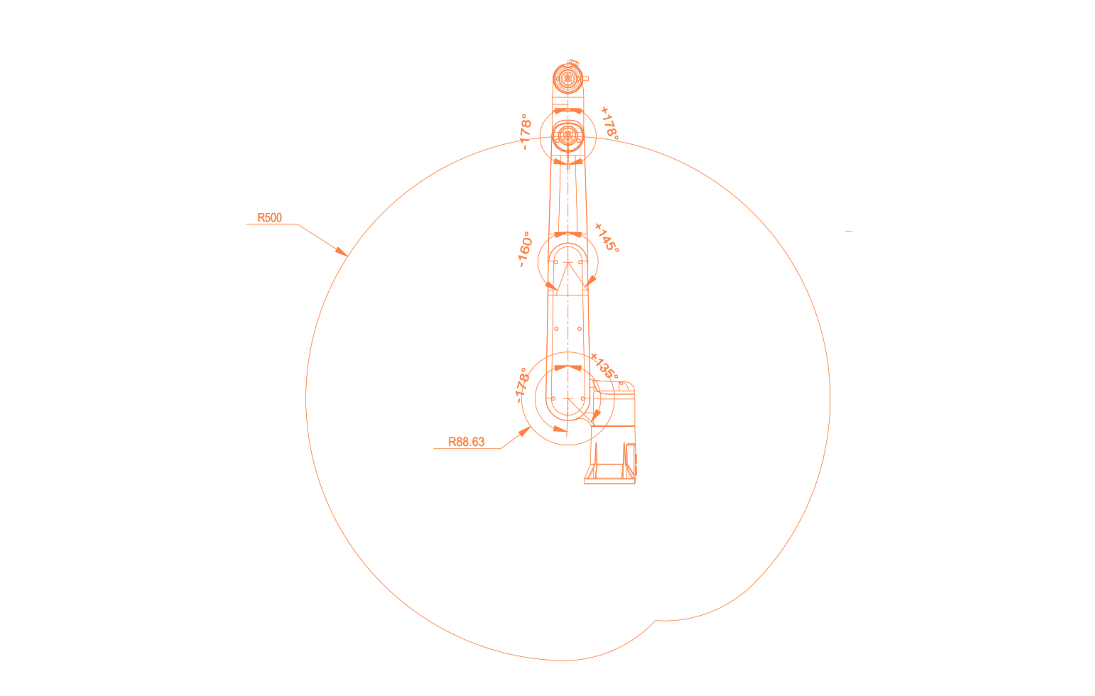
Workspace Diagram
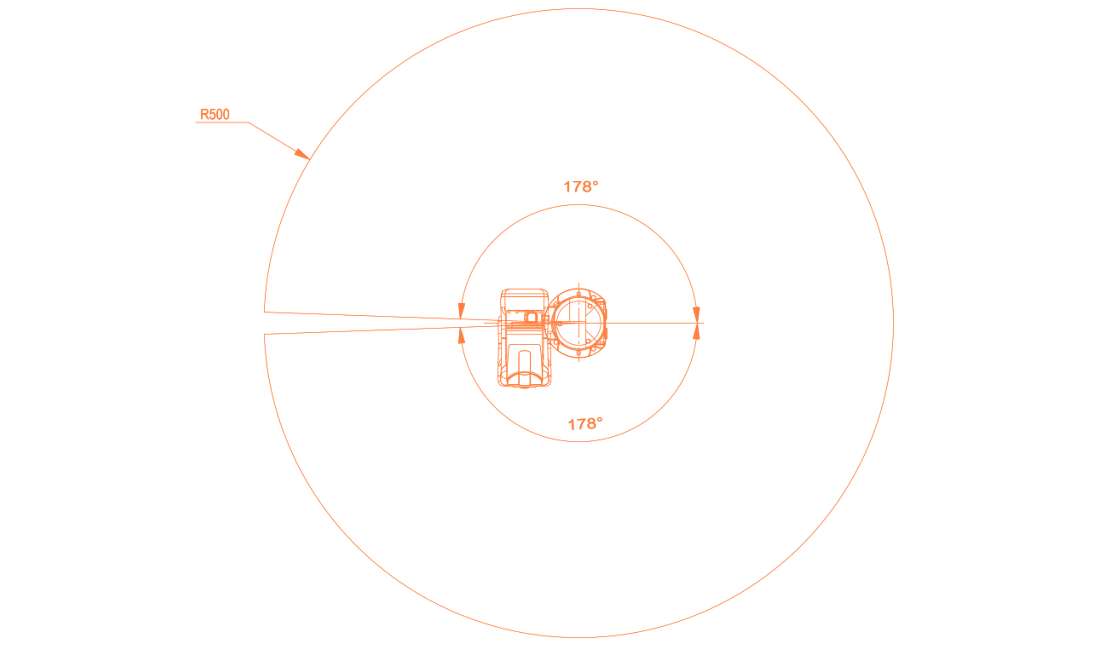
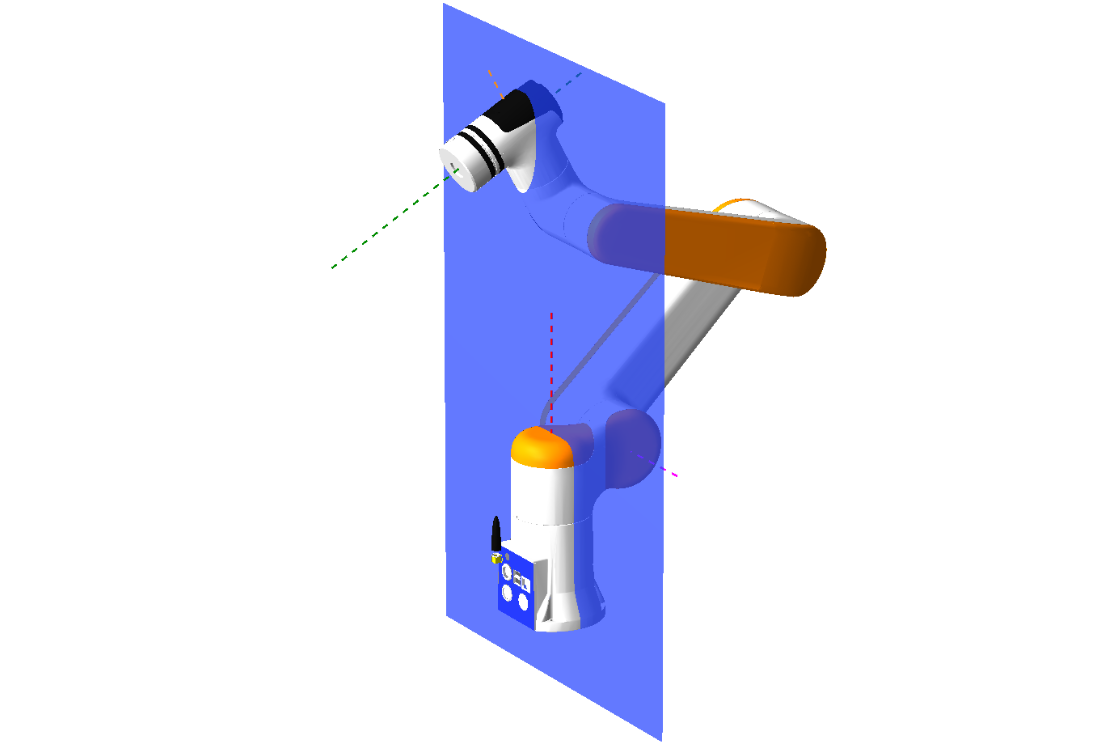
Shoulder Singularity Diagram
Application
A cost-effective choice for basic operations with precision and efficiency
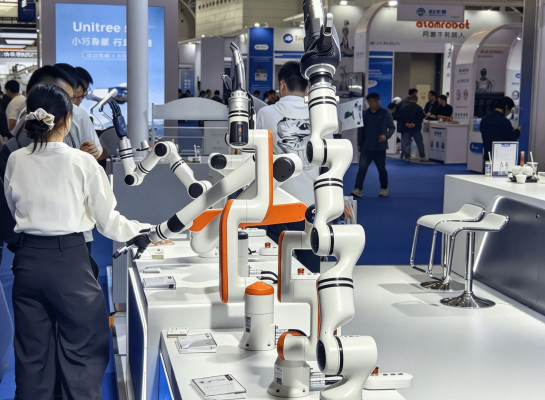
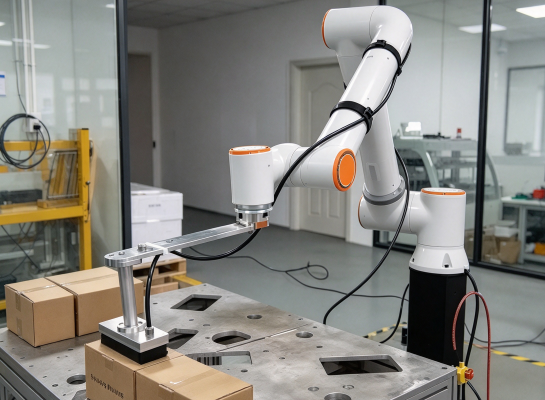
Suitable for new retail, industrial production lines, massage therapy, coffee robots and medical applications
Product parameters
Parameter | Value |
Degrees of freedom | 6 |
Rated payload | 5 kg |
Self-weight | 7.9 kg |
Repeatability | ±0.05 mm |
Working radius | 638.5 mm |
Power supply voltage | DC 20-30 V, 24 VDC nominal |
Power consumption | Max 200 W, typical 100 W |
Ingress protection | IP54 (robot arm body) |
Material | Aluminum alloy, ABS |
Controller | Integrated |
Communication | WiFi/Ethernet/Bluetooth/USB serial/RS485 |
Control methods | Drag teaching/teach pendant/API/JSON |
Joint motion range | J1 ±178°, J2 ±135° to 178°, J3 ±145° to 160°, J4 ±178°, J5 ±178°, J6 ±360° |
Max joint speed | J1-J2 180°/s, J3-J6 225°/s |
Six-axis force range | 200 N / 7 N·m |
Six-axis force accuracy | ≤0.1% FS |