

Product Description
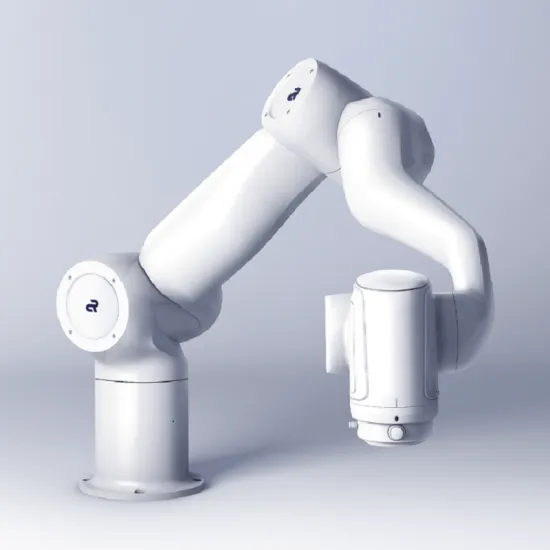
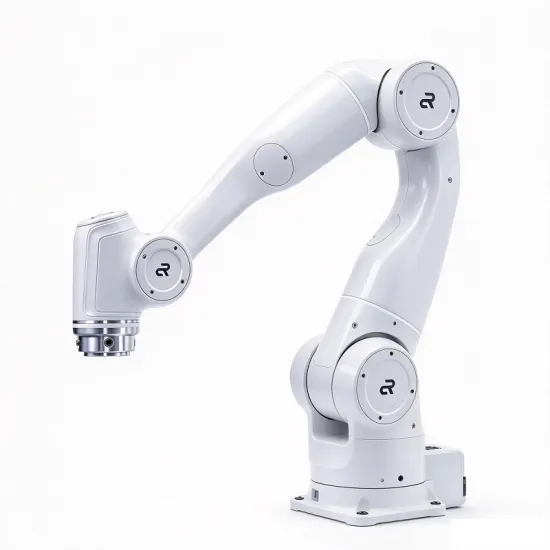
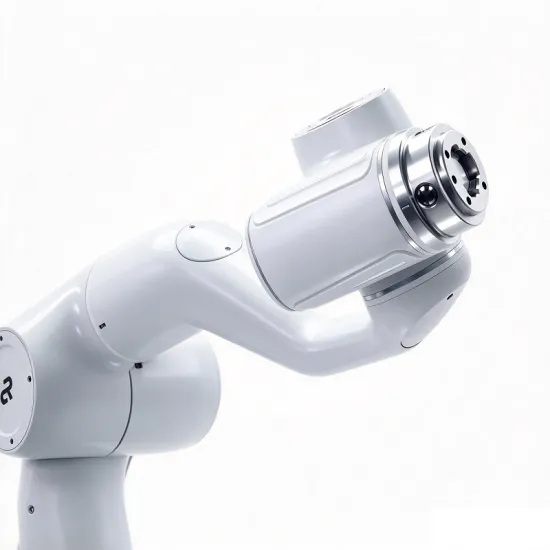
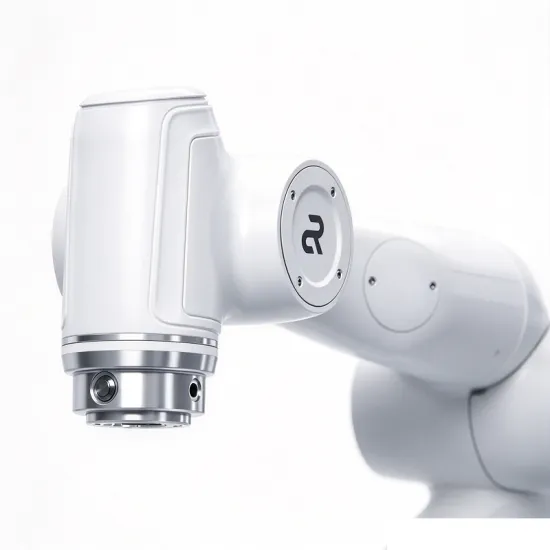
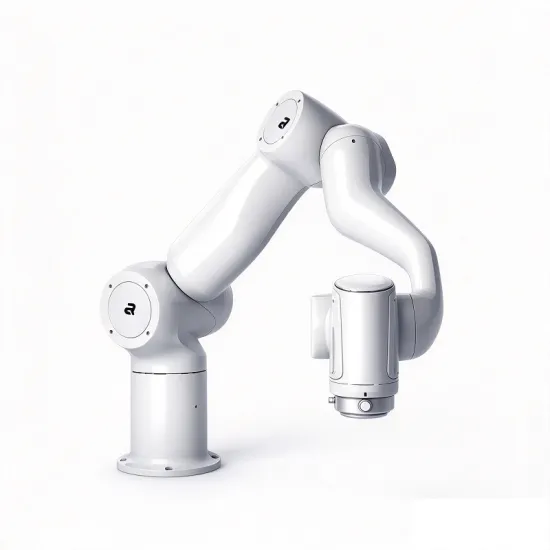
Dina 7 Med
Universal Medical Intelligent Force-Controlled Robot
Main application scenarios include robot-assisted surgery on hard tissues such as orthopedics, neurosurgery and dentistry, as well as ultrasound-based diagnosis and treatment, and rehabilitation therapy.
Functional Features
Universal Intelligent Force-Controlled Medical Robot
Diana 7 Med is a universal medical robot independently developed by Agile Robots. High-precision torque sensors integrated in its joints provide highly sensitive force sensing and collision detection.
The 7-DOF design offers a flexible workspace and control modes.
High-stiffness, impact-resistant design
· Flexible impedance control modes: stiffness and damping can be set independently for each axis
· API interface developed for medical scenarios
· Automatic load identification and compensation
· Alcohol-resistant surface coating
· Matte finish without interference to optical positioning systems
· Compliant with IEC 60601-1 and IEC 60601-1-2
Application
From the operating room to the rehabilitation clinic, the versatility of Diana 7 Med keeps it active throughout every stage of the healthcare chain.
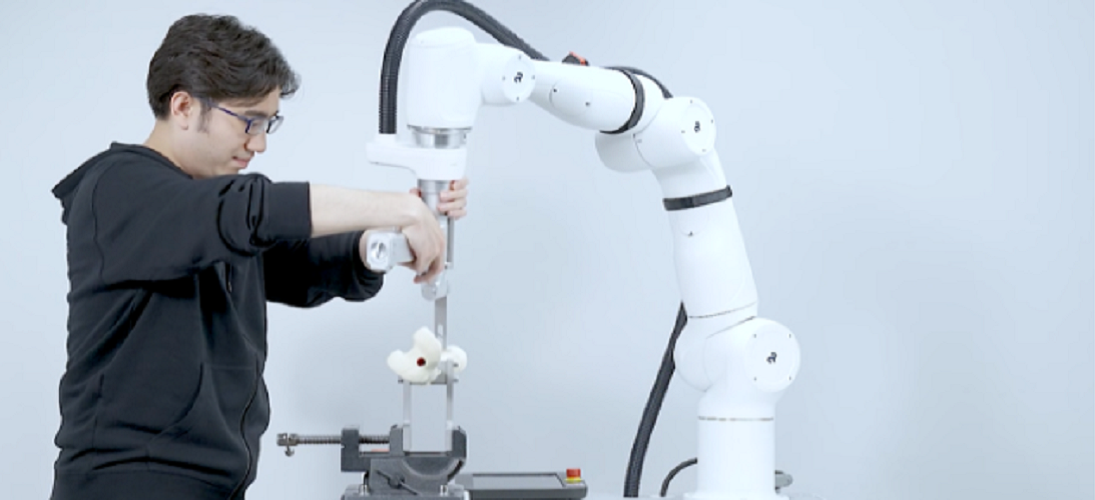
Orthopedic & Neurosurgical Assistance
With its high stiffness and force feedback, the robot assists in holding grinding drills or locating guide pins during spinal surgery, joint replacement, or dental implantation.
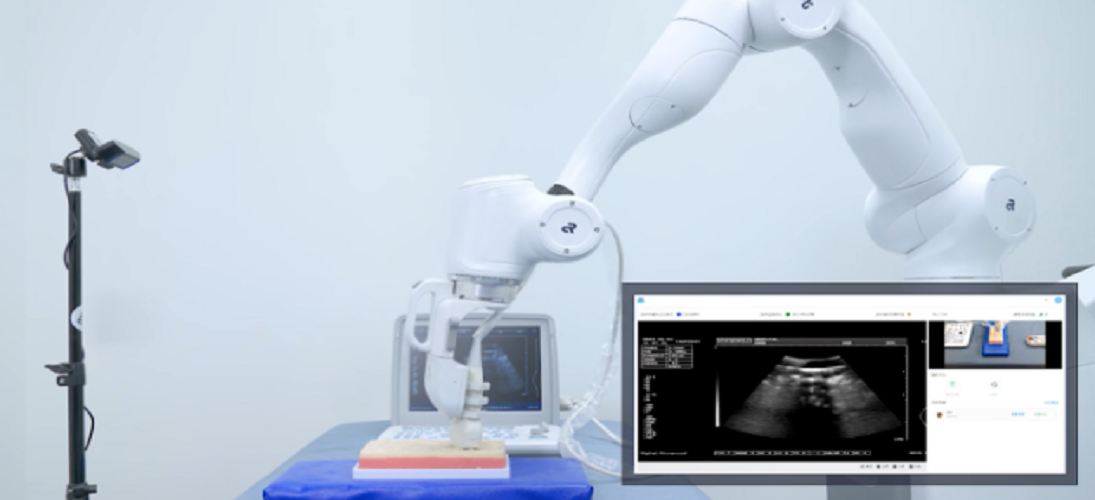
Automated Ultrasound Diagnosis
Diana 7 Med can be equipped with an ultrasound probe and, through constant-force control technology, deliver automated scanning — even providing hardware support for remote ultrasound medicine.
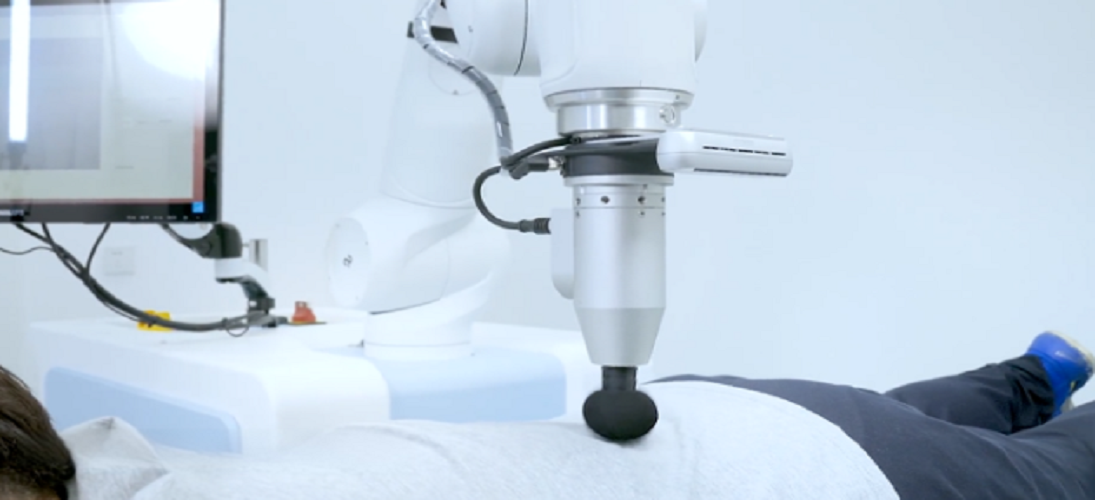
Traditional Chinese Medicine Therapy & Rehabilitation
Diana 7 Med can replicate the pushing, kneading and massage pressure of professional physiotherapists, providing patients with standardized rehabilitation plans.
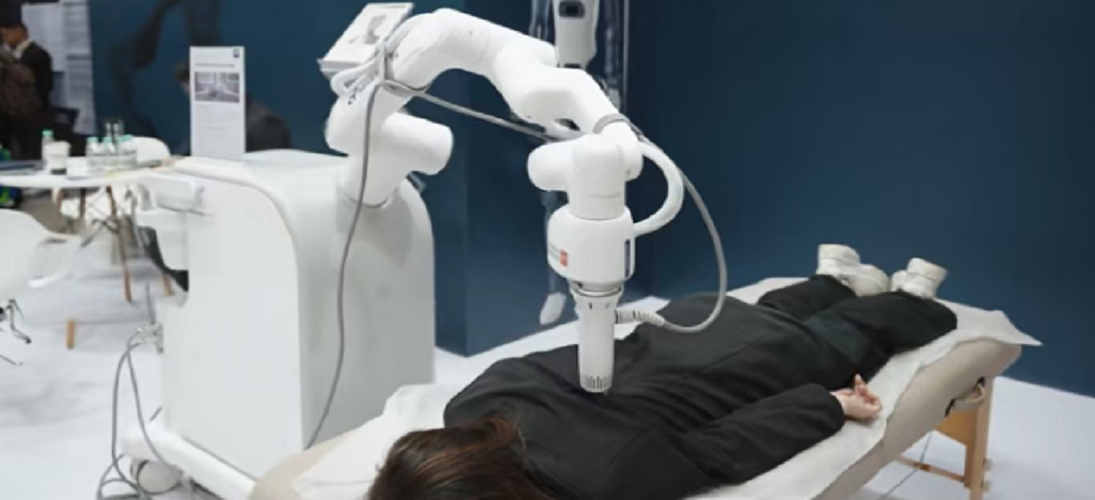
For the smart health & elderly care sector, it adapts to wellness centers, physiotherapy institutions, enterprises and premium commercial spaces, delivering standardized intelligent physiotherapy and massage services for the shoulders and neck, waist and back, and limbs through the X-SPA solution.
Product parameters
Parameter | Value | Parameter | Value |
Payload | 7 kg | Weight | 30 kg |
Working radius | 916 mm | Base diameter | φ190 mm |
Degrees of freedom | 7 | Max. TCP linear speed | 1.2 m/s |
Repeat positioning accuracy | ±0.03 mm | Force control accuracy | 0.5 N |
Programming | Graphical programming environment, scripting API | ||
Joint 1 range of motion | -179°~179° | Joint 1 max. speed | 90°/s |
Joint 2 range of motion | -90°~90° | Joint 2 max. speed | 90°/s |
Joint 3 range of motion | -179°~179° | Joint 3 max. speed | 90°/s |
Joint 4 range of motion | -1°~175° | Joint 4 max. speed | 90°/s |
Joint 5 range of motion | -179°~179° | Joint 5 max. speed | 170°/s |
Joint 6 range of motion | -179°~179° | Joint 6 max. speed | 170°/s |
Joint 7 range of motion | -179°~179° | Joint 7 max. speed | 170°/s |
Parameter | Value | Parameter | Value |
Cable length (robot to control box) | 5.0 m | Control box power supply | 220V AC, 50Hz |
Dimensions | 431mm x 365mm x 174mm | Weight | 13.5 kg |
I/O ports | 4 port DI / 4 port DO | I/O power | 24V/2A |