

Product Description
LEAP Hand
Low-cost, efficient, and anthropomorphic
c
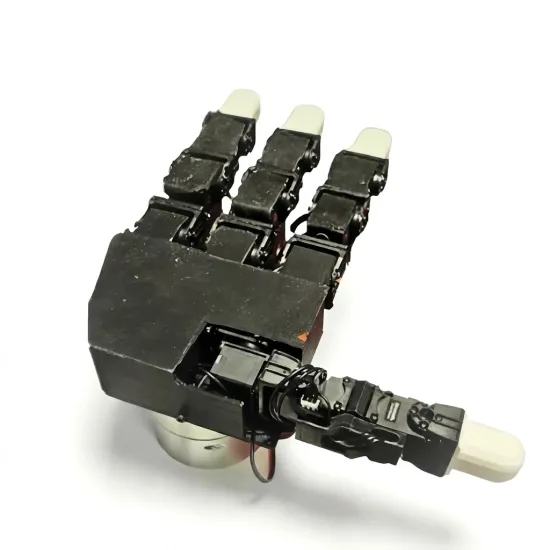
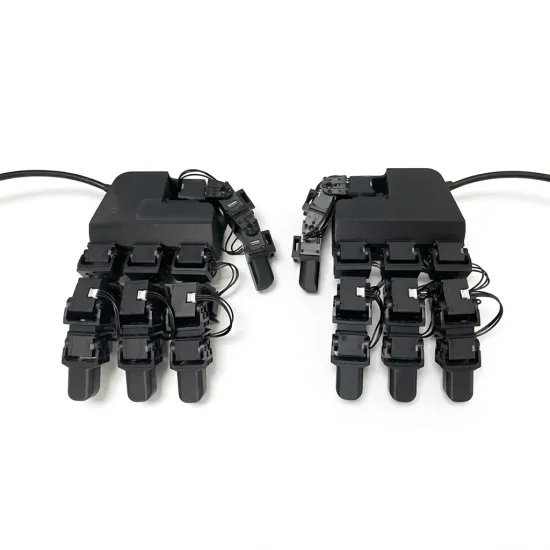
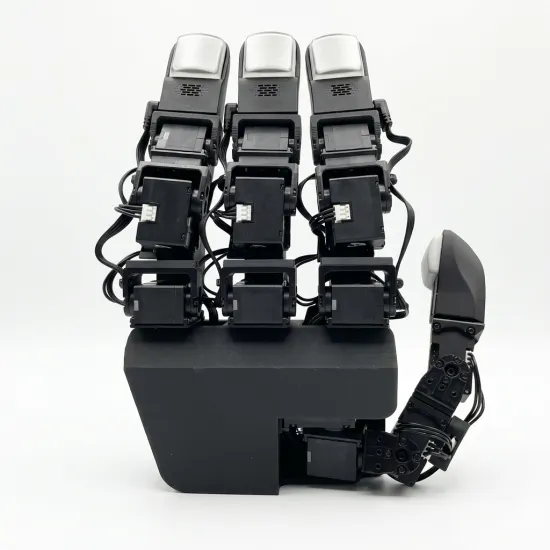
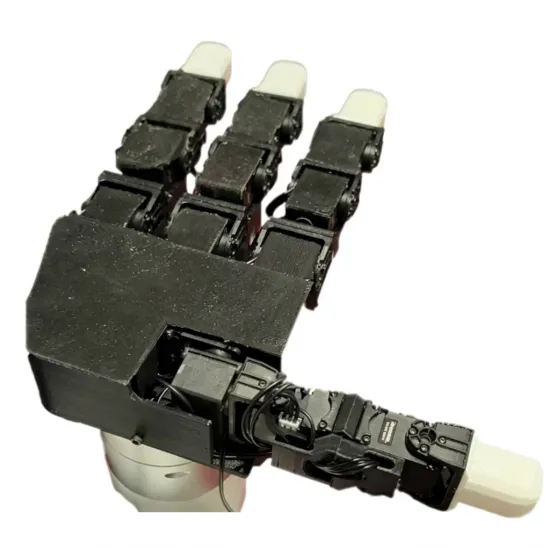
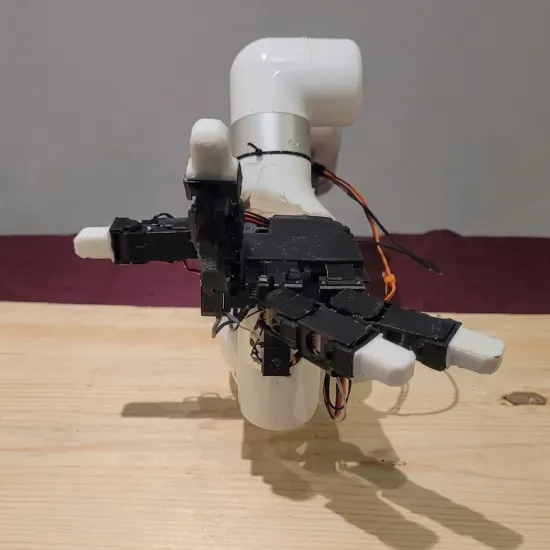
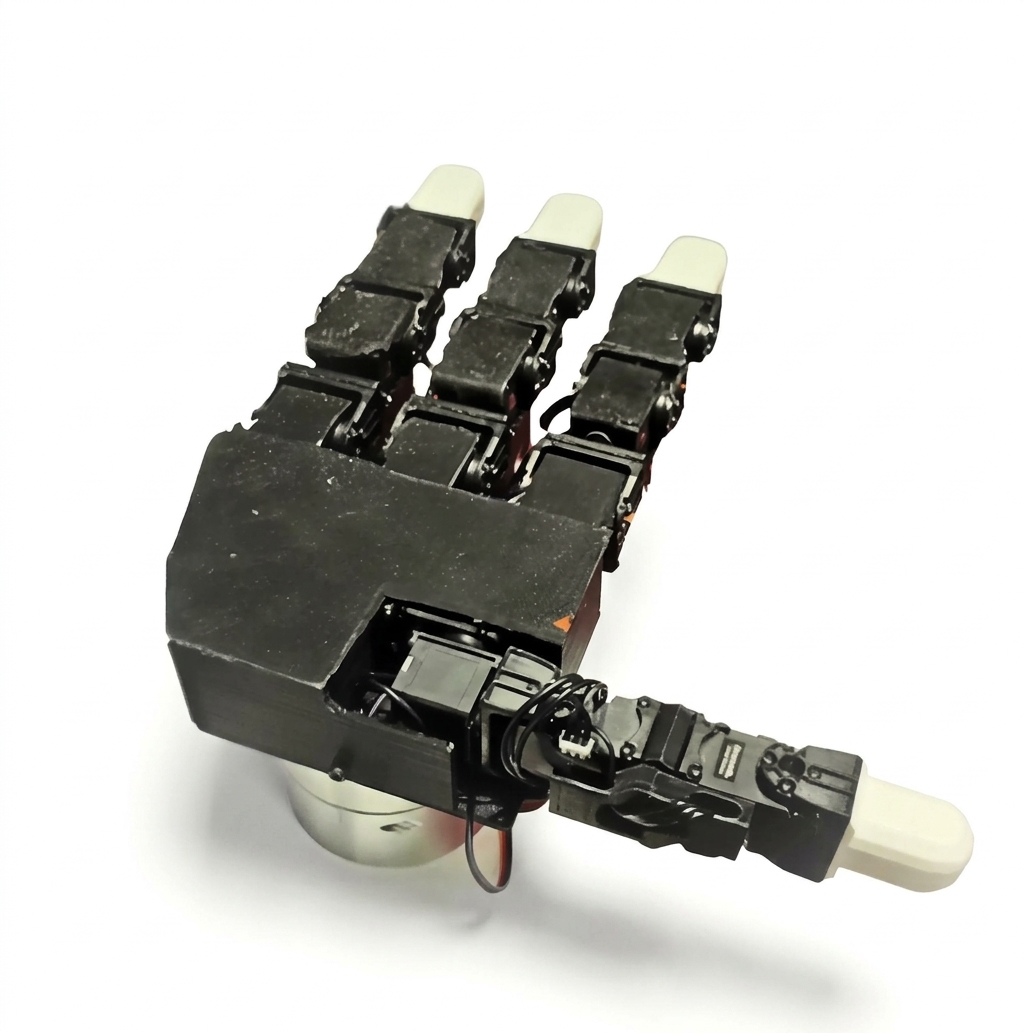
LEAPHand features an innovative kinematic structure that ensures exceptional dexterity across a wide range of finger poses. It is highly affordable and can be assembled in just four hours using off-the-shelf components. Beyond its cost-effectiveness, LEAPHand is also capable of delivering high torque output consistently over extended periods of operation.
| LEAPHand has a novel motion structure that can be achieved regardless of finger posture. Maximum flexibility, LEAPHand is low cost and can be used ready-made in 4 hours Parts assembled, cost $2,000. Multi-Task Manipulation LEAPHand can be used to perform a variety of manipulation tasks in the real world ranging from visual teleoperation to learning from passive video data and sim-to-real transfer. Low Cost LEAPHand significantly outperforms its closest competitor, the Allegro Hand, while costing only one-eighth as much. |
Advantages LEAPHand is an open-source robotic hand designed for machine learning: 1) Highly dexterous 2) Low-cost and easy to build 3) Robust and durable
|
|
Functional Features
| Using Internet Videos for Behavioral Cloning |
|
Teleoperation from Uncalibrated Human Videos |
| One of the most powerful robotic hands on the market |
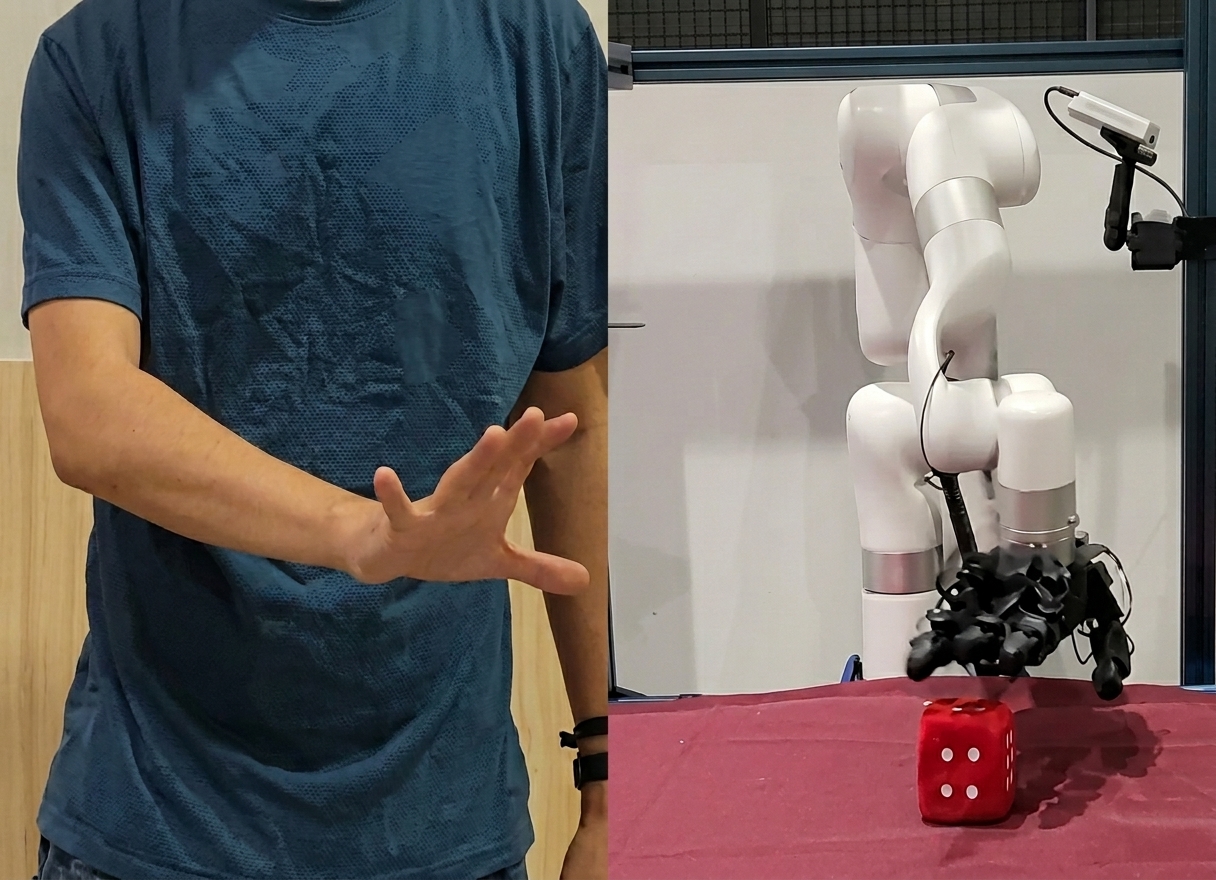
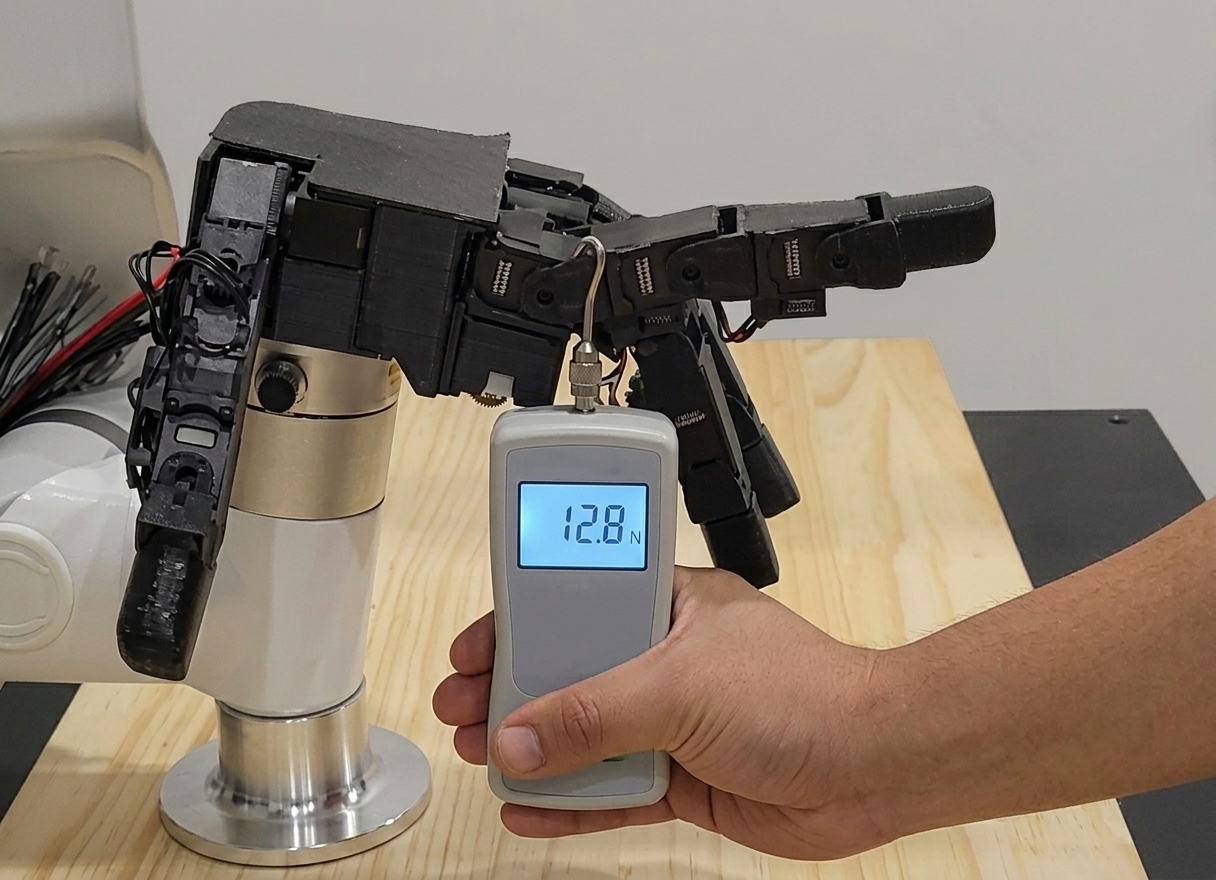
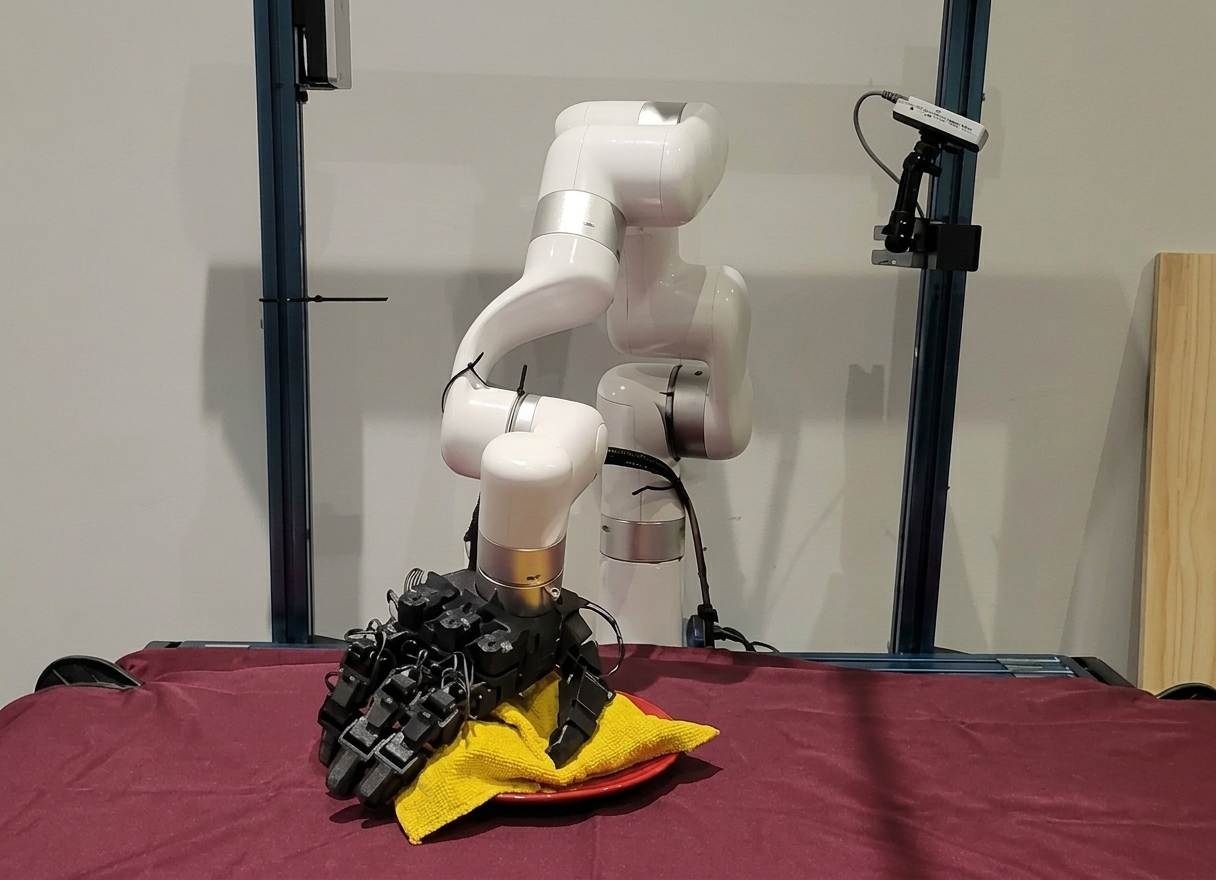
Robustness The LEAP Hand can accurately perform repetitive actions without overheating. | Robustness The LEAP Hand can perform accurately repetitive actions without overheating. | Cost The LEAP Hand costs less than $2,000 |
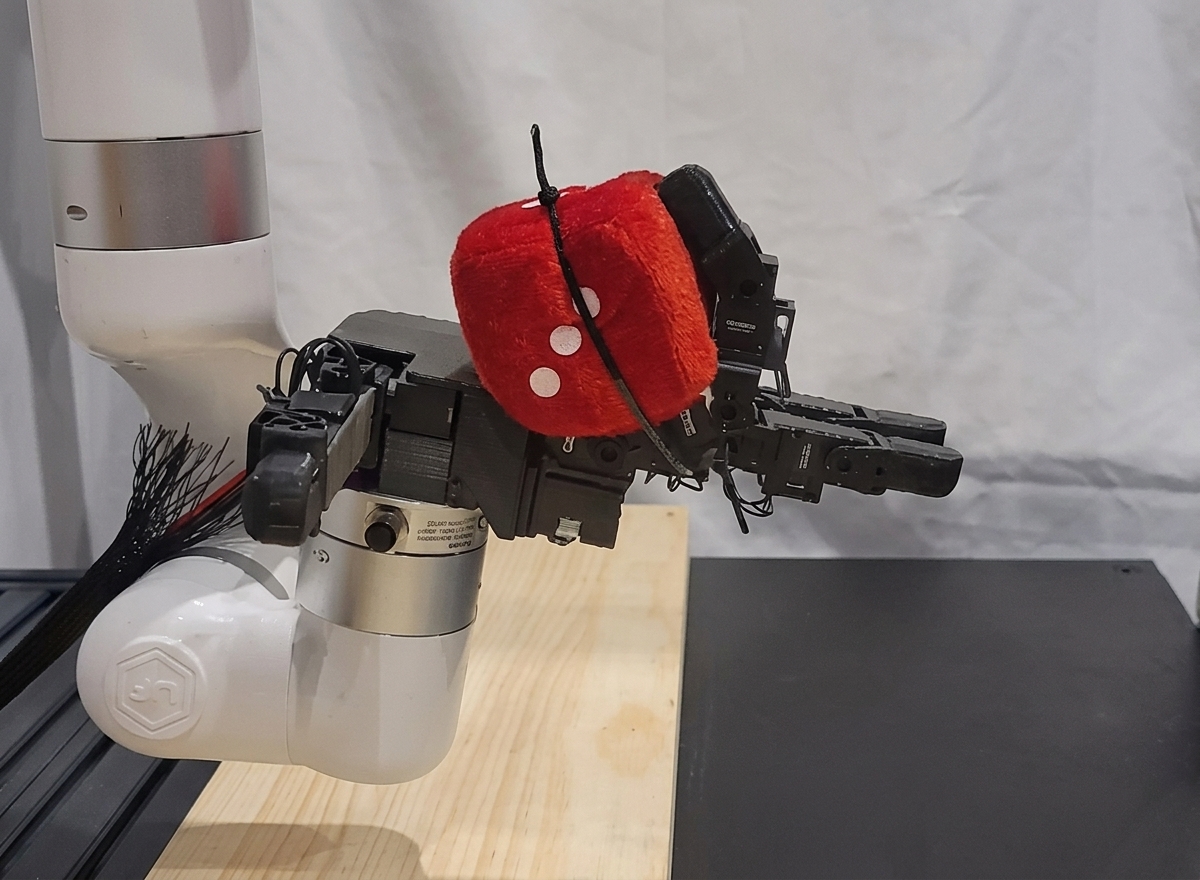
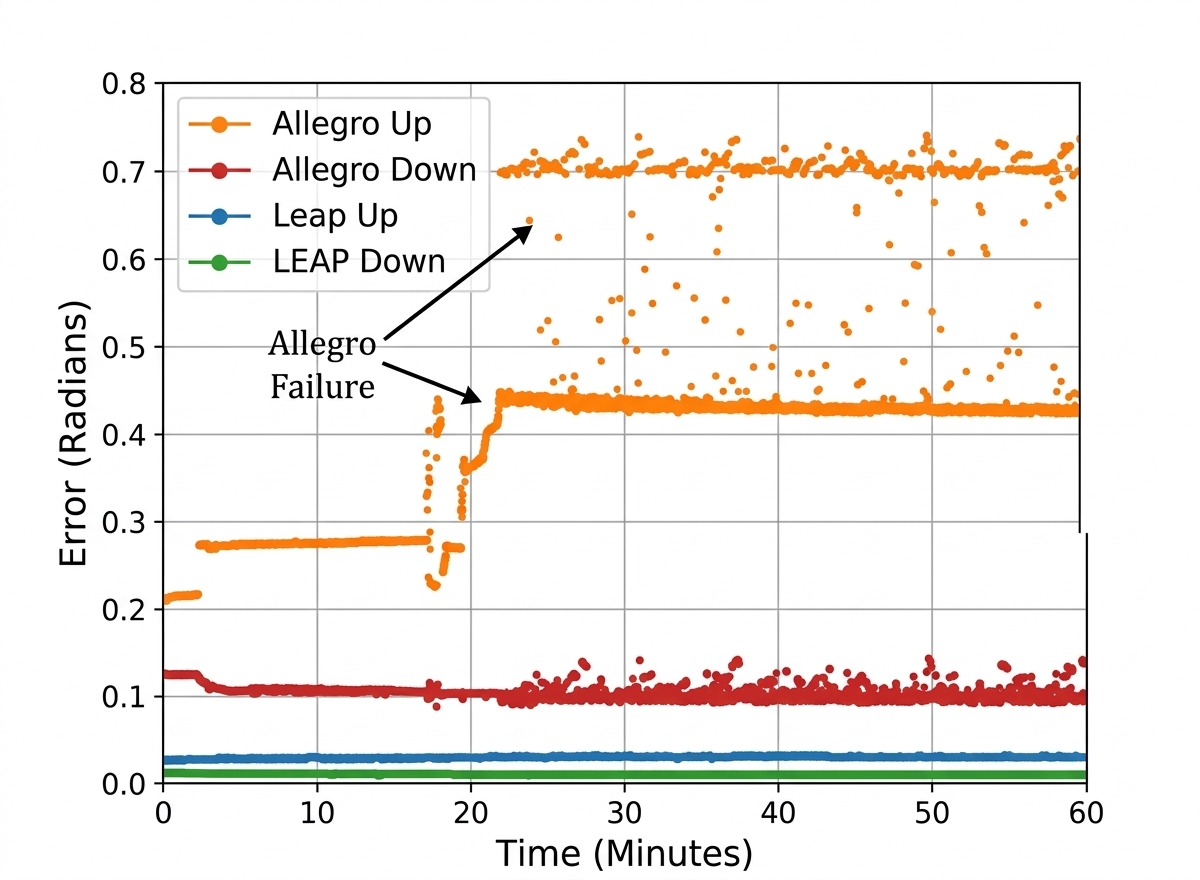
Robustness
LEAP Hand can accurately complete repeated motions without overheating
| |
Strength
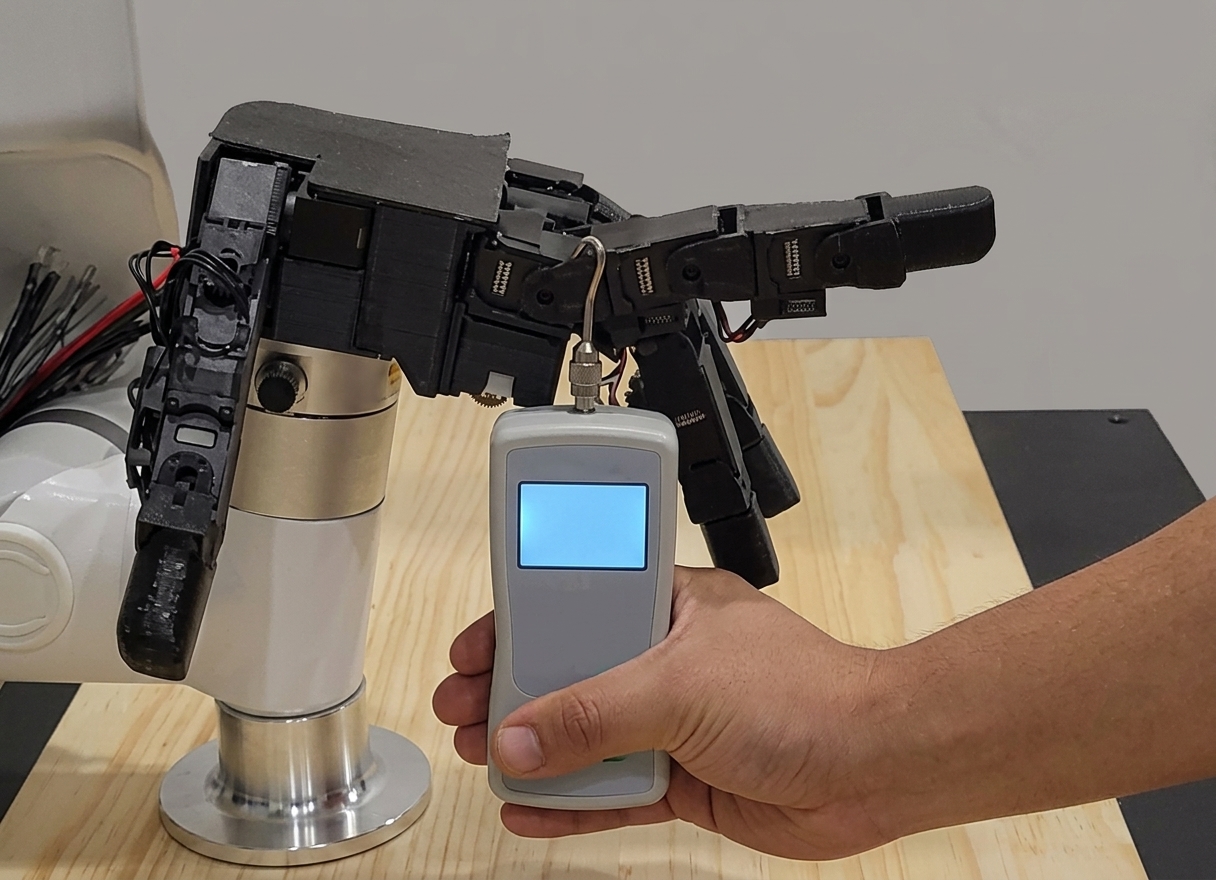
LEAP Hand is one of the strongest robotic hands available today
| Hand | Strength (N) | Power Density N x DOF/(em²) |
Bauer et.al [28] Allegro Hand [20] D'Manus [21] Inmoov Hand [18] Adult Human Hand | 37.4 8.5 27.8 5.8 26.5 | 0.677 0.35 0.313 0.116 2.199 |
LEAP Hand LEAP-CHand | 19.5 21.5 | 1.045 1.15 |
TABLE II: Pullout Test. A resistance comparison of each hand to pullout force which correlates to grasping strength. Power density is the total amount of motor force per square area of the hand.
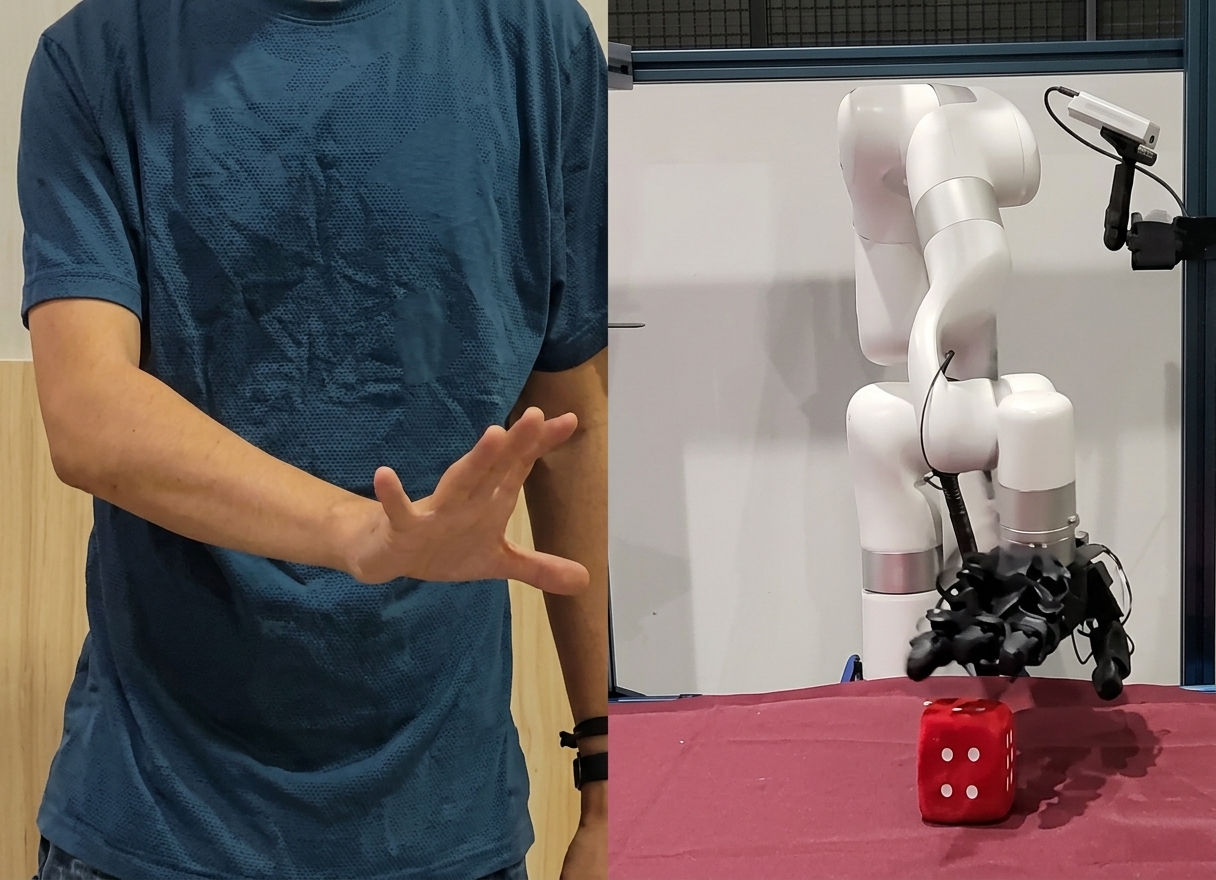
ML: Learning from Humans
LEAPHand can learn from human video data, using joint-to-joint mapping or energy functions.
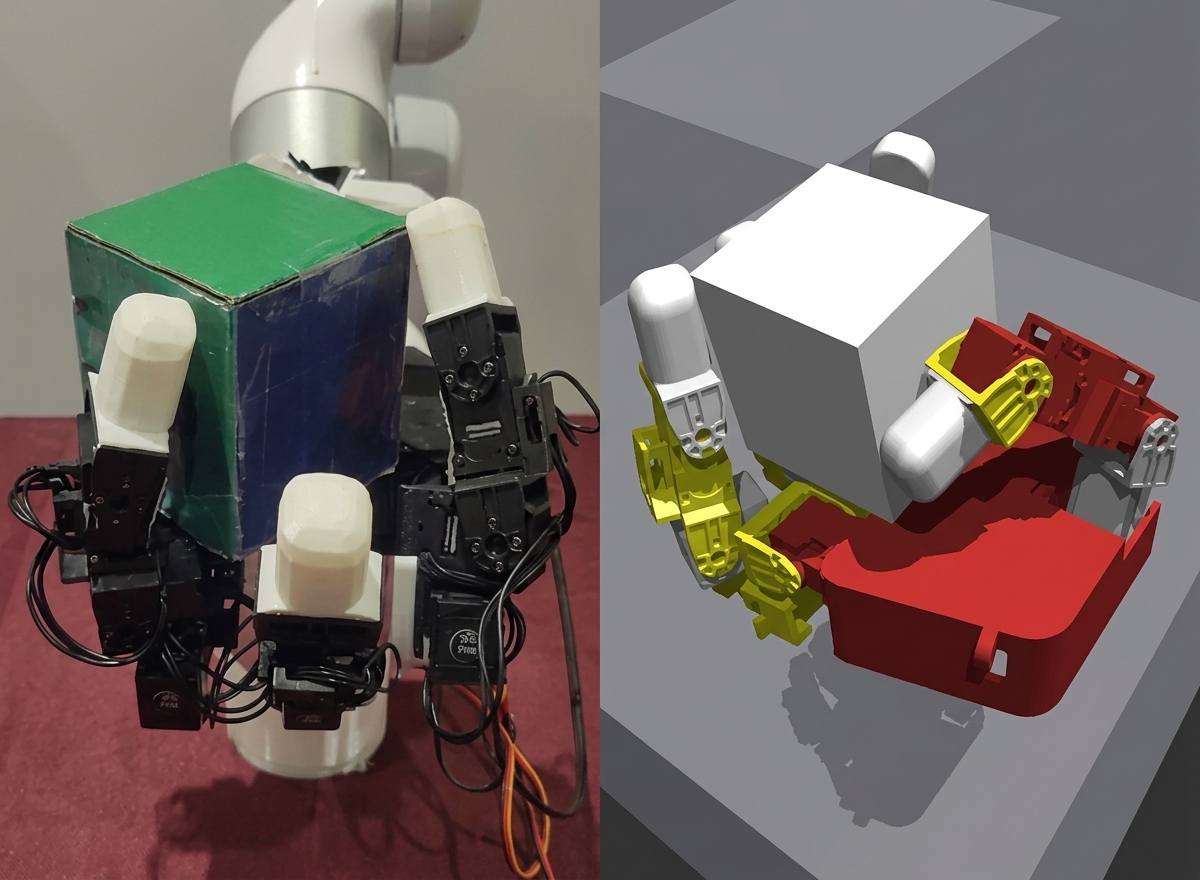
ML: Sim2Real Manipulation
The URDF for LEAPHand faithfully and accurately represents the actual robotic hand and can be used with many RL frameworks.
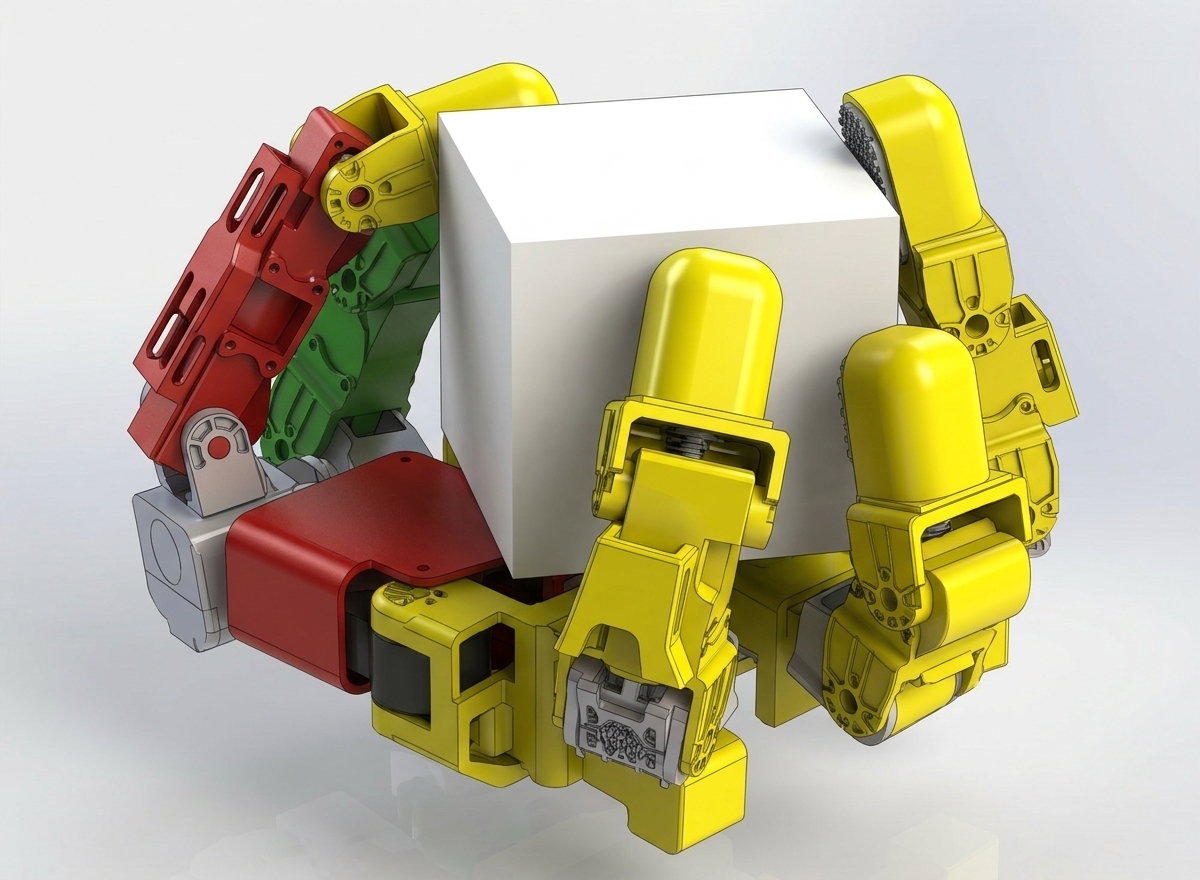
Not paired videos
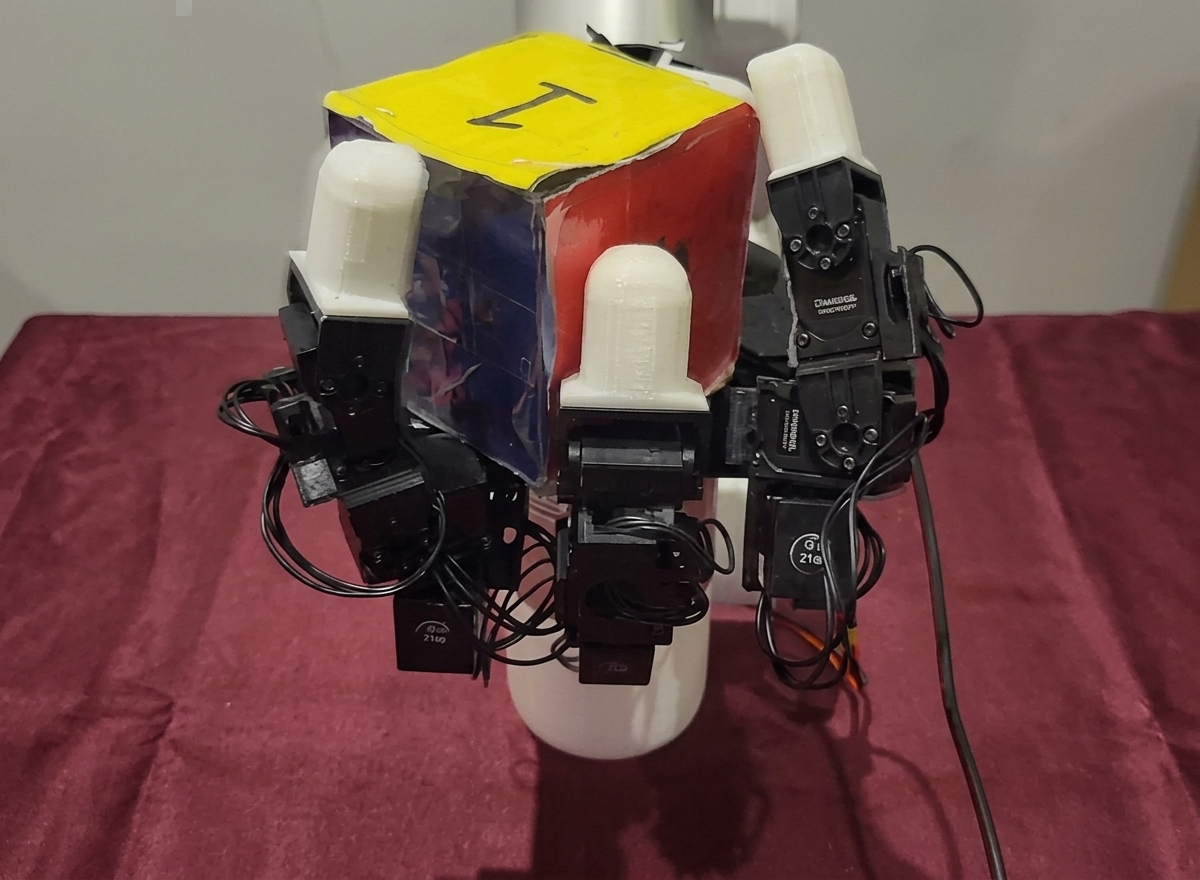
Real Time
Product Display
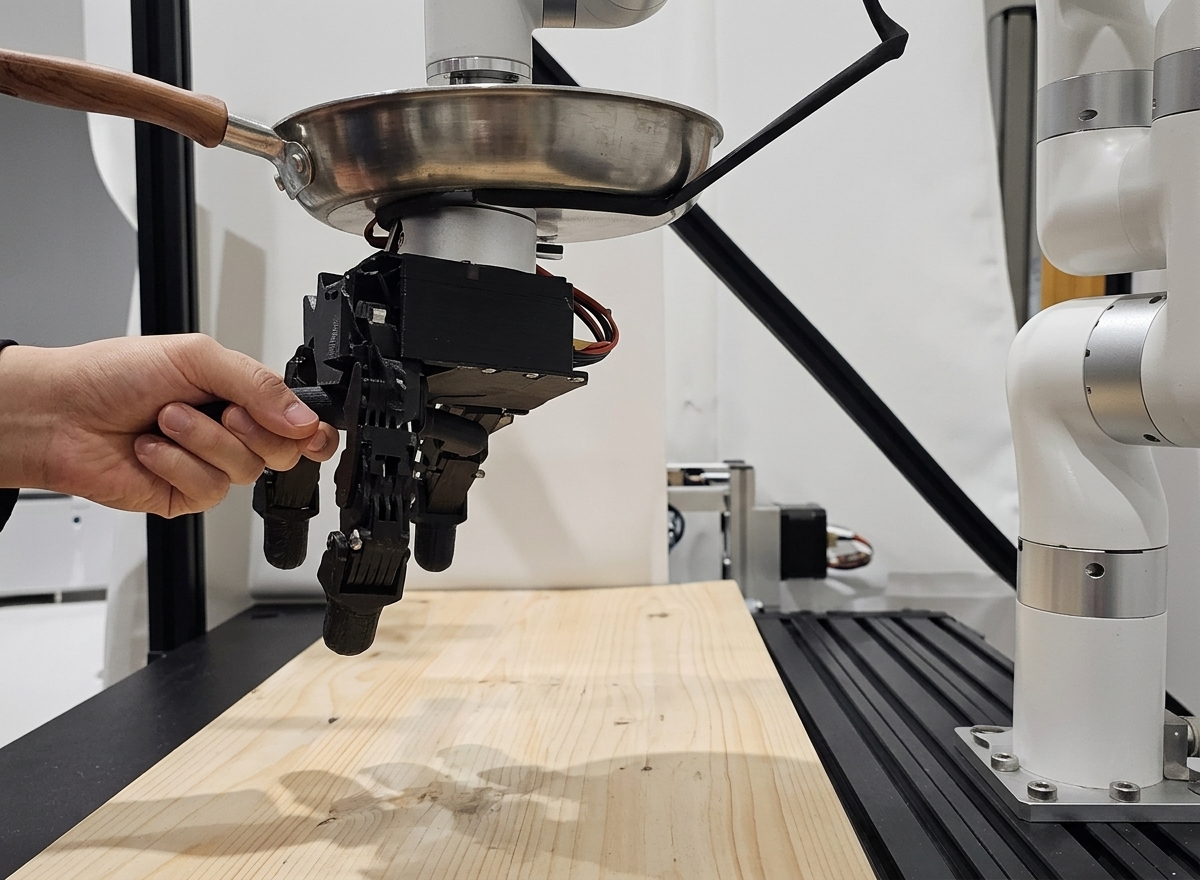
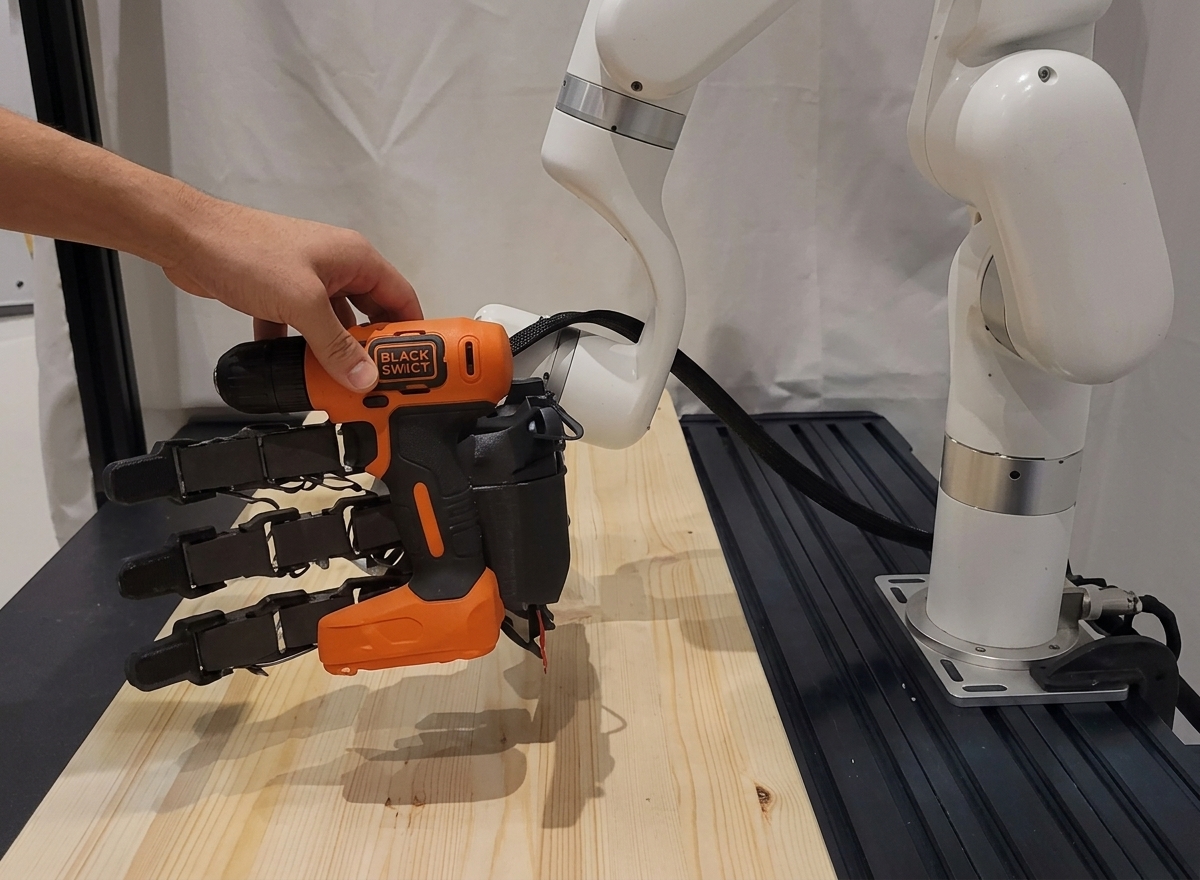
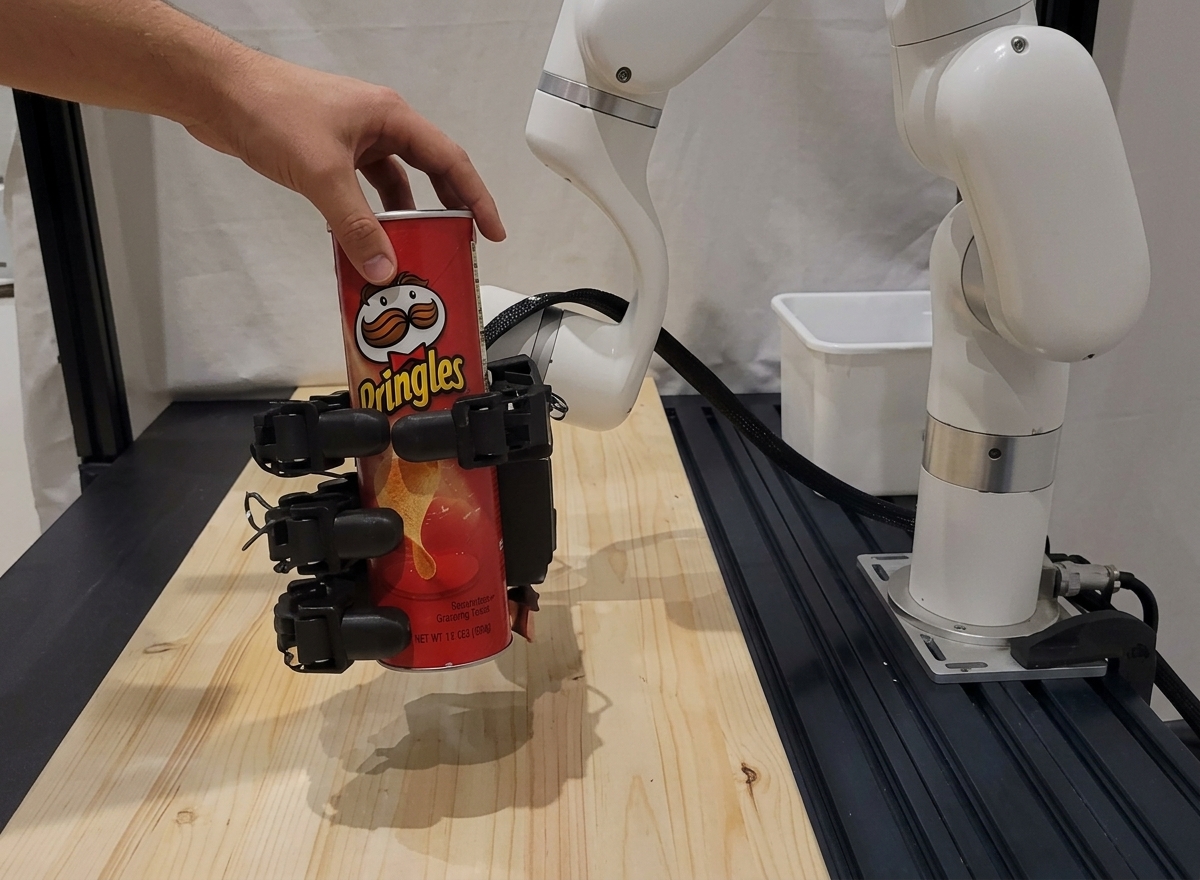
Human-like Versatility
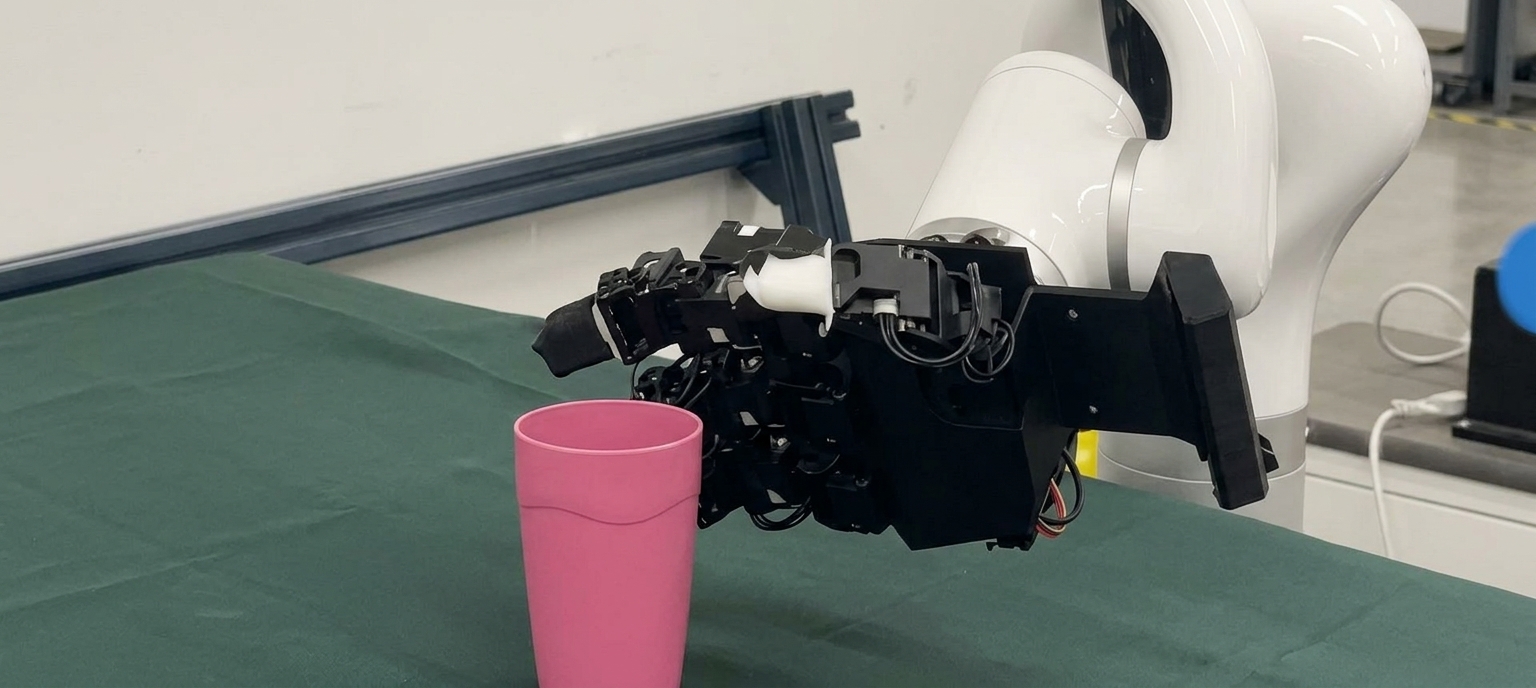
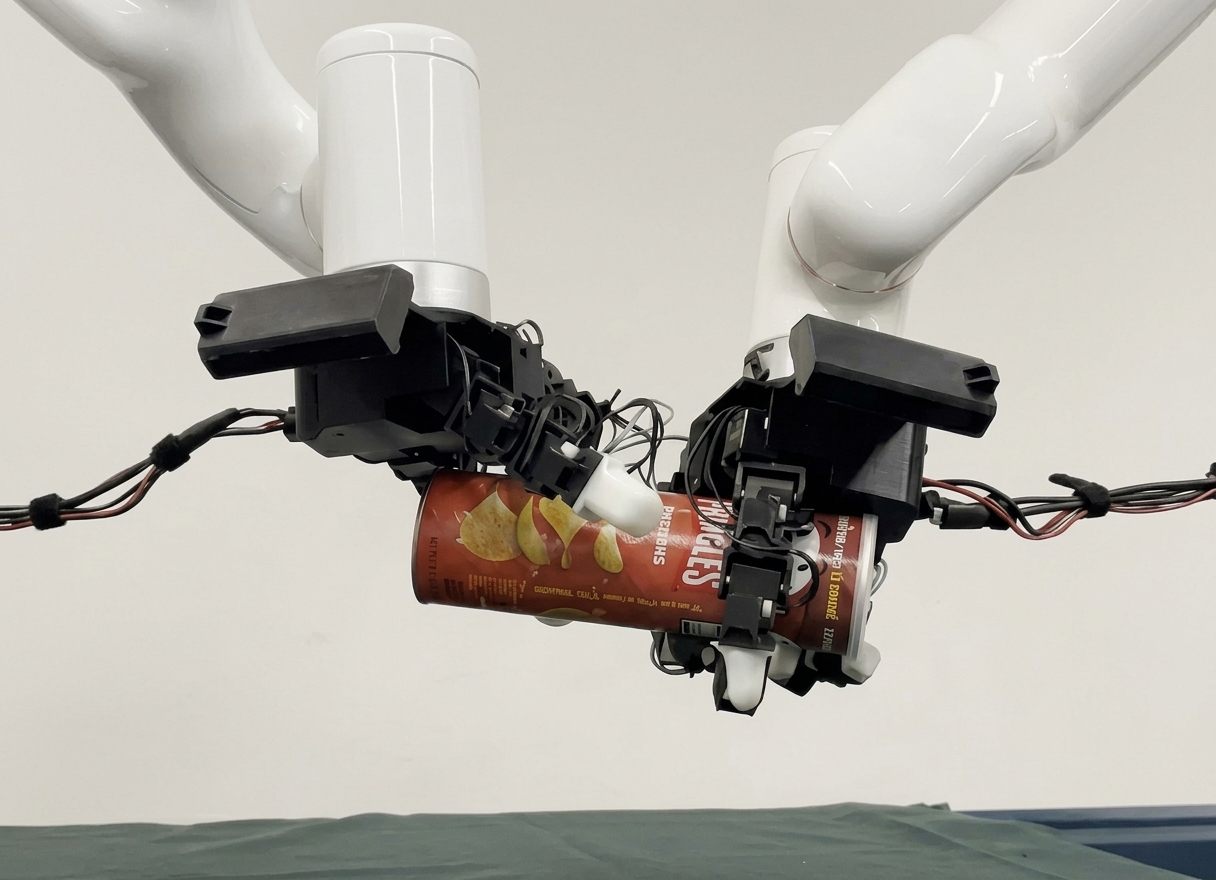
LEAP Hand can grasp a wide variety of objects easily
|
|
|
Kinematics and Dexterity
LEAP hand demonstrates side to side dexterity in both the finger up and finger down configuration. This is thanks to its universal abduction-adduction mechanism.
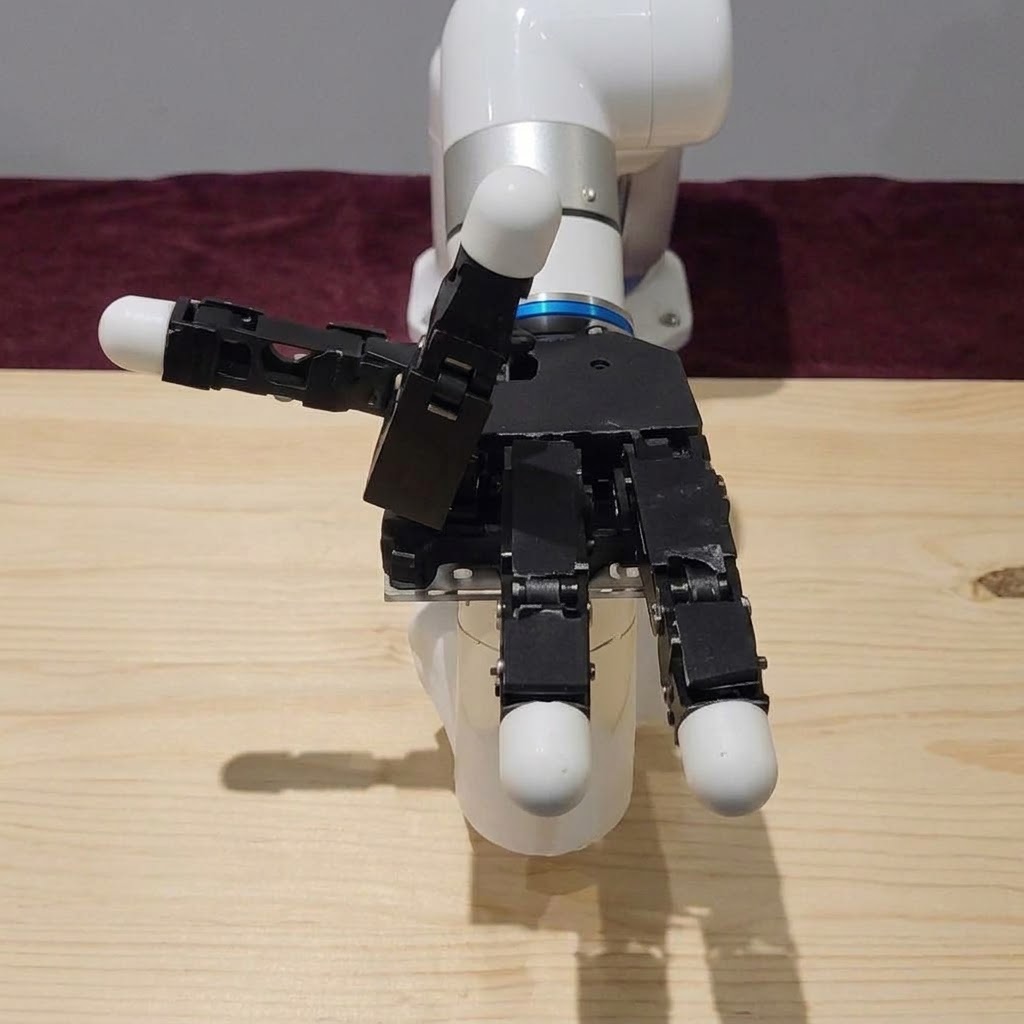
Pronation-Supination
When Up
AllegroHand
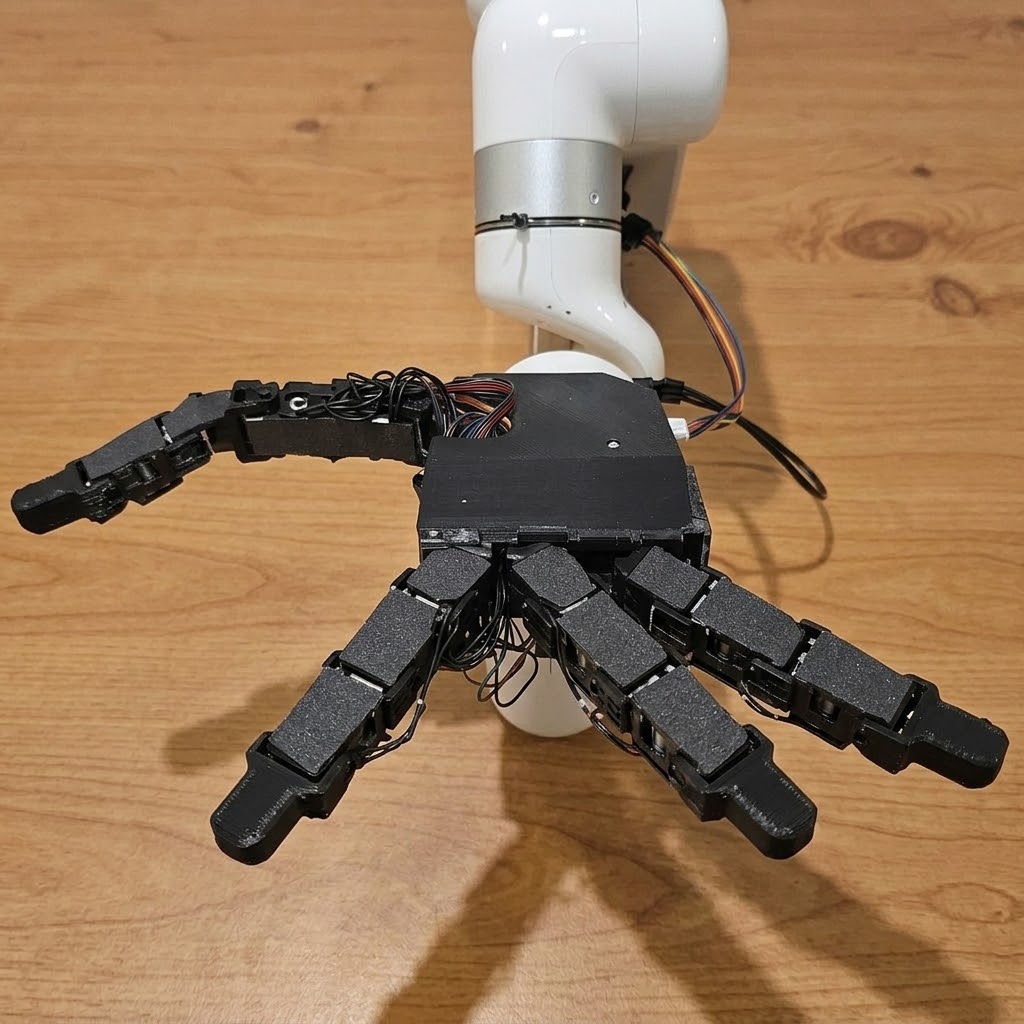
Abduction-Adduction
When Down
LEAP-CHand
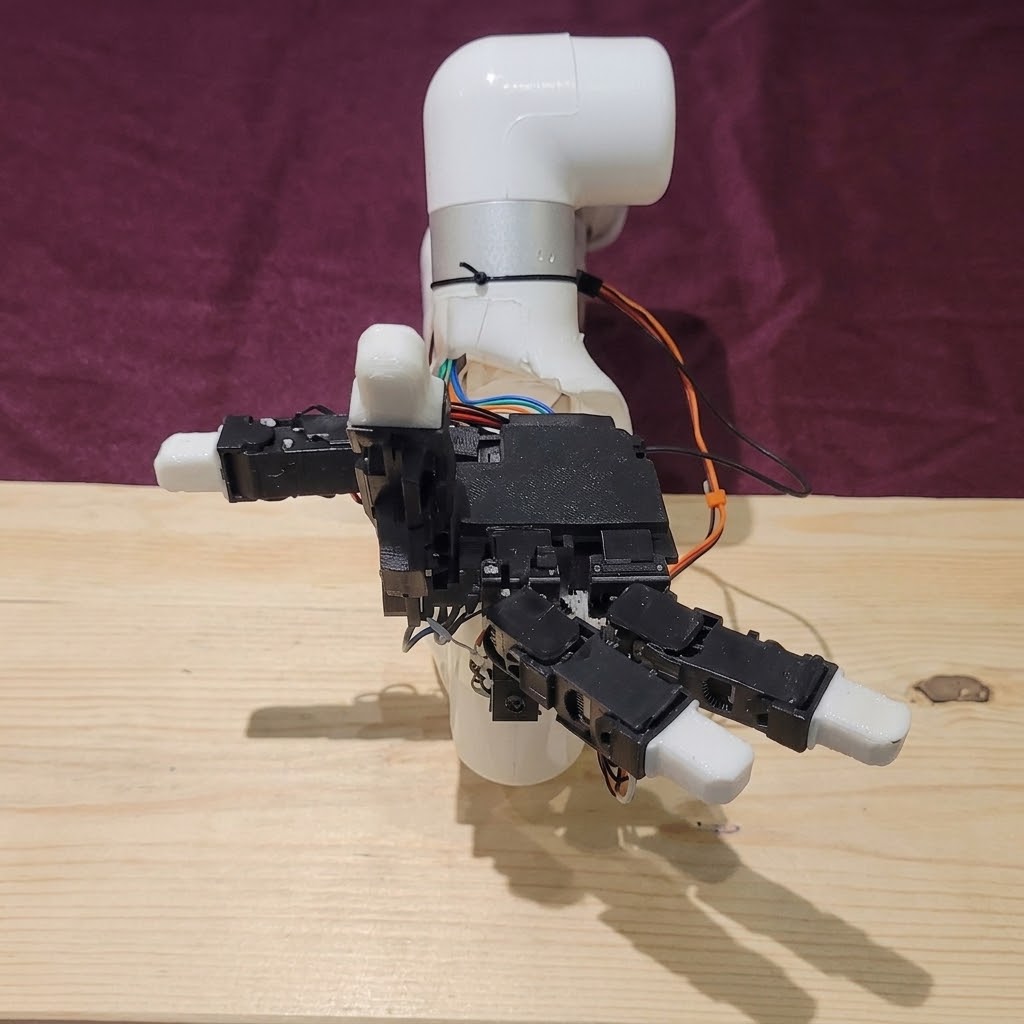
Abduction-Adduction
At Both Positions
LEAPHand
Product parameters
XL330 Complete Version List (This version comes fully assembled and is ready for use right out of the box)
No. | Item / Description | Unit | Quantity |
1 | XL330-M288-T | Set | 16 |
2 | FPX330-H101 | Pack | 3 |
3 | FPX330-S101 | Pack | 3 |
4 | FPX330-S102 | Pack | 2 |
5 | U2D2 Serial Communication Module | Set | 1 |
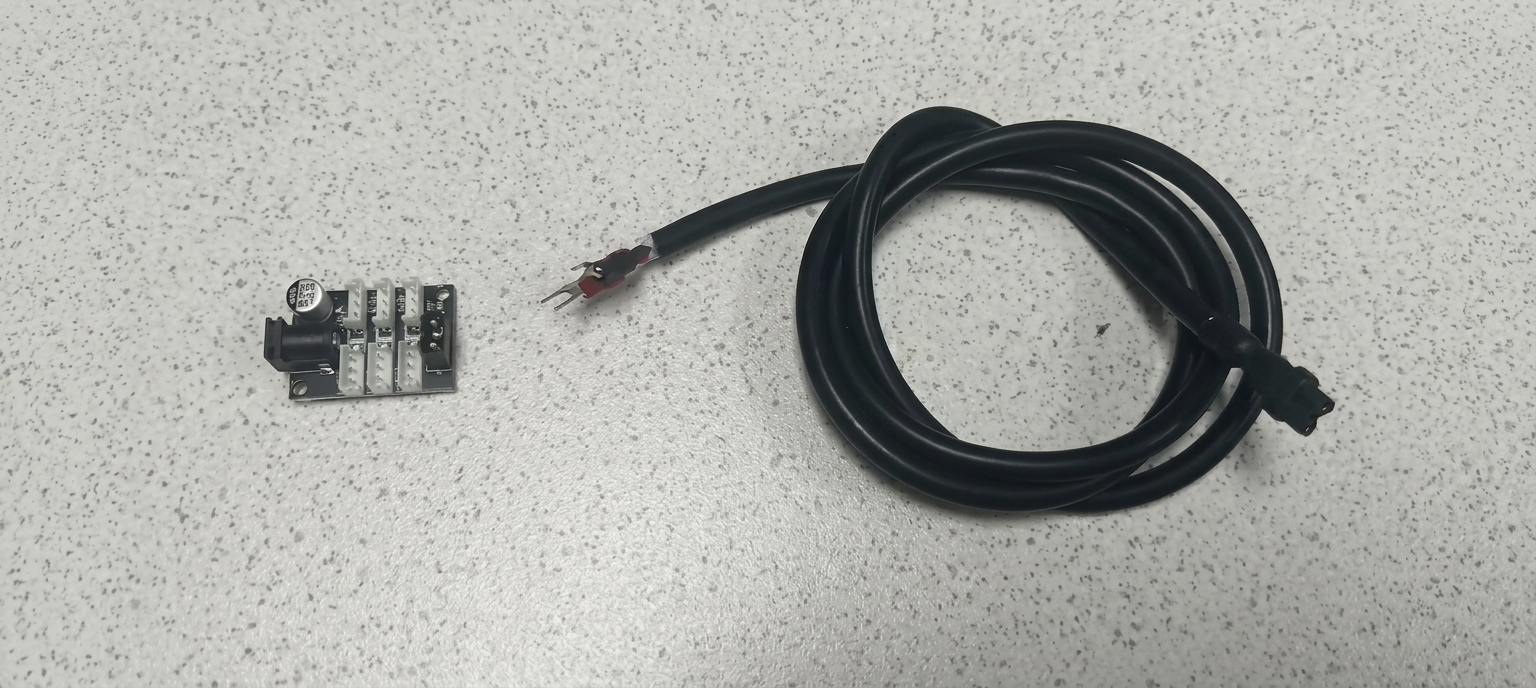
6 | YA-EX2DXL Power Extension Board | Piece | 1 |
7 | X3 PIN Servo Cable 20cm | Piece | 5 |
8 | DC5.5*2.5 Power Extension Cable | Piece | 1 |
9 | 3D Printed Parts | Set | 1 |
10 | 5V 26A Power Supply | Set | 1 |
11 | Assembly & Calibration Service | - | 1 |
XC330 Complete Version List (This version comes fully assembled and is ready for use right out of the box)
No. | Item / Description | Unit | Quantity |
1 | XC330-M288-T | Set | 16 |
2 | FPX330-H101 | Pack | 3 |
3 | FPX330-S101 | Pack | 3 |
4 | FPX330-S102 | Pack | 2 |
5 | U2D2 Serial Communication Module | Set | 1 |
6 | YA-EX2DXL Power Extension Board | Piece | 1 |
7 | X3 PIN Servo Cable 20cm | Piece | 5 |
8 | DC5.5*2.5 Power Extension Cable | Piece | 1 |
9 | 3D Printed Parts | Set | 1 |
10 | 5V 26A Power Supply | Set | 1 |
11 | Assembly & Calibration Service | Service | 1 |
XC330 DIY Version Parts List
(Note: This version does not include 3D-printed parts or a power supply; users are responsible for assembly and calibration.)
No. | Item / Description | Unit | Quantity |
1 | XC330-M288-T | Set | 16 |
2 | FPX330-H101 | Pack | 3 |
3 | FPX330-S101 | Pack | 3 |
4 | FPX330-S102 | Pack | 2 |
5 | U2D2 Serial Communication Module | Set | 1 |
6 | YA-EX2DXL Power Extension Board | Piece | 1 |
7 | X3 PIN Servo Cable 20cm | Piece | 5 |
8 | DC5.5*2.5 Power Extension Cable | Piece | 1 |
XL330 DIY Version Parts List
(Note: This version does not include 3D-printed parts or a power supply; assembly and debugging are to be performed by the user.)
No. | Item / Description | Unit | Quantity |
1 | XL330-M288-T | Set | 16 |
2 | FPX330-H101 | Pack | 3 |
3 | FPX330-S101 | Pack | 3 |
4 | FPX330-S102 | Pack | 2 |
5 | U2D2 Serial Communication Module | Set | 1 |
6 | YA-EX2DXL Power Extension Board | Piece | 1 |
7 | X3 PIN Servo Cable 20cm | Piece | 5 |
8 | DC5.5*2.5 Power Extension Cable | Piece | 1 |
Some images in the details feature the LEAP HAND with vision-tactile sensors
The integration of vision-tactile sensors with robotic hands represents an important research direction in robotics
Adaptive Grasp Control: Vision-tactile sensors can capture subtle contact changes on objects in real-time, helping the robotic hand flexibly adjust gripping force according to the physical properties of objects, thereby achieving adaptive grasping for various items
. Dexterous Manipulation: By fusing visual and tactile feedback, the robotic gripper achieves generalized dexterous manipulation, demonstrating higher performance, especially when handling complex grasping tasks
Working Principle of Vision-Tactile Sensors
Vision-tactile sensors achieve force perception by calibrating marker vector information, providing high-precision and multi-modal force data