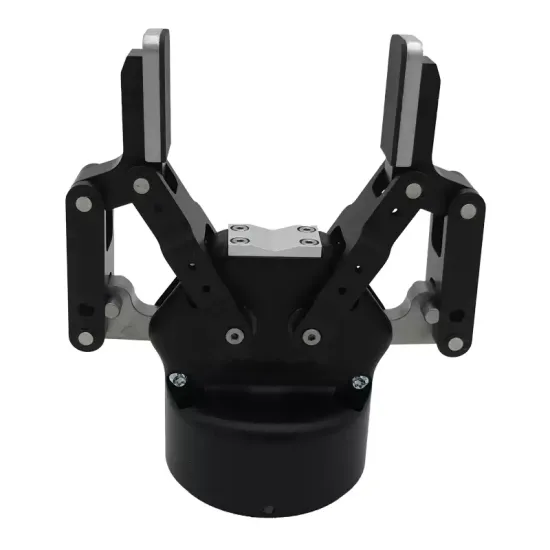
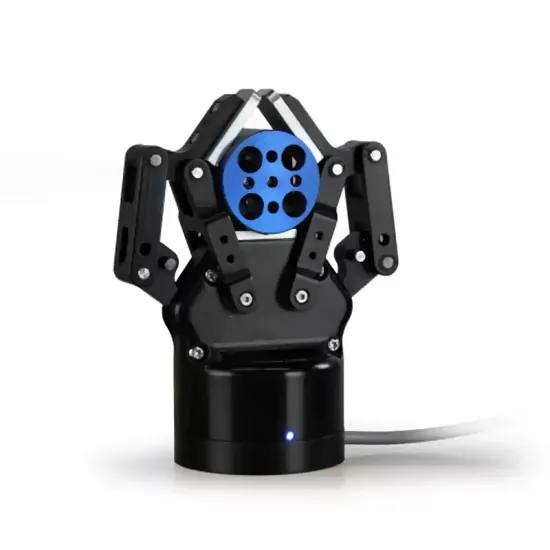


Product Overview
Functional Features
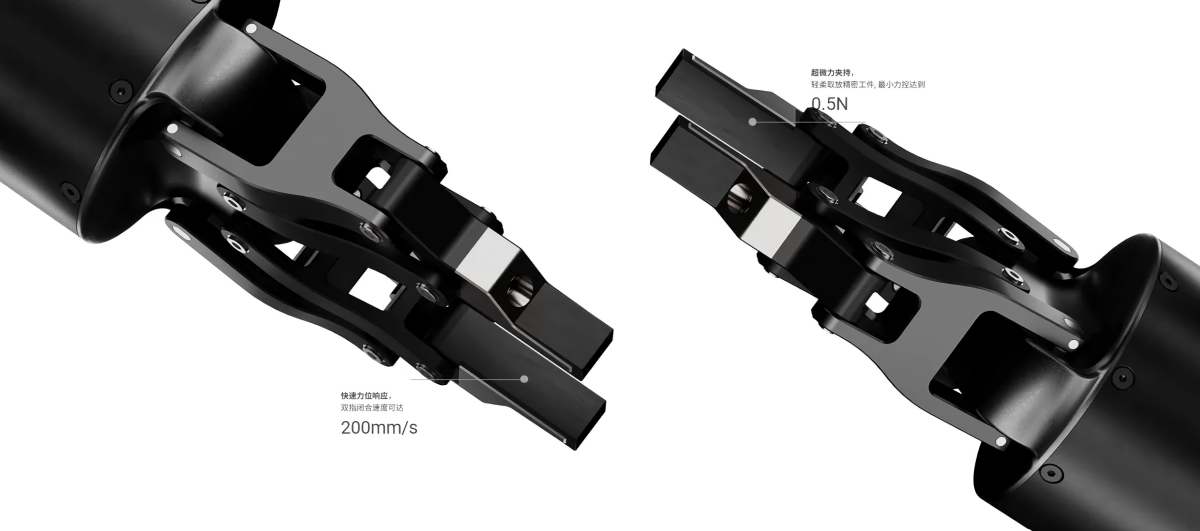
| Provides stable, reliable gripping force; automatically adapts to changes in object dimensions. |
|
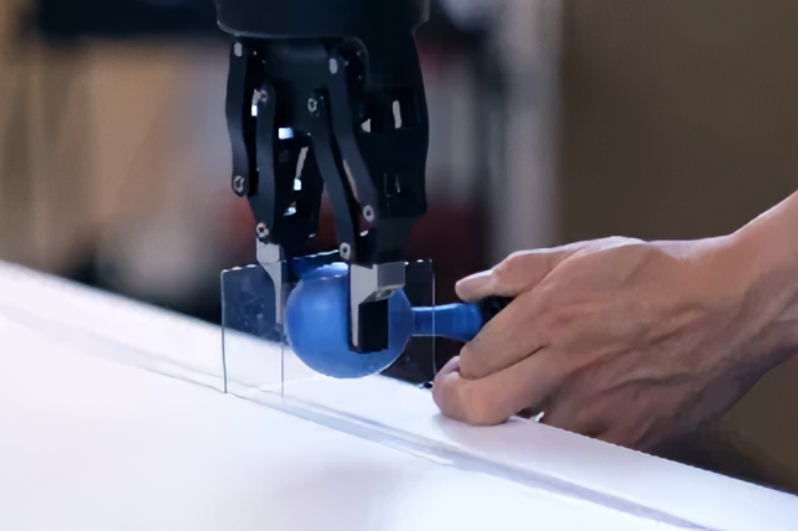
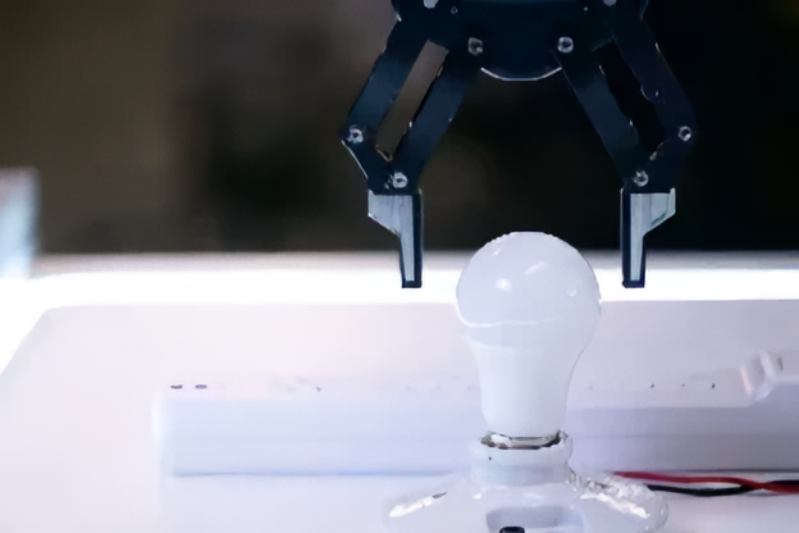
| The clamping force is flexible and controllable, allowing for secondary positioning during the workpiece clamping process. |
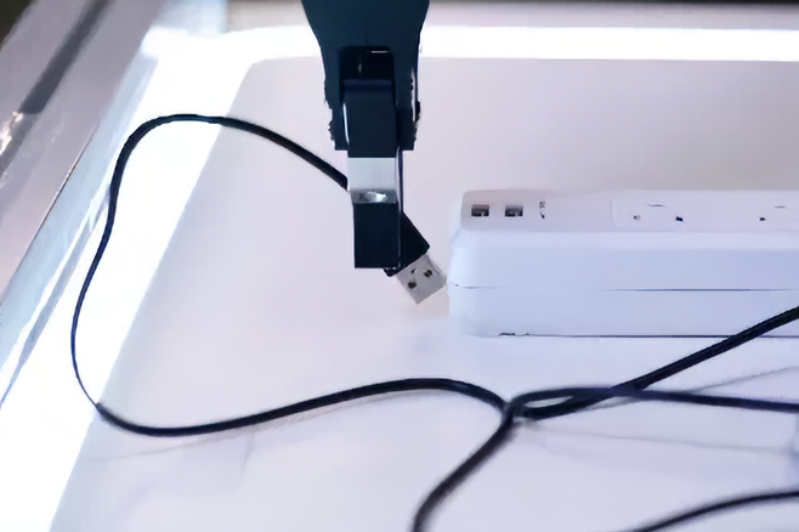
Capable of compliant or contact-based grasping, even in complex environments or operations. |
|
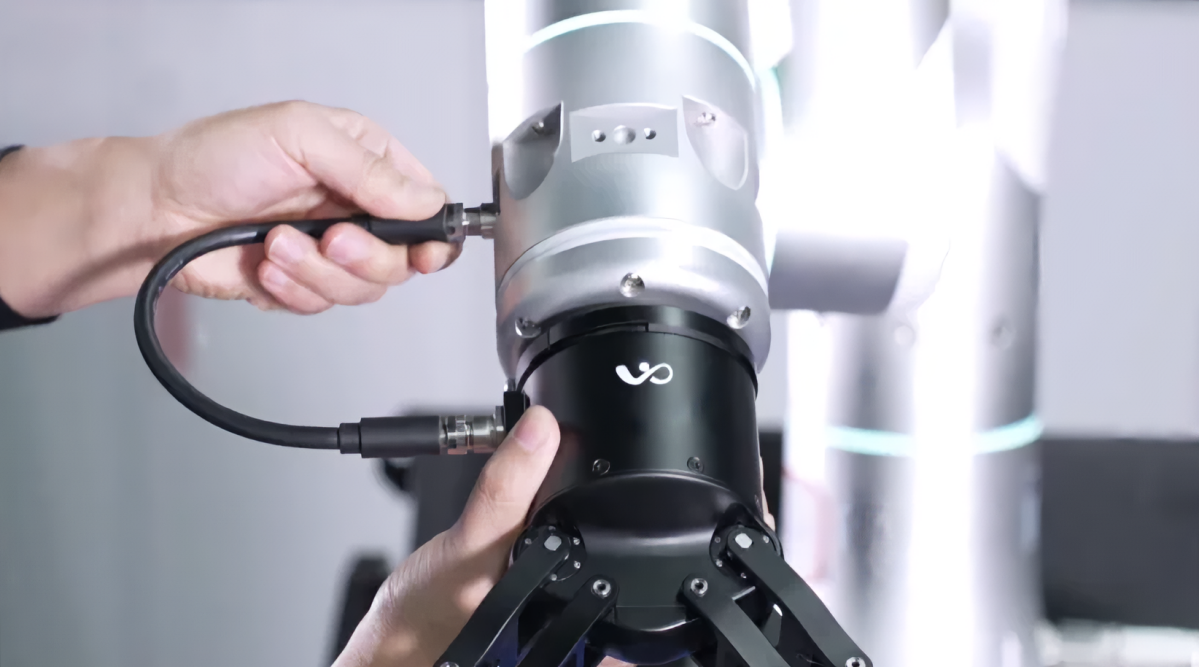
Perfectly compatible with adaptive robots, enabling plug-and-play functionality.
|
|
With an IP67 protection rating, it can adapt to a very wide range of operating temperatures and humidity levels, ensuring stable performance under the vast majority of working conditions. | Complies with the human-robot safety criteria specified in ISO/TS-15066, ensuring safety during human-robot interaction; features an operational lifespan exceeding 10 million cycles and requires no maintenance. |
Product Details
The man-made "biomimetic gecko material" enables passive adhesion—much like a gecko’s toes—granting the "Xingqing" (Star-Engine) system exceptional frictional grip. This allows it to effortlessly pick up objects weighing several kilograms, while also making them easy to release. |
|
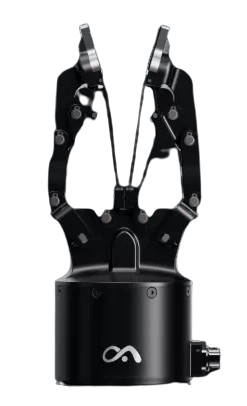
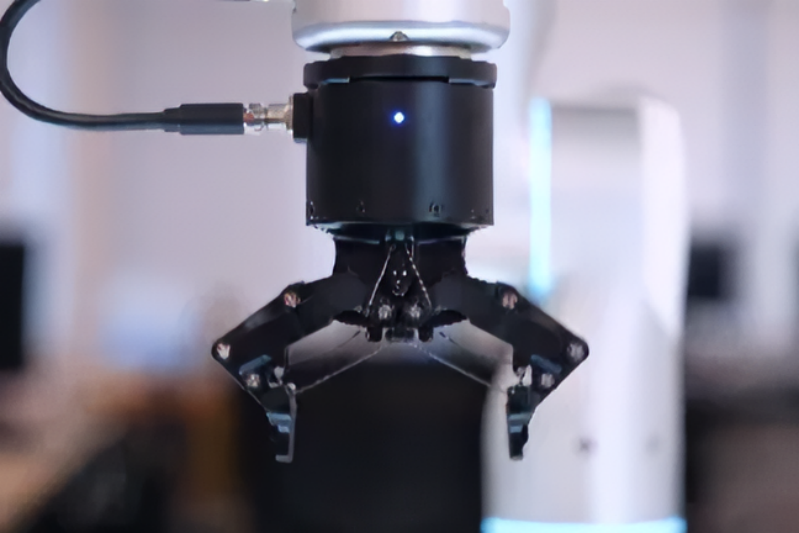
Supports seamless switching between two modes: rigid grasping using fingertips and flexible grasping utilizing gecko-inspired materials |
|
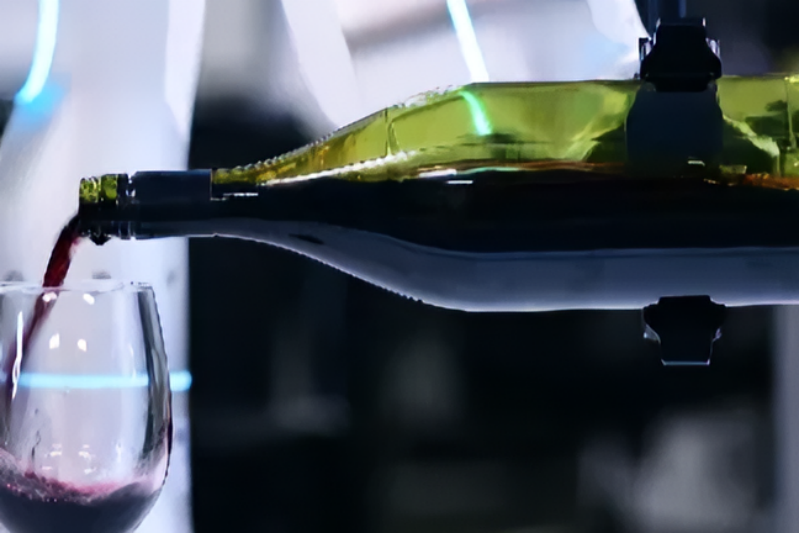
| Complete the tasks by combining rigid and flexible gripping methods. |
Technical Specifications
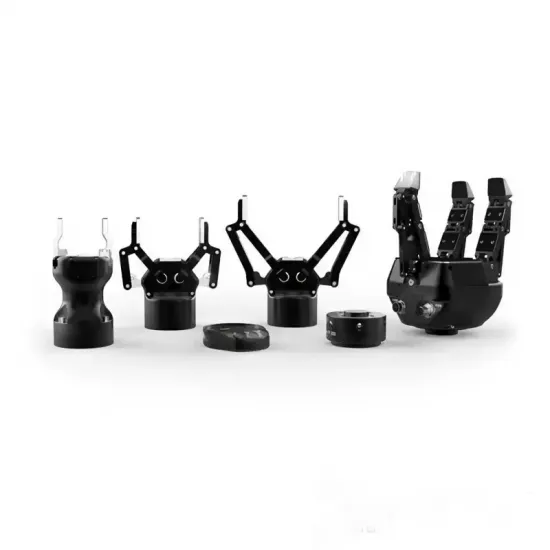
Each model in the Grav series has its own unique characteristics; choose the gripper that best addresses your specific needs.
GRAV | GRAV ENHANCED | |
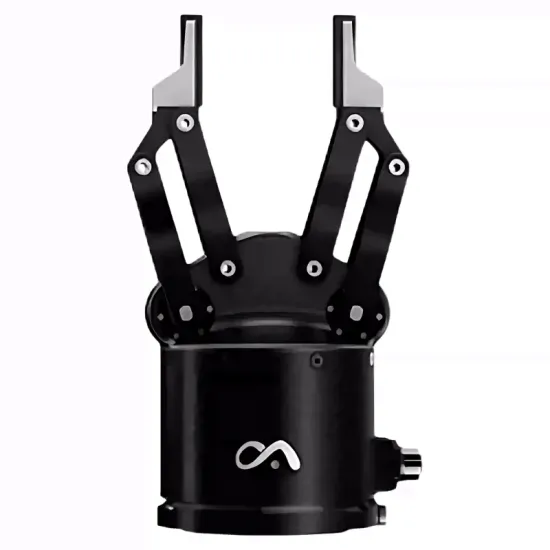
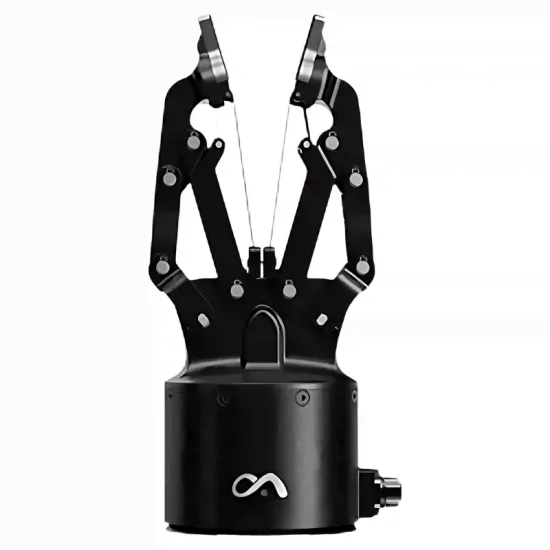
Clamping technology | Two types of force-controlled gripping | Parallel clamping mode V-type clamping mode |
Single-finger travel | 50 mm | 52 mm |
Size | 202 mm x 159 mm x 84 mm | Parallel clamping mode: 211 mm x 180 mm x 84 mm |
Weight | 0.9 kg | 1 kg |
Optimal clamping force range | 1 N to 100 N | 1 N to 30/80 N |
Clamping speed | 1 to 200 mm/s | 1 to 200 mm/s |
Finger position repeatability | 0.1 mm | 0.1 mm |
Force control precision | 1 N | 1 N |
Protection Rating | IP67 | IP67 |
Operating temperature | -20 to +45 °C | -20 to +45 °C |
Communication | Integrated Arm (Modbus RTU) | Integrated Arm (Modbus RTU) |
Mechanical interface | ISO 9409-1-50-4-M6 | ISO 9409-1-50-4-M6 |