

Product Description
BrainCo
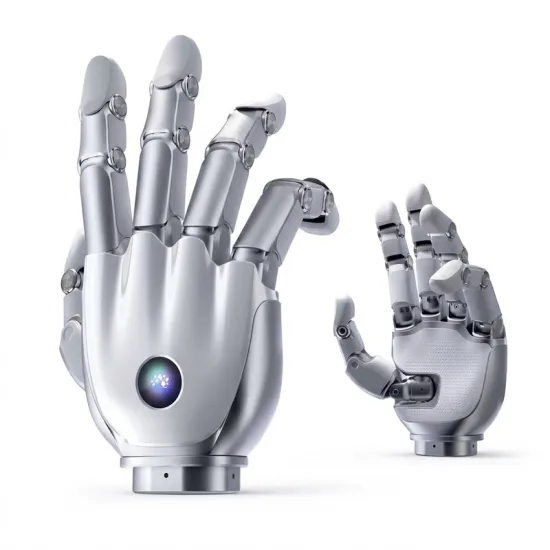
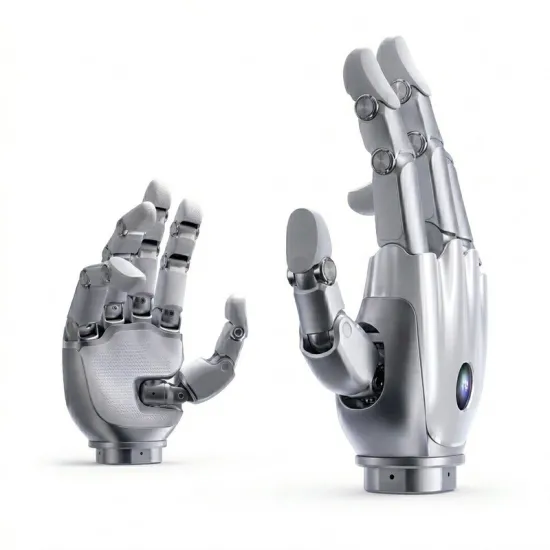
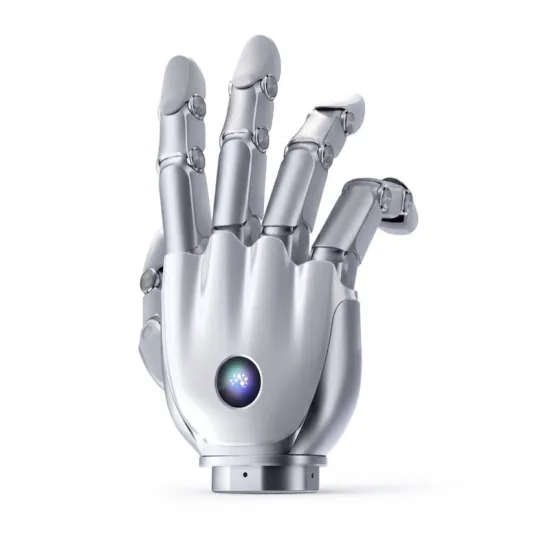
Revo 3 Smart Bionic Hand
Built for Dexterity, Designed for the Future
Full Direct-Drive
Backdrivable
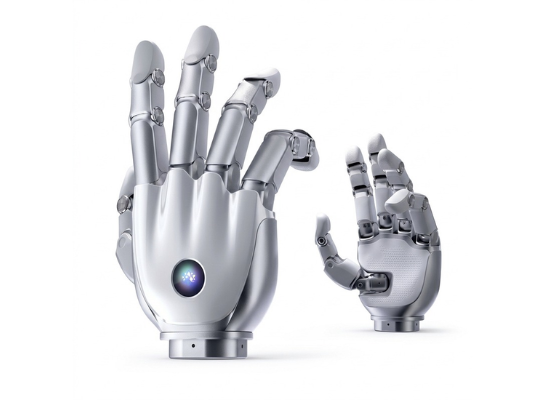
485/CAN FD/EtherCAT Full Protocol Support |  | Out-of-the-box Demo |  | Open-Source Ecosystem |
21 Active DoF | 20 N Fingertip Pinch Force | 70 N Full-Palm Grasping Force | 3 Hz Ultra-Fast Open-Close |
500 Hz Control frequency | 0.01 N Full-Palm Tactile Resolution | 13 Microns Minimum Detectable Visuotactile Deformation | 12-80 V Wide Voltage |
Product parameters
For reference only. Subject to actual delivery.
Category | Parameter | Revo 3 U21 | Revo 3 U21T | Revo 3 U21VT |
Degrees of Freedom | Total DoF | 21 (Full Direct-Drive & Backdrivable) | ||
DoF Distribution | Four fingers 4x4 DoFs, Thumb 5 DoFs | |||
Dimensions | Hand Dimensions | 215 x 105 x 50 mm | ||
Operating Parameters | Supply Voltage | 12-80V | ||
Max Current | 10A (24V) | |||
Active Grasping Force | >70 N | |||
Fingertip Max Pinch Force | >20 N | |||
Total Hand Payload | 20 kg | |||
Four-Finger Payload | 5 kg | |||
Repeatability | 0.1° | |||
Joint Open/Close Speed | 3 Hz | |||
Range of Motion | Five-Finger Opposition | Four fingers / Thumb reach palm (Kapandij test full score) | ||
Min Grasp Diameter | 10 mm | |||
Max Grasp Diameter | 150 mm | |||
Hardware Configuration | Communication Interface | EtherCAT / CANfd / RS-485 | ||
Communication Frequency | 500 Hz | |||
Sensors | IMU (Mainboard), Temperature (Mainboard) | |||
Control Modes | Position, MIT Force-Position, Admittance, Zero-Torque | |||
Tactile Sensing | Tactile Sensors | / | Full-Palm Array Tactile | Full-Palm Array Tactile + Fingertip Visuotactile |
Measuring Range | / | 0-25 N | 0-25 N | |
Resolution | / | 0.01 N | 0.01 N | |
Min Measurable Deformation | / | / | 130 μm | |
 | 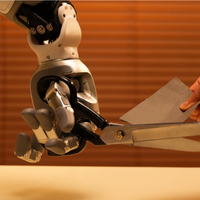 | 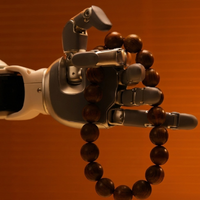 | 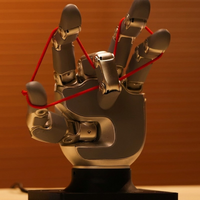 |
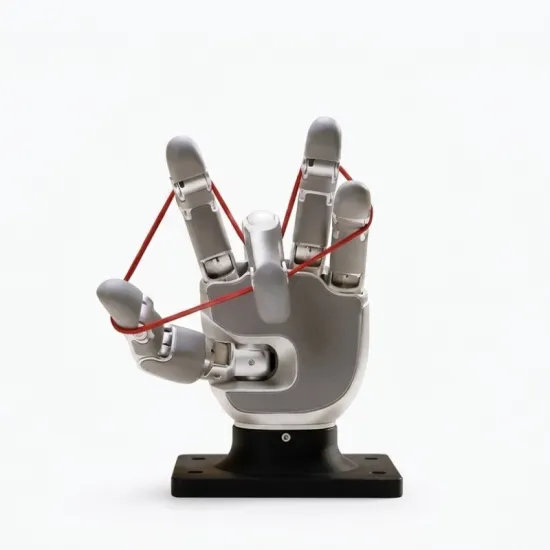
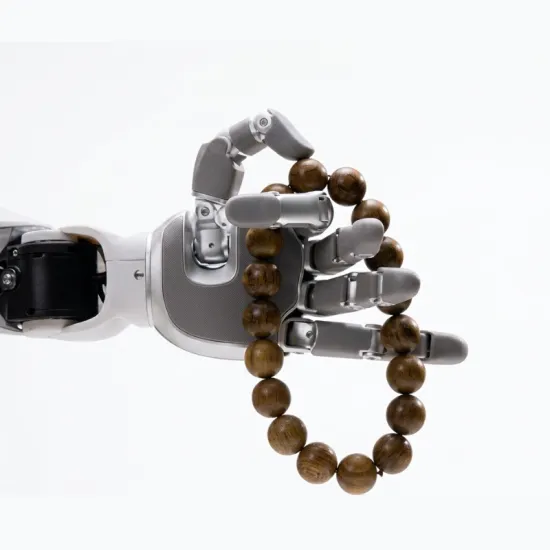
| Solving a Rubik's Cube | Using scissors | Rolling prayer beads | Playing cat's cradle |