


Abstract:A new omnidirectional chassis for humanoid robots has been unveiled, offering advanced mobility, intelligent perception, and high operational efficiency. The platform aims to accelerate the deployment of humanoid robots in industrial, commercial, and research environments.
A groundbreaking omnidirectional chassis designed specifically for humanoid robots has been officially introduced, marking a major advancement in humanoid mobility systems. Leveraging nine years of experience in industrial robotics and large-scale production capabilities for Autonomous Mobile Robots (AMRs), the platform addresses persistent challenges such as high costs, limited battery life, and low adaptability in complex environments.
The chassis enhances robot motion from basic walking to a more intelligent mobility capability. It supports lateral movement, S-curve navigation, smooth curved trajectories, and continuous curvature turning, delivering fluid and natural motion. Production-line testing and evaluations by leading robotics companies confirmed positioning accuracy within ±10 mm, overcoming the instability and sluggishness often seen in traditional legged robots.
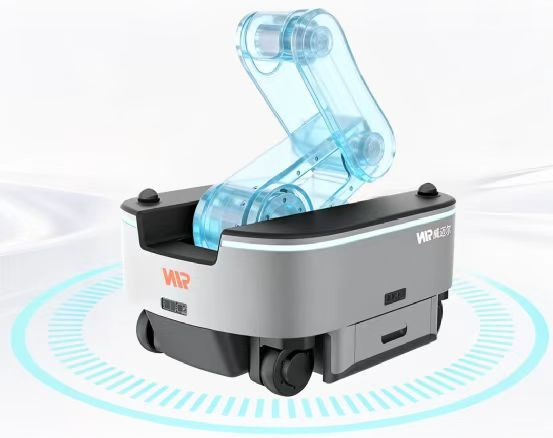
Equipped with a 360-degree full-view 3D vision sensor, the system enables real-time environmental perception and proactive obstacle avoidance. The platform also features hot-swappable batteries, allowing full power recovery in about one minute, which significantly improves operational continuity and efficiency for extended usage.
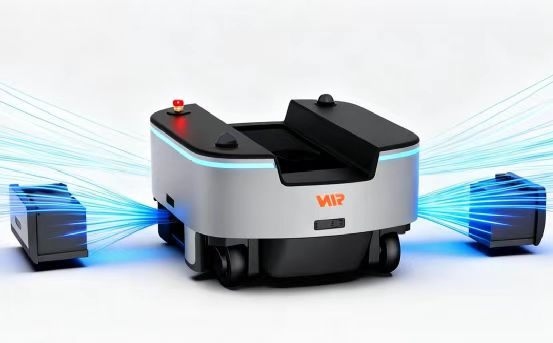
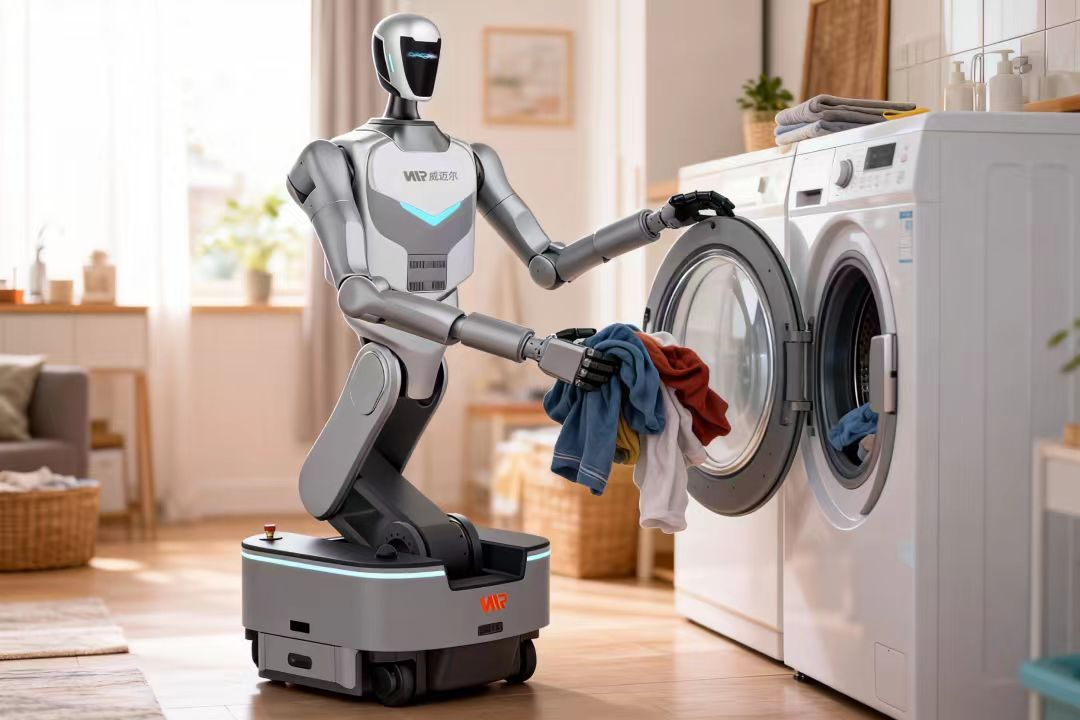
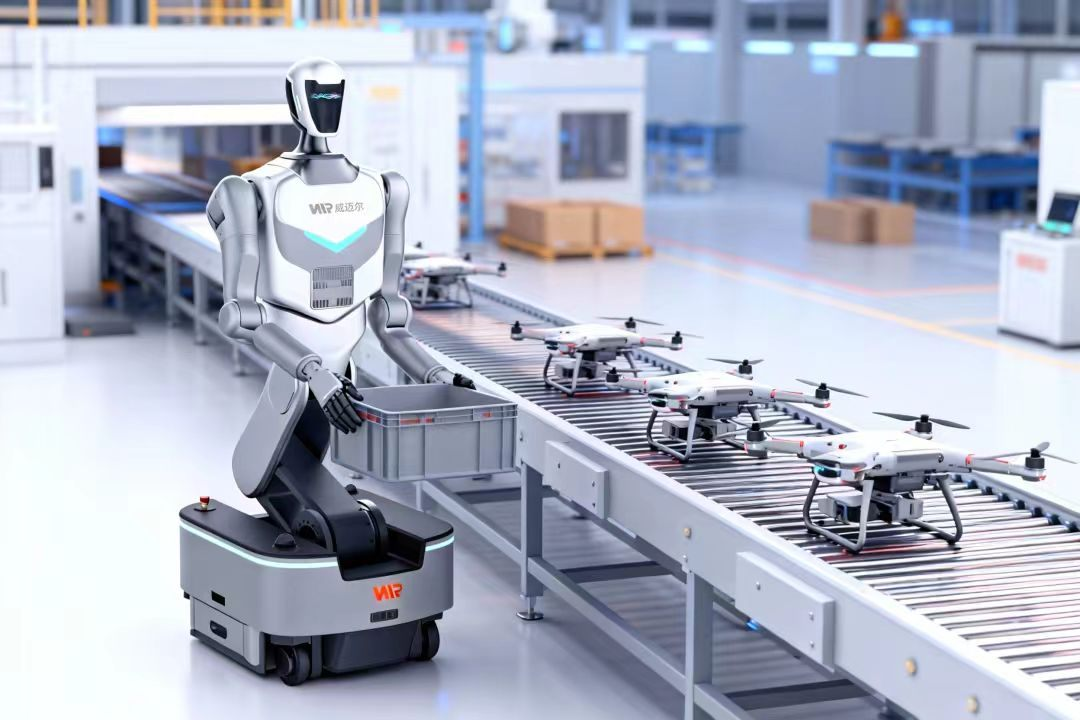
The chassis uses a plug-and-play hardware and software design, reducing integration complexity and supporting customization for multiple robot models and applications. This versatility positions it as a core mobility platform for humanoid robots in industrial manufacturing, reception and guidance, household services, and research, facilitating the transition from laboratory prototypes to real-world deployment.
 |  |
Development leaders emphasize that the goal is not just to provide robots with the ability to walk, but to equip them with a mobility system capable of understanding and responding intelligently to real-world scenarios. Continued collaboration with global partners will focus on technological iteration and expanding intelligent mobility capabilities.

