


Summary:DG-5F-S is a compact humanoid robotic hand designed for high-precision dexterous manipulation. It combines a lightweight structure, 20 DoF architecture, and upgraded actuator system to improve integration, cost efficiency, and real-world usability in humanoid platforms.
The DG-5F-S is a next-generation humanoid robotic hand engineered to enhance dexterous manipulation while reducing size, weight, and system complexity. It is built on a redesigned proprietary actuator architecture that prioritizes high torque density, durability, and long-term maintainability, while eliminating reliance on general-purpose actuator components.
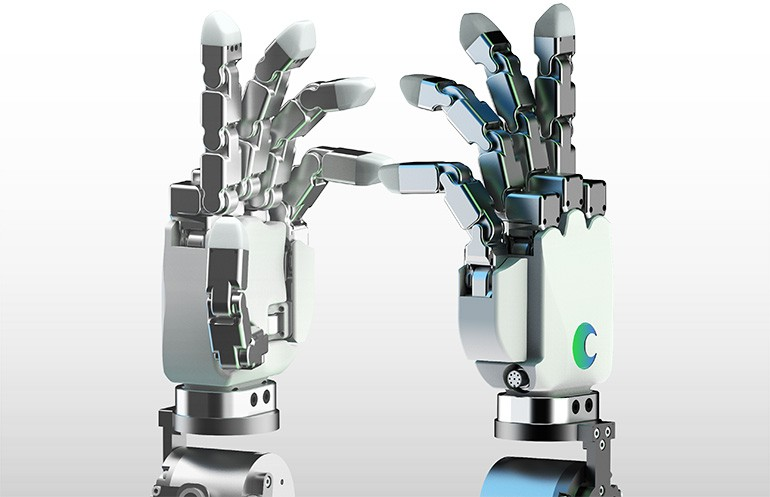
The DG-5F-S robotic hand.
The hand preserves a high-fidelity anthropomorphic structure with 20 degrees of freedom across five fingers. Each finger contains four independently driven joints, enabling precise replication of human hand kinematics. This configuration allows for complex grasping patterns, fine motor control, and stable interaction with objects of varying shapes, textures, and rigidity.
A key upgrade in the DG-5F-S is its compact and lightweight design. Weighing under 1 kg (2.2 lbs), it achieves a significantly reduced footprint compared to previous iterations, making it easier to integrate into a wide range of humanoid robotic platforms without requiring major structural modifications.
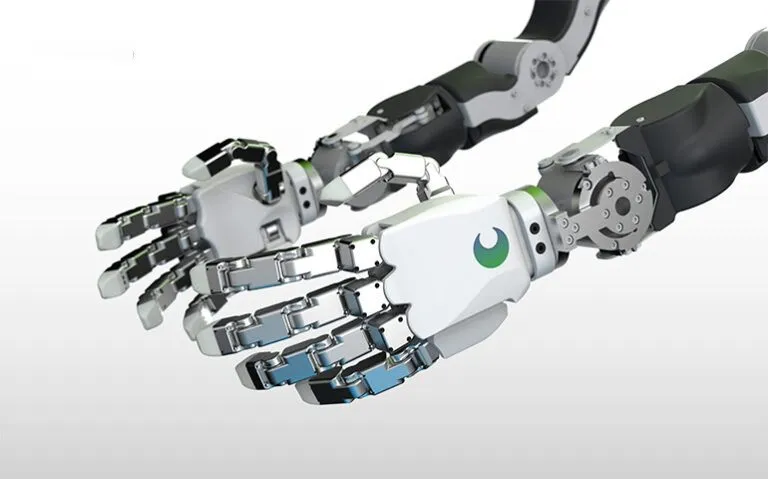
The system uses a direct-drive actuation mechanism, minimizing transmission backlash and improving positional accuracy as well as responsiveness. This results in smoother control behavior and more intuitive manipulation performance, especially in delicate or precision-demanding tasks.
The DG-5F-S is also designed for broader system compatibility. It supports standard industrial communication protocols, allowing straightforward integration with existing robotic control stacks. In addition, it can be paired with tactile sensing modules and advanced manipulation algorithms, enabling enhanced feedback-driven grasping and adaptive object handling.
Cost optimization is another major improvement. The DG-5F-S is positioned at approximately 60% of the cost of its predecessor, making advanced dexterous hand technology more accessible to research institutions, startups, and industrial users.
Customization options further expand its applicability, including sensor integration, protective housing configurations, and algorithm-level tuning for specific operational scenarios. These features support deployment across research, service robotics, and industrial automation environments.
Overall, the DG-5F-S represents a refined balance between performance, size, and affordability, aiming to accelerate the transition of humanoid robotic hands from experimental prototypes to scalable commercial components.

