

Product Description
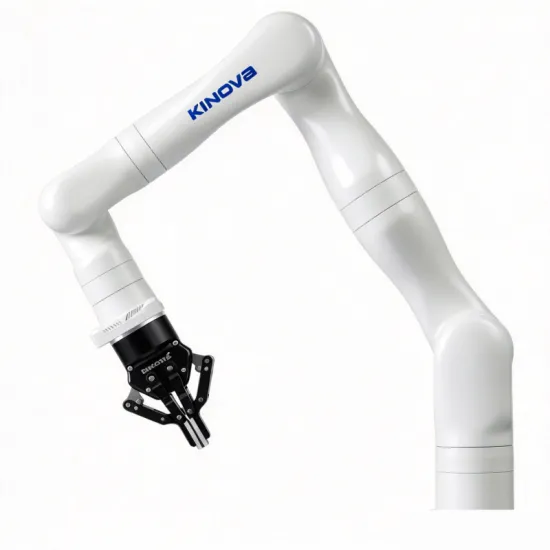
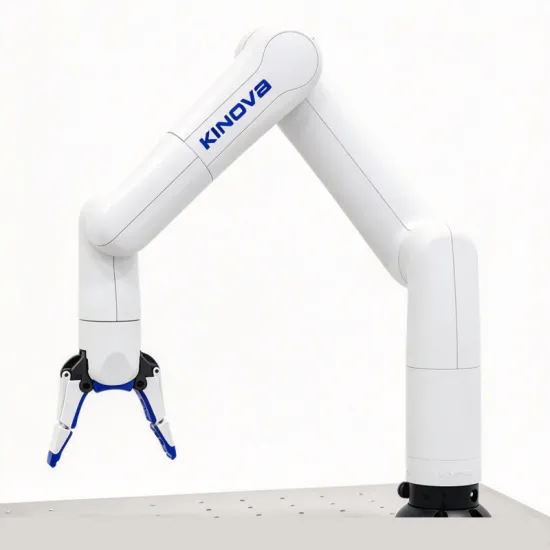
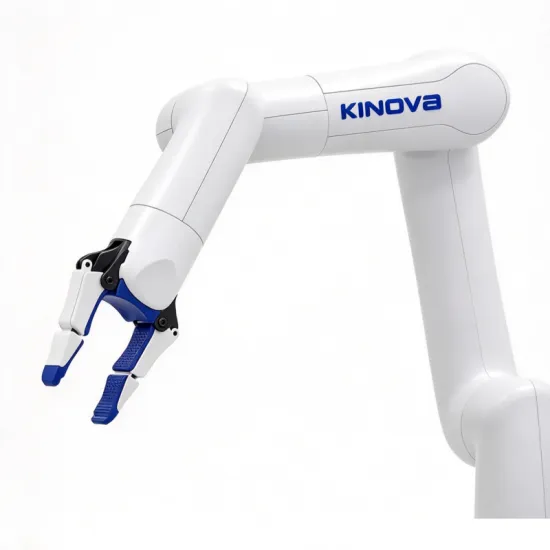
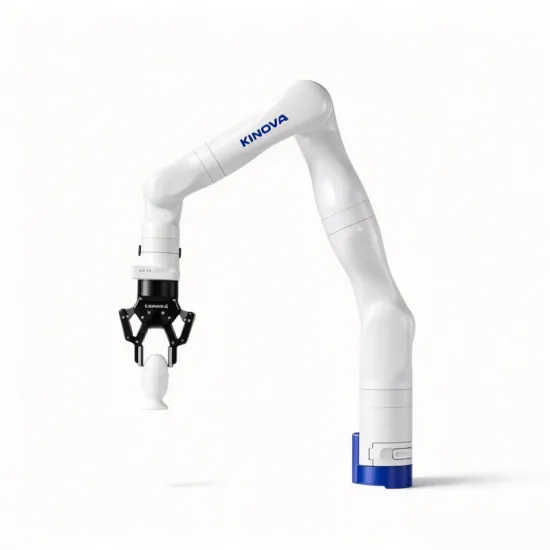
Ultra-lightweight modular collaborative robot
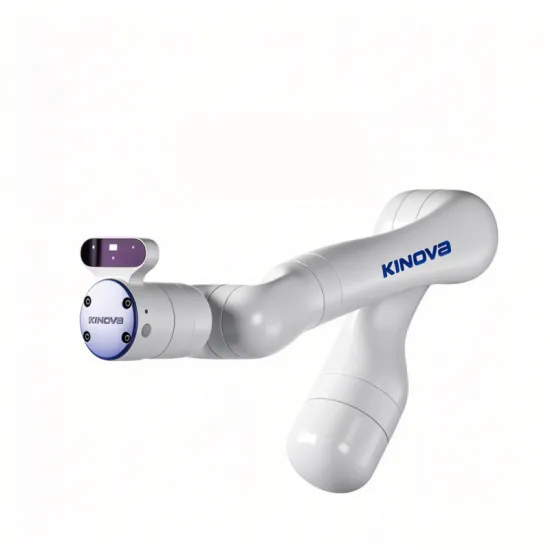
Optional integration
- 2D/3D VISION modules
- High-level and low-level control
- Open end-effector interface module
- Smart actuators with integrated torque sensors
Functional Features
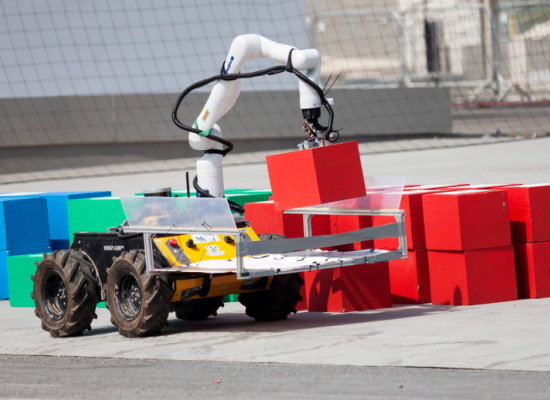
Gen3 Robot - 6DoF Collaborative Robot
Four key advantages
1. 6 degrees of freedom with torque sensors built into every joint.
2. Self-weight of 7.2 kg, payload of 4 kg, low power consumption of 36 W.
3. Embedded control cabinet and embedded vision.
4. Supports ROS and multiple programming methods.
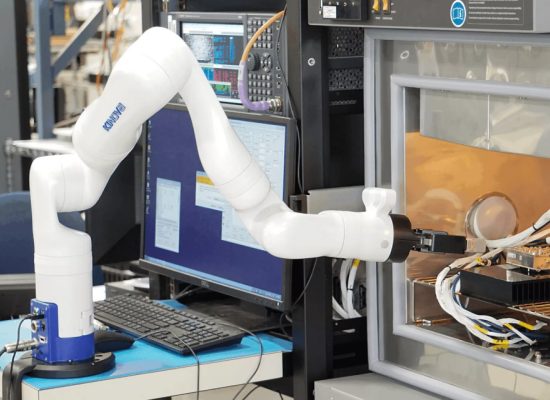
Gen3 Robot - 7DoF Collaborative Robot
Four key advantages
1. 7 degrees of freedom with torque sensors built into every joint.
2. Self-weight of 8.2 kg, payload of 4 kg, low power consumption of 36 W.
3. Embedded control cabinet and embedded vision.
4. Supports ROS and multiple programming methods.
Product Display
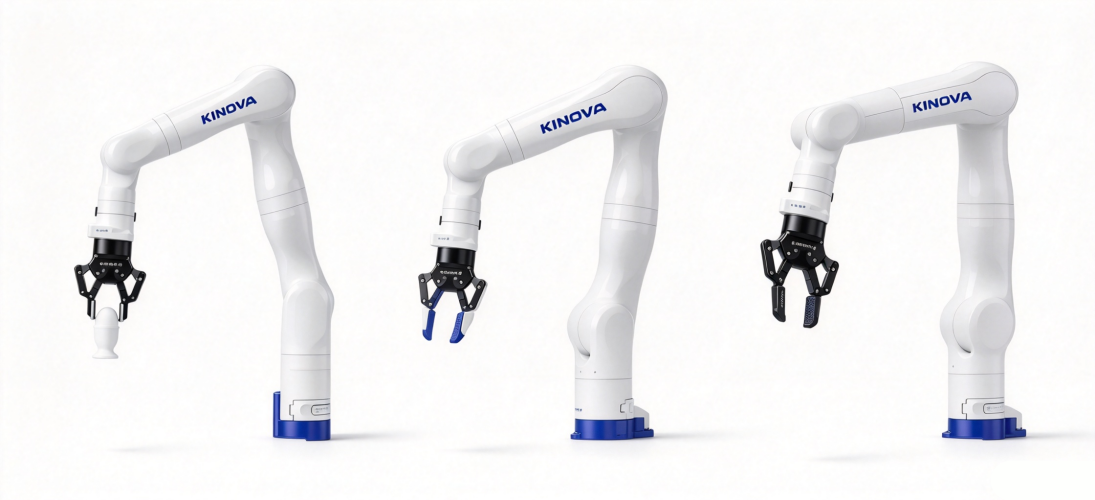
Plug-and-play open-source robot arm
Take your project to the next level through simple integration and the KINOVA "Kortex" open API software
- Closed-loop 1 kHz low-level control
- Gazebo and MoveIt simulation environments
- ROS, MATLAB and Simulink software packages
- Advanced programming in C++ and Python
- Intuitive web application accessible from any desktop or mobile device
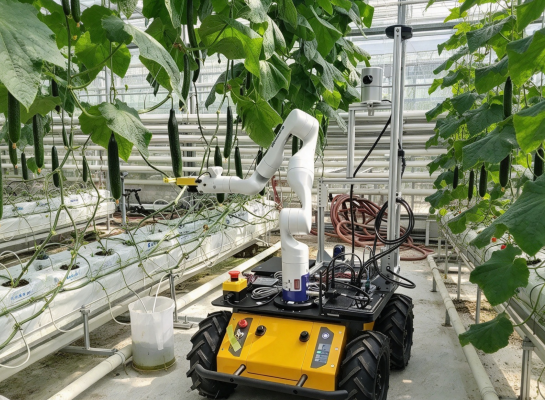
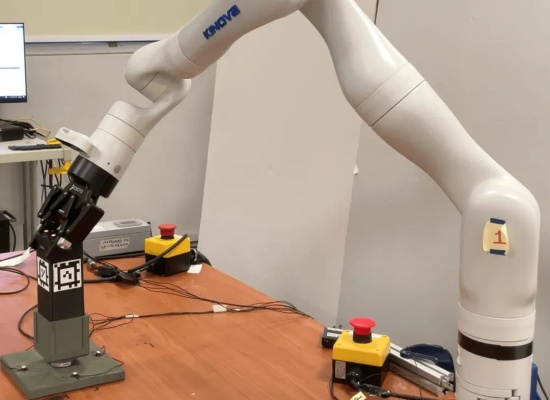
Open technology for AI and machine learning
Dynamic grasping;Deep learning;Vision-based grasping;Dextrous assembly;Mobile manipulation
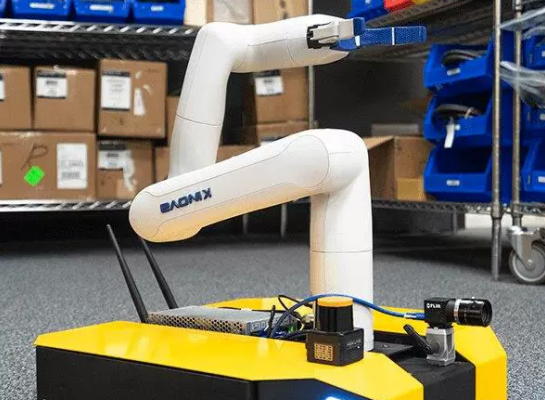
Designed for safe and efficient control in real environments
Ultra-lightweight;Energy-efficient;Portable;Superb payload-to-weight ratio
Product parameters
Parameter | Gen3 6DOF | Gen3 7DOF |
Technical Specifications | ||
Degrees of freedom | 6 | 7 |
Payload (full reach) | 2 kg | 2 kg |
Payload (mid-range reach) | 4 kg | 4 kg |
Self-weight | 7.2 kg | 8.2 kg |
Reach | 902 mm | 902 mm |
Max Cartesian translational speed | 50 cm/s | 50 cm/s |
Joint range after start-up (software limitation) | Unlimited | Unlimited |
Power supply voltage | 18-30 VDC, 24 VDC nominal | |
Average power | 36 W | 36 W |
Ingress protection | IP33 | IP33 |
Operating temperature | -30 °C to 35 °C | |
Sensors | torque, position, current, voltage, temperature, accelerometer and gyroscope | |
Interfaces | ||
Software | Kinova Cortex | |
Internal communication | 2 × 100 Mbps Ethernet | |
API compatibility | Windows 10, Linux Ubuntu 18.04, ROS Melodic | |
Programming languages | C++, Python, MATLAB | |
Basic interfaces | USB, Ethernet, HDMI, Wi-Fi, Digital/IO | |
End-effector interface | RS-485, Ethernet, GPIO, PC, UART, 24 V supply @1A | |
Control frequency | 1 kHz | 1 kHz |
Low-level control | position, velocity, current, torque | |
High-level control | Cartesian position/velocity, joint position/velocity, force, torque | |
Vision (optional) | ||
Color sensor | 1920 × 1080 @ up to 30 fps; FOV up to 65°±3% (diagonal); focus range 30 cm to infinity | |
Depth sensor (Intel RealSense) | 480 × 270 (16:9) @ up to 30 fps; FOV up to 72°±% (diagonal); minimum depth distance 18 cm | |