

Details & Images
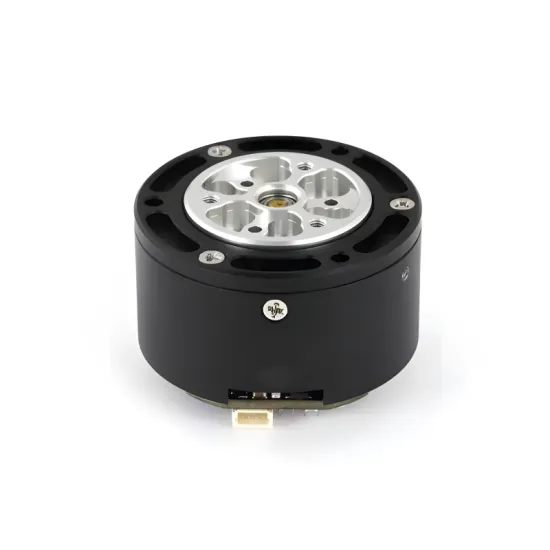
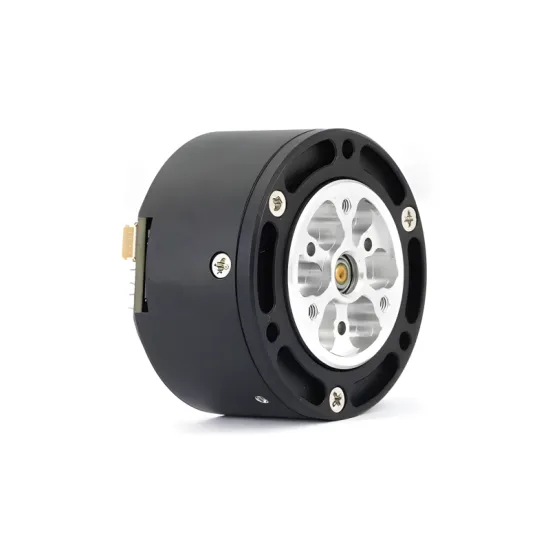
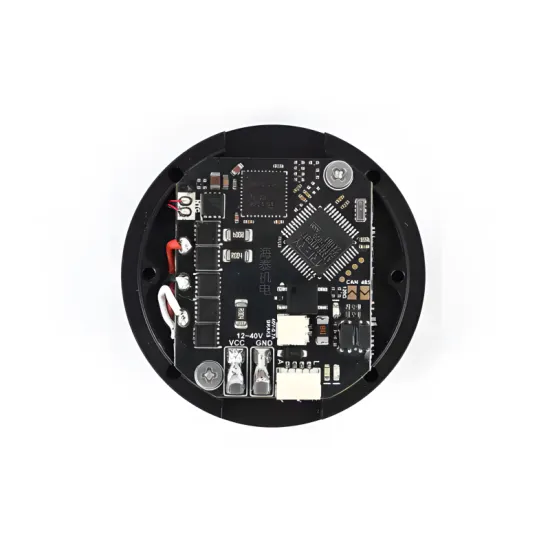
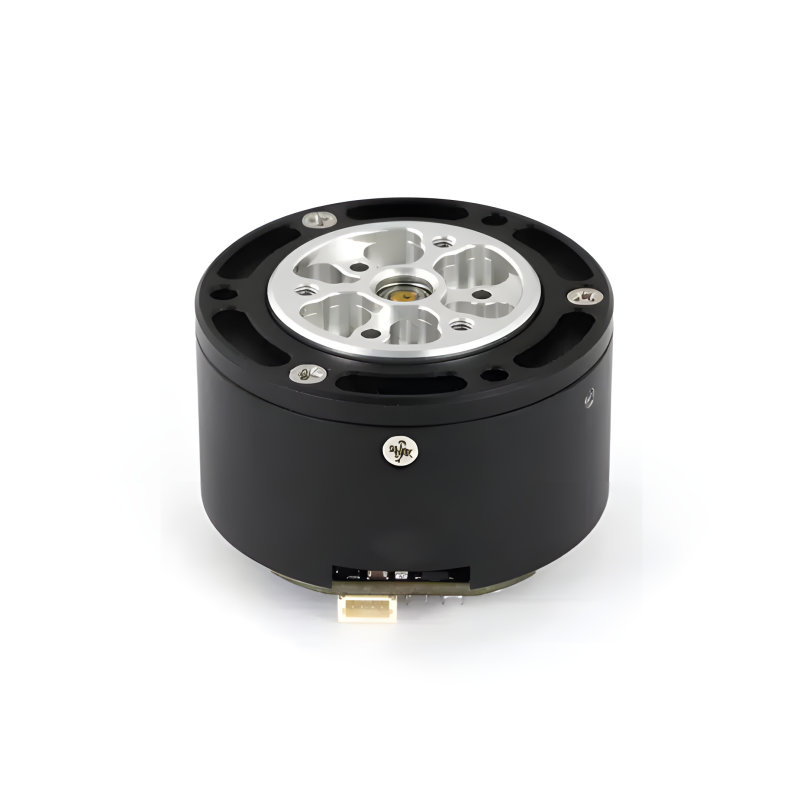
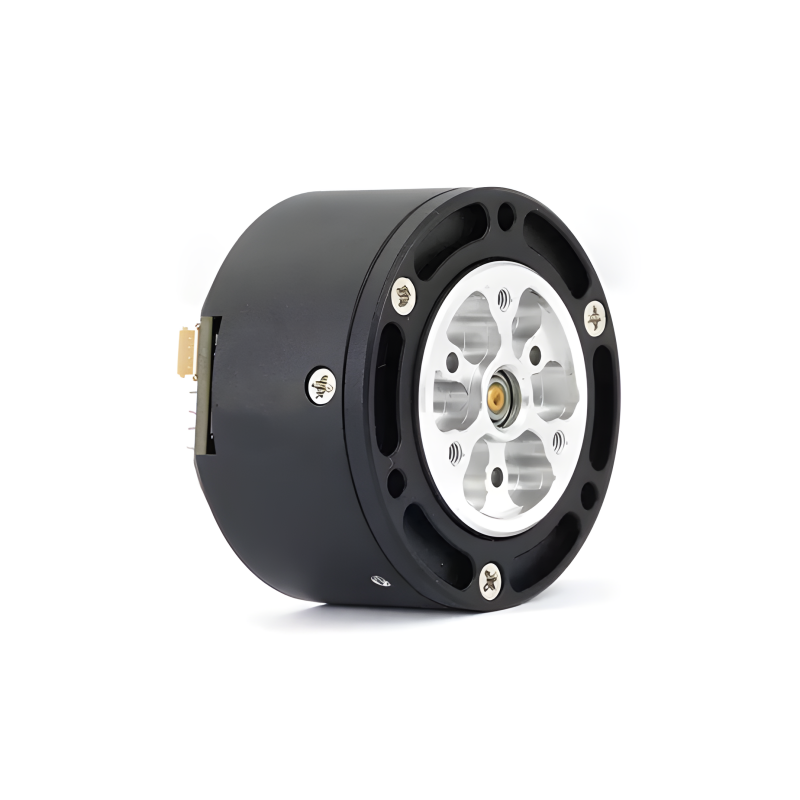
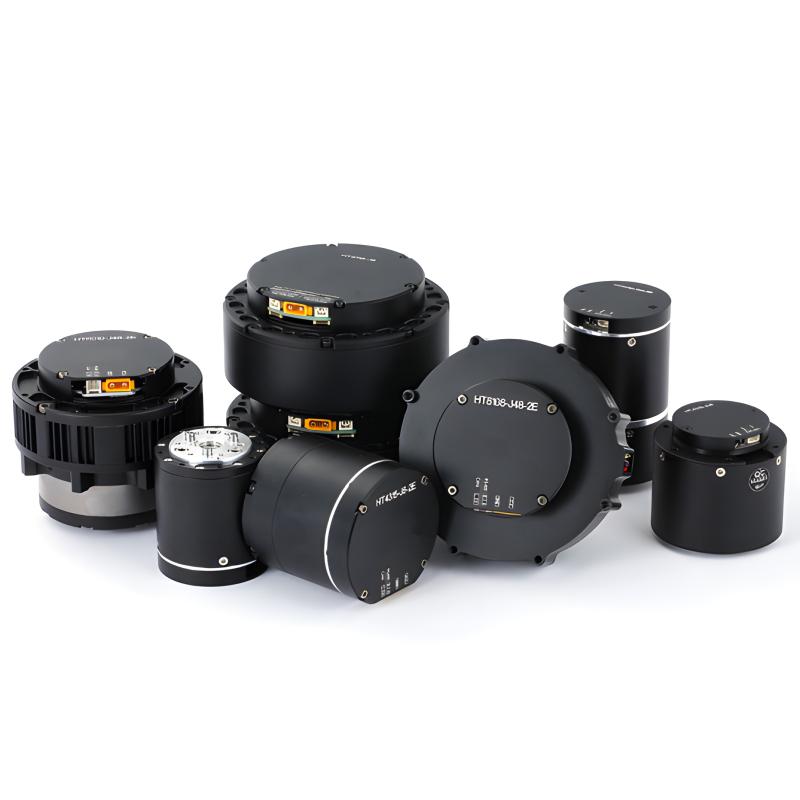
Robot Joint Motor
Integrated Planetary Module
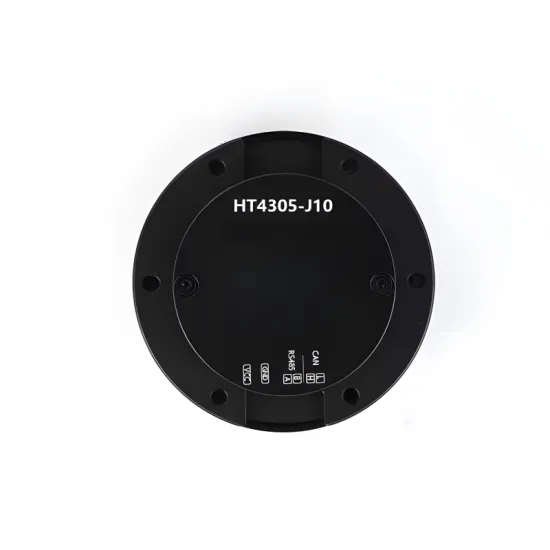
Motor Model: HT4305-J10 Rated Torque: 1 N·m Communication Type: RS485 & CAN Motor Dimensions: Ø53 mm × 32 mm |
|
Product specifications.
Servo motor | ||
Factory Direct Sales | Quality Guaranteed | Reduction ratio1:10 |
Details/Model | Unit | HT4305-J10-V2 | |
Driver Model | / | GDZ34 | GDZ34H |
Winding Type | △/Y | Y | Y |
Rated voltage | V | 24 | 48 |
Voltage Range | V | 12~40 | 12~48 |
Rated Power | W | 48 | 96 |
Rated torque | N.M | 1 | 1 |
Peak torque | N.M | 5.61 | 5.61 |
Rated Speed after reduce | RPM | 312 | 736 |
Max Speed after reduce | RPM | 402 | 779 |
Rated current | A | 2 | 2 |
Peak current | A | 19.55 | 19.55 |
Interphase resistance | Ω | 1.113 | 1.113 |
Interphase inductance | uH | 283.957 | 283.957 |
Speed constant | rpm/v | 16.20 | 16.20 |
Torque constant | N.M/A | 0.5 | 0.5 |
Number of pole pairs | Pairs | 14 | 14 |
Gear Rate | / | 10:1 | 10:1 |
Gear type | / | Planetary | Planetary |
Reducer gear material | / | ALU (default)or STEEL | ALU (default)or STEEL |
Reducer gear backlash | arcmin | 15 | 15 |
Motor weight without driver | g | 140 | 140 |
Motor weight with driver | g | 150 | 150 |
Size without Driver | mm | Ø53*26 | Ø53*26 |
Size with Driver | mm | Ø53*32 | Ø53*32 |
Max.Axial load | N | 125 | 125 |
Max.Radial load | N | 500 | 500 |
Noise | dB | <60 | <60 |
Communicatio | / | CAN & RS485 | CAN & RS485 |
the second encoder on the output shaft | / | NO | NO |
Protection grade | / | IP54 | IP54 |
Working temperatur | ℃ | -20 ~ +80 | -20 ~ +80 |
Resolution of the encoder on the driver | Bit | 14 | 14 |
Can support separate encoder or not | / | NO | NO |
Can support custom brakes | / | YES | YES |
HT4305-J10-v2 Motor Installation Drawing
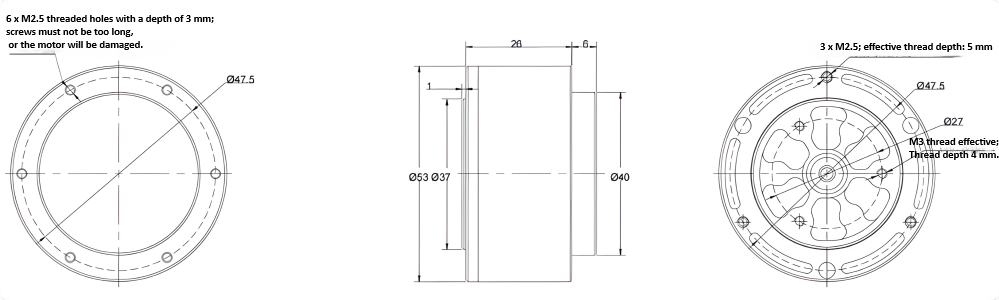
(with GDZ drive)
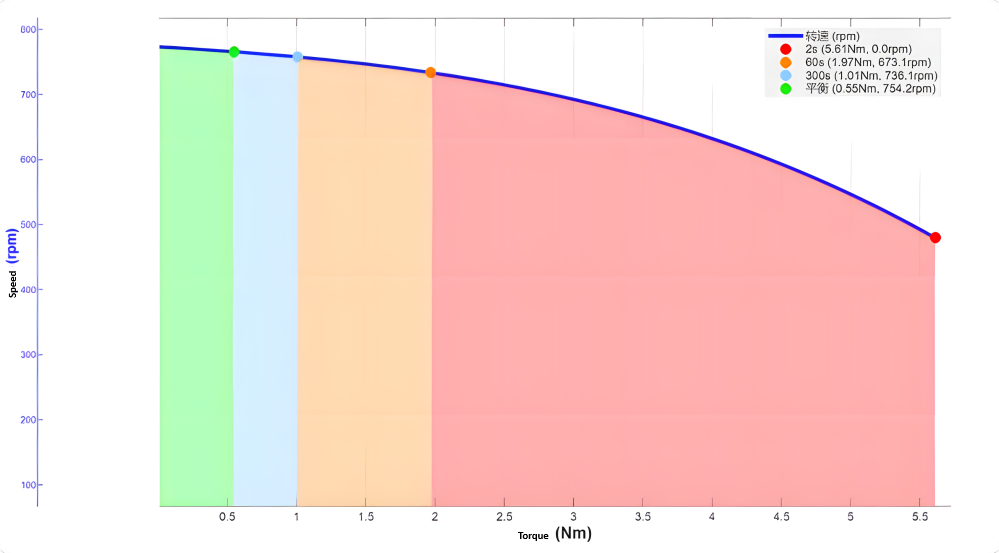
HT4305-J10 Motor Characteristic Curve @ 48V
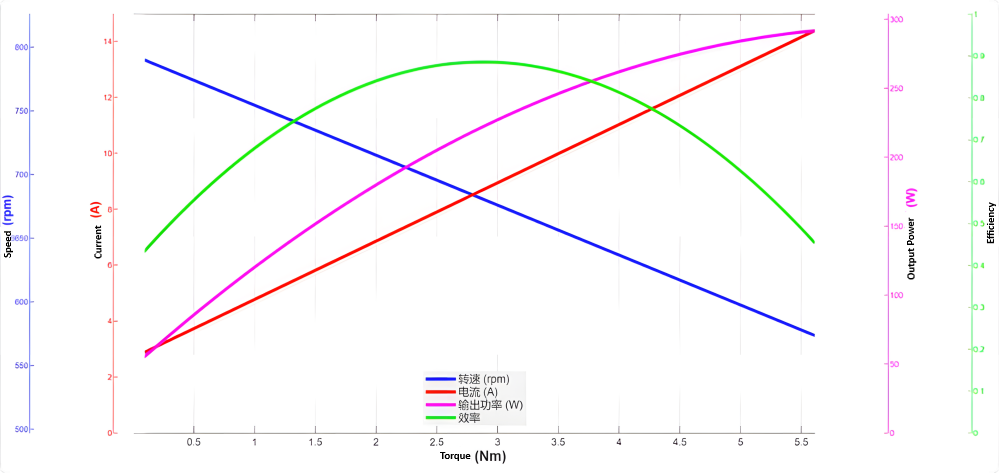
HT4305-J10 Motor Operating Range Curve @ 48V
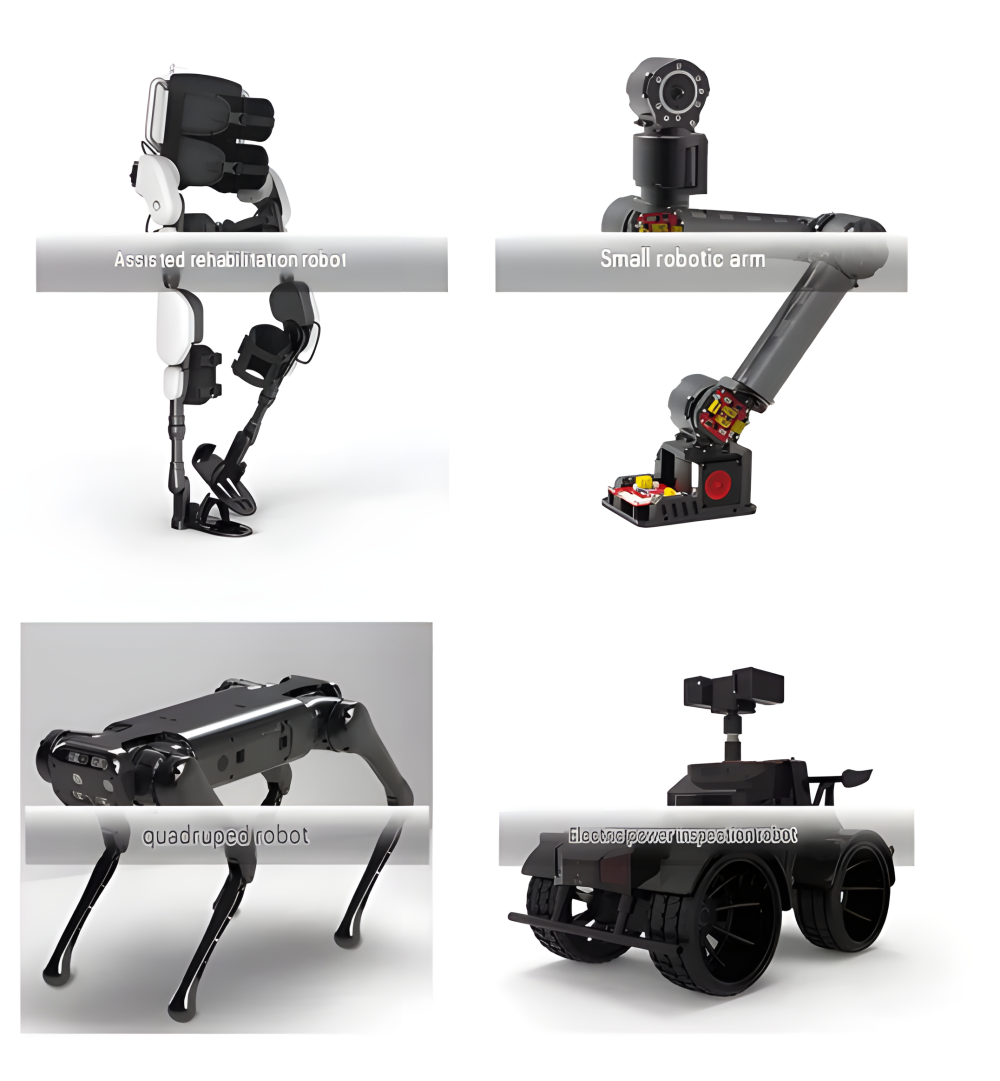
Wide Range of Applications
Widely used in legged robots, robotic arms, and SCARA robots.