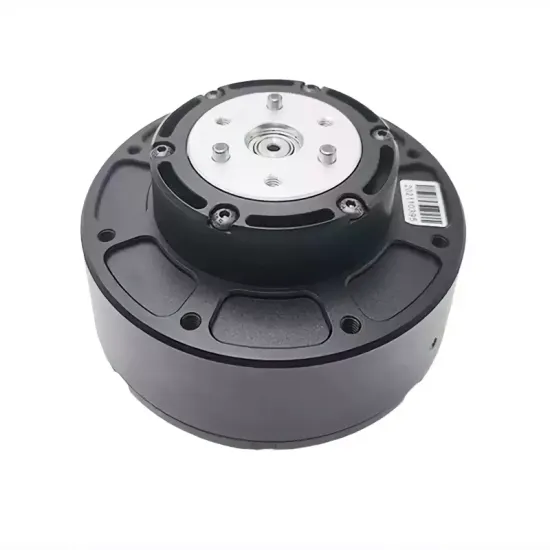
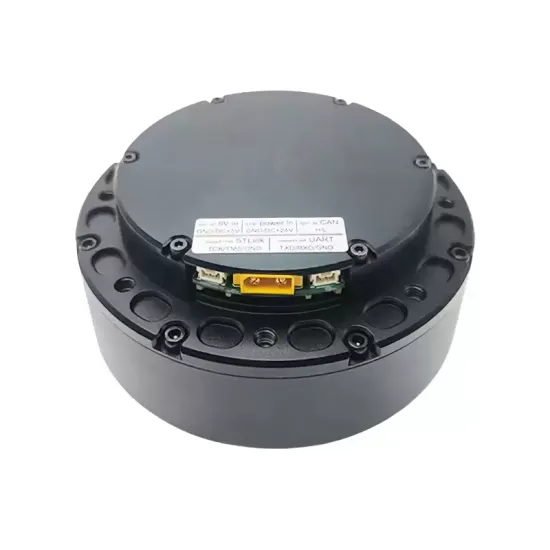
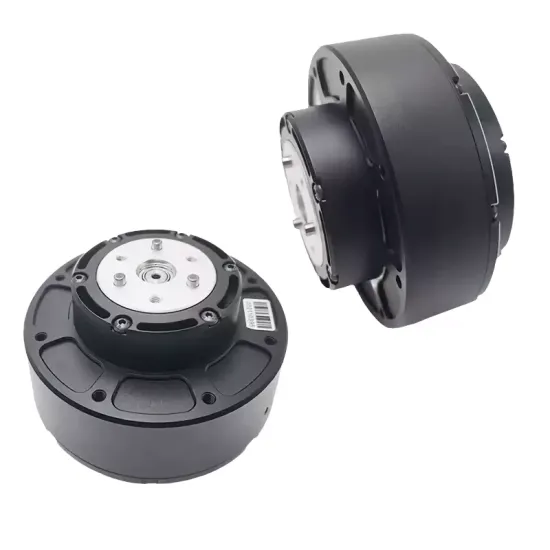
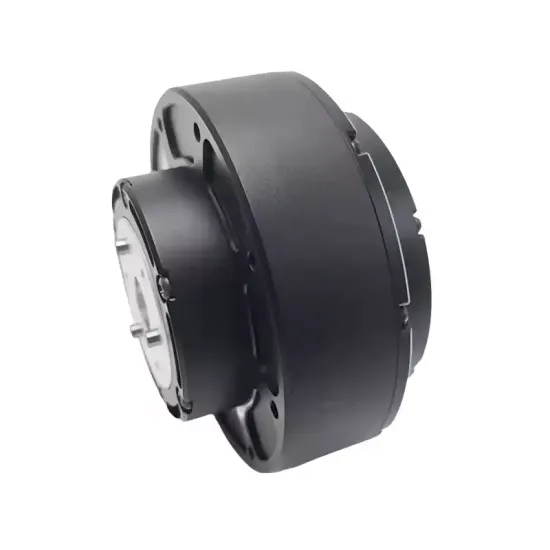


|
|
HT8108-J36 Characteristic Curves @ 36V
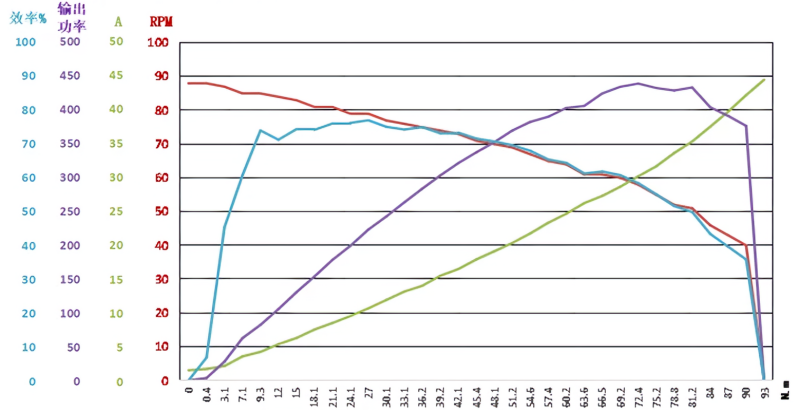
—Rotational speed—Electric current—Output power—efficiency
| Motor Model | Unit | HT8108-J36 (Former name(s)HT-03-36) |
Nominal voltage | V | 36 |
Voltage Range | V | 24~48 |
Power | W | 100 |
Nominal torque | N.M | 24 |
Stall torque | N.M | 93 |
Nominal Speed after reduce | RPM | 40 |
Max Speed after reduce | RPM | 110 |
Nominal current | A | 17 |
Stall current | A | 45 |
Phase to phase resitance | Ω | 0.118 |
Phase to phase inductance | mH | 0.05 |
Speed constant | rpm/v | 2.5 |
Torque constant | N.M/A | 1.45 |
Rotor inertia | gcm^2 | 55 |
Number of pole pairs | Pairs | 21 |
Gear Rate | / | 36:1 |
Gear type | / | Planetary |
Reducer gear material | / | STEEL |
Reducer gear backlash | arcmin | <6 |
Motor weight without driver | g | 720 |
Motor weight with driver | g | 760 |
Size without Driver | mm | Ø96*52.5 |
Size with Driver | mm | Ø96*60 |
Max.Axial load | N | 900 |
Max.Radial load | N | 1000 |
Noise | dB | <65 |
Protection grade | / | Only the motor has an IP54 protection rating |
Working temperature | °C | -20~+80 |
MIT Open Source Driver Protocol | / | CAN |
Baudrate | bps | 1M |
V1.0 Driver (MIT Version) Input Voltage | V | 24 |
V2.0 Driver (MIT Version) Input Voltage | V | 24-48 |
Communication Frequency | Hz | CAN:300Hz(1Mbps) |
Control Mode | / | Torque loop (40 kHz) / Speed loop (40 kHz) / Position loop (40 kHz) |
Resolution of the encoder on the driver | Bit | 12Bit |
Reducer end encoder accuracy | No | |
the second encoder on the output shaft | No | |
Can support separate encoder or not | / | Yes |
HT8115-J36 Characteristic Curves @ 36V
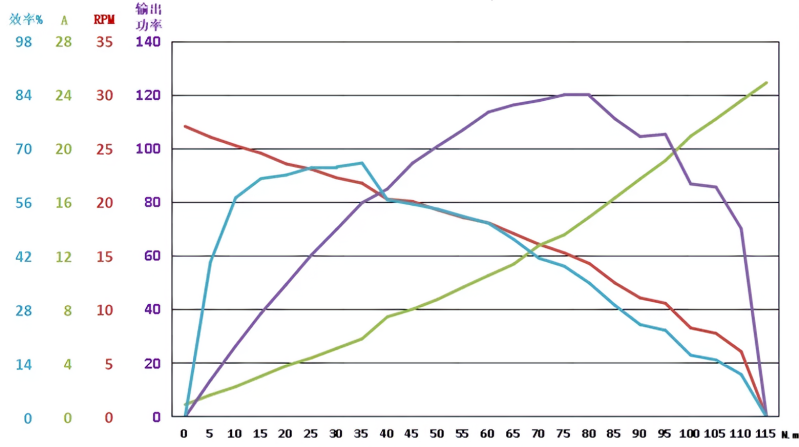
—Rotational speed—Electric current—Output power—efficiency
Motor Model | Unit | HT8115-J36 (formerly known as HT-04-36) |
Nominal voltage | V | 36 |
Voltage Range | V | 24~48 |
Power | W | 85 |
Nominal torque | N.M | 45 |
Stall torque | N.M | 115 |
Nominal Speed after reduce | RPM | 15 |
Max Speed after reduce | RPM | 36 |
Nominal current | A | 9.5 |
Stall current | A | 25 |
Phase to phase resitance | Ω | 0.54 |
Phase to phase inductance | mH | 0.262 |
Speed constant | rpm/v | 0.75 |
Torque constant | N.M/A | 4.80 |
Rotor inertia | gcm^2 | 61.60 |
Number of pole pairs | Pairs | 21 |
Gear Rate | / | 36:1 |
Gear type | / | Planetary |
Reducer gear material | / | STEEL |
Reducer gear backlash | arcmin | <6 |
Motor weight without driver | g | 920 |
Motor weight with driver | g | 960 |
Size without Driver | mm | Ø108*41 |
Size with Driver | mm | Ø108*51 |
Max.Axial load | N | 900 |
Max.Radial load | N | 1000 |
Noise | dB | <65 |
Protection grade | / | Only the motor has an IP54 protection rating. |
Working temperature | °C | -20~+80 |
MIT Open Source Driver Protocol | / | CAN |
CAN Baudrate | bps | 1M |
V1.0 Driver (MIT Version) Input Voltage | V | 24 |
V2.0 Driver (MIT Version) Input Voltage | V | 24-48 |
Communication Frequency | Hz | CAN:300Hz(1Mbps) |
Control Mode | / | Torque loop (40 kHz) / Speed loop (40 kHz) / Position loop (40 kHz) |
Resolution of the encoder on the driver | Bit | 12Bit |
Reducer end encoder accuracy | / | No |
the second encoder on the output shaft | / | No |
Can support separate encoder or not | / | Yes |
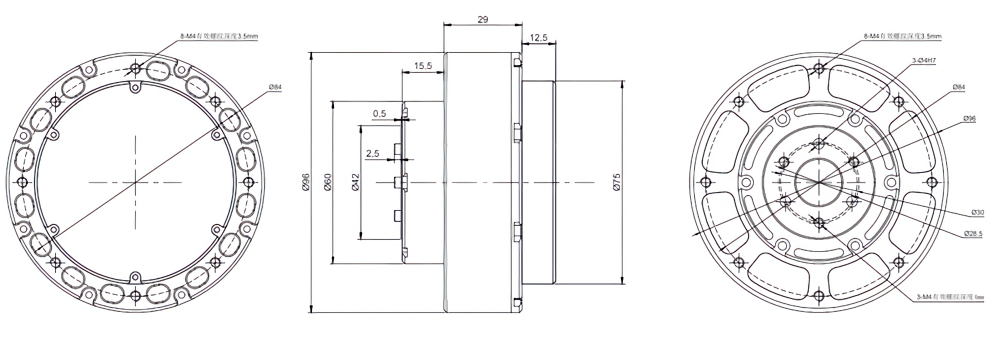
HT8108-J36 Motor Mounting Dimensions Drawing
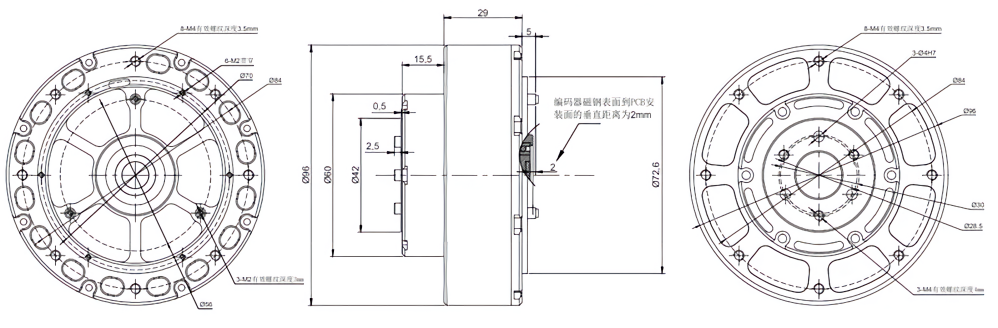
(No-drive state)
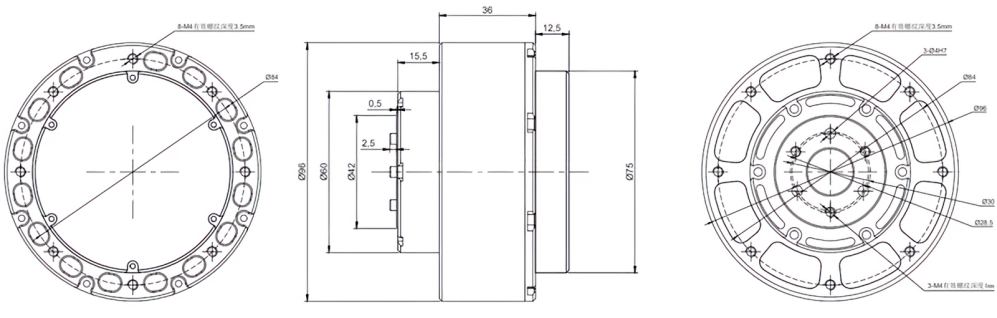
HT8115-J36 Motor Mounting Dimensions Drawing
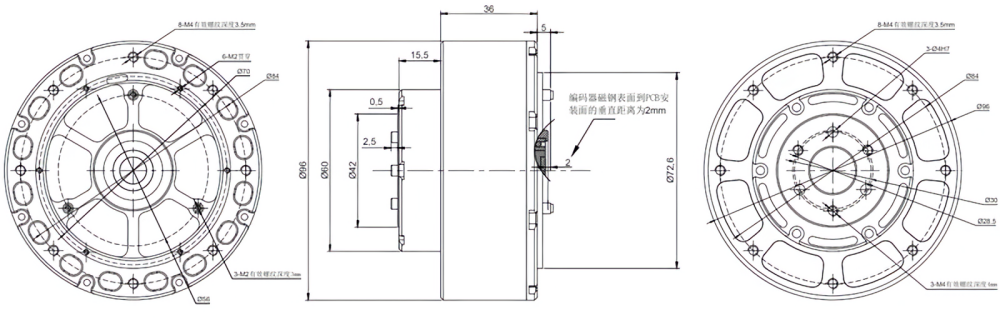
(No-drive state)
You can contact customer service to obtain the 2D and 3D files for the motor.