

Product Description
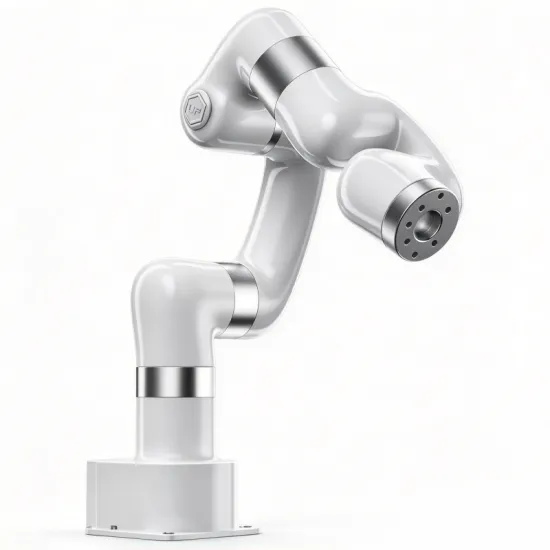
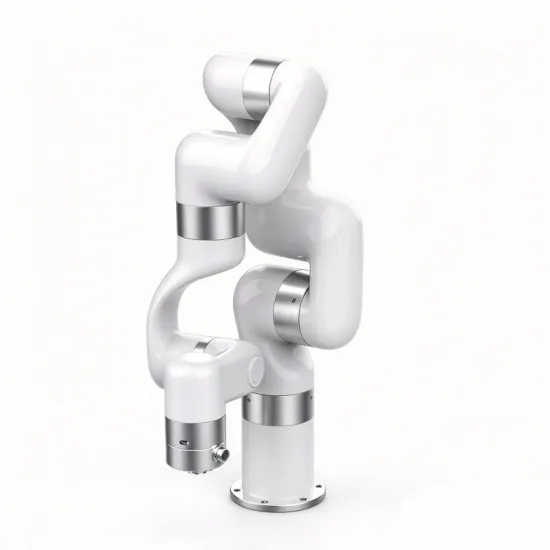
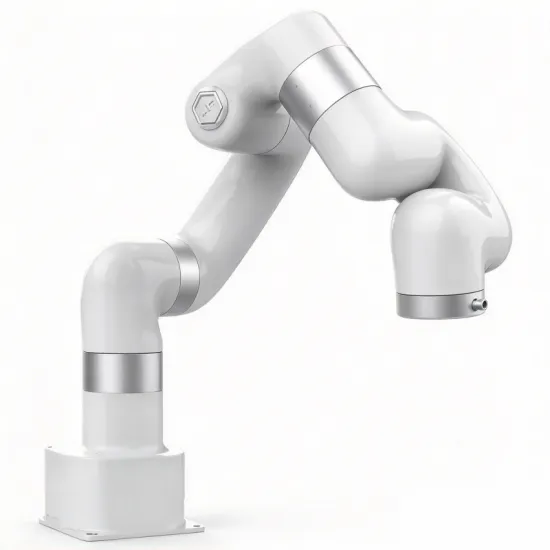
UFACTORY Lite6
Desktop 6-axis collaborative robot arm
Functional Features
Long-lasting and affordable
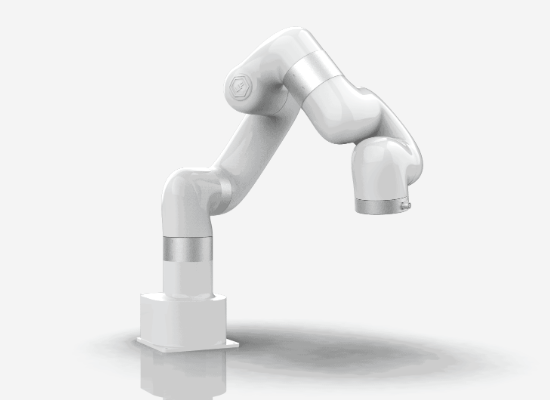
· Budget-friendly, saving your investment cost.
· Industrial-grade actuators for 24/7 operation.
· Built-in control box saves your workspace.
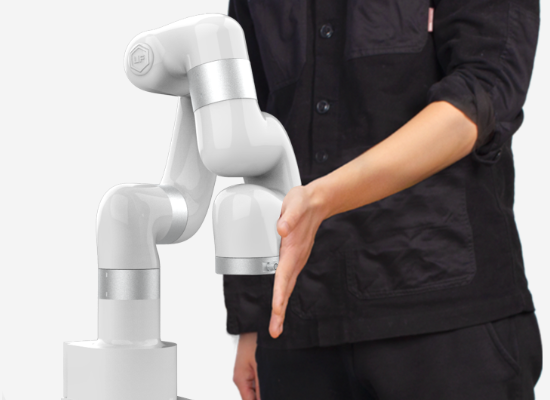
Flexible deployment, safe and reliable
· Light weight and compact size let you easily redeploy the robot to new applications without changing your production layout.
· Collision detection keeps you safe.
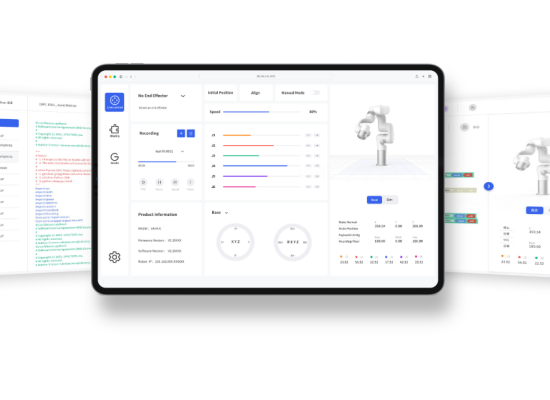
Easy programming, beginner friendly
· Compatible with macOS and Windows operating systems.
· Compatible with all mainstream browsers.
· Drag-and-drop code to make your robot move.
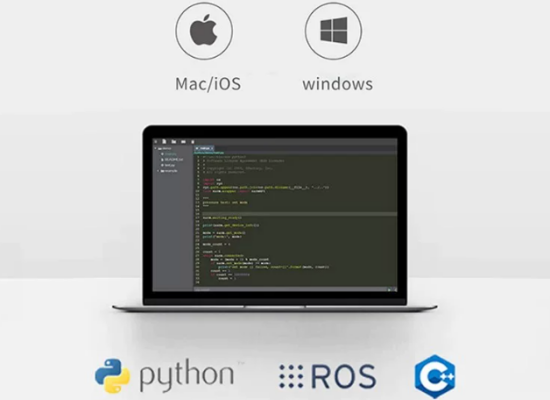
Free open-source software
· Free Python/C++ open-source software for more flexible programming.
· Sample code helps you deploy the robot arm smoothly.
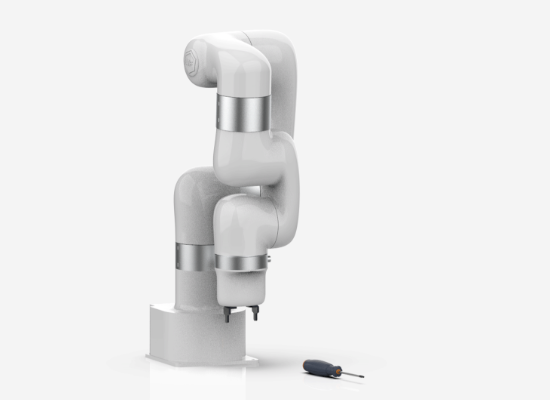
Effortless integration with official accessories
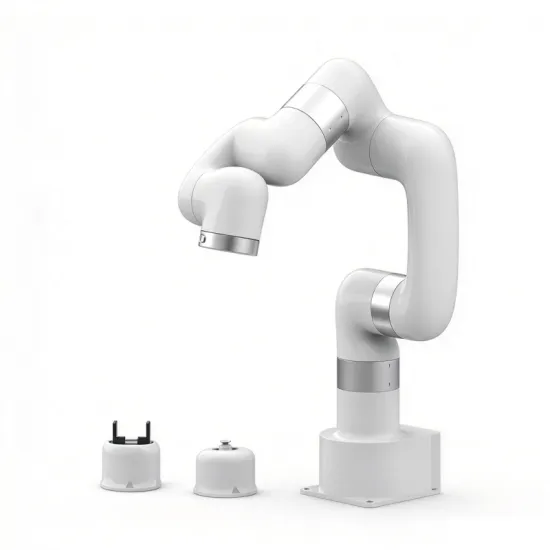
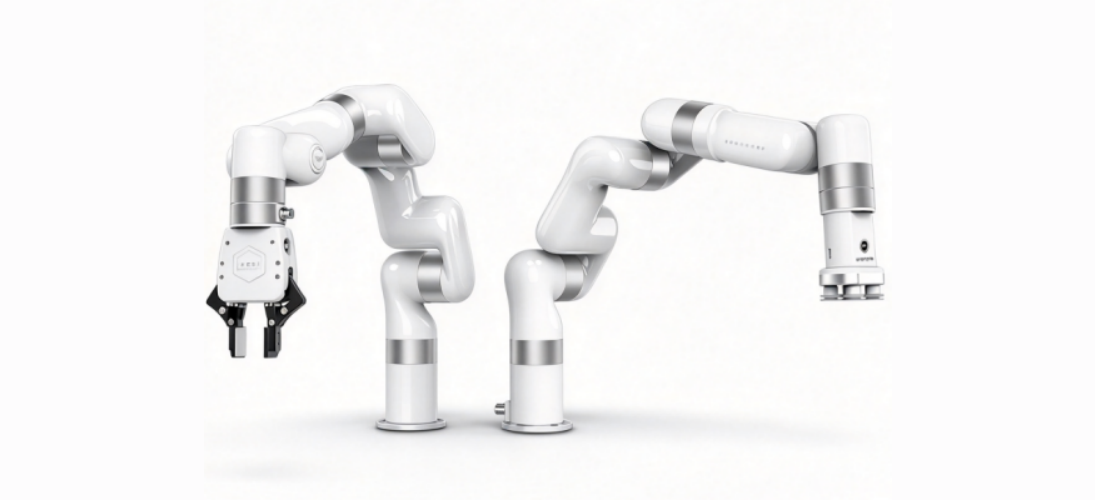
· Official accessories such as vacuum suction nozzles and grippers integrate seamlessly with the robot arm.
Application
Suitable for:
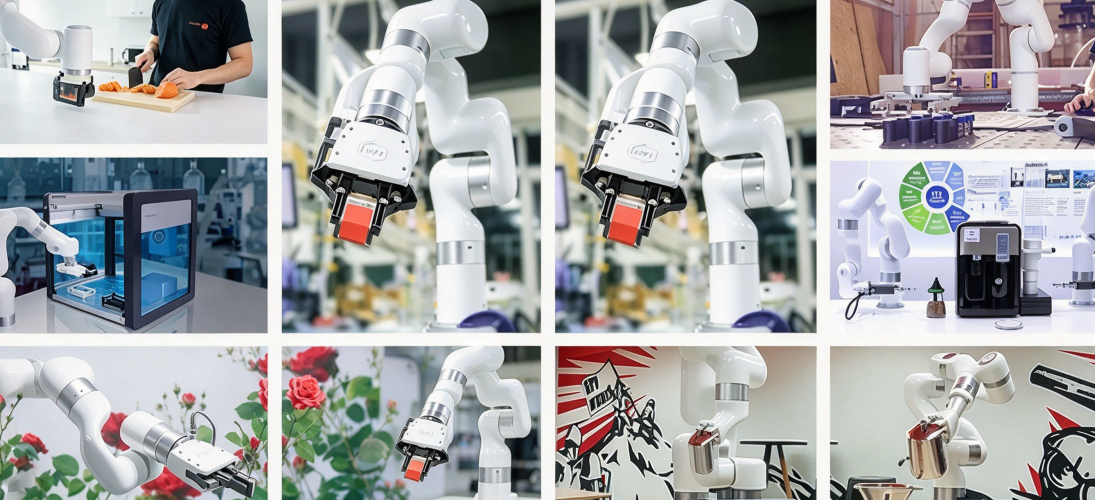
Lab automation·Robot research·Coffee machines·Screen testing
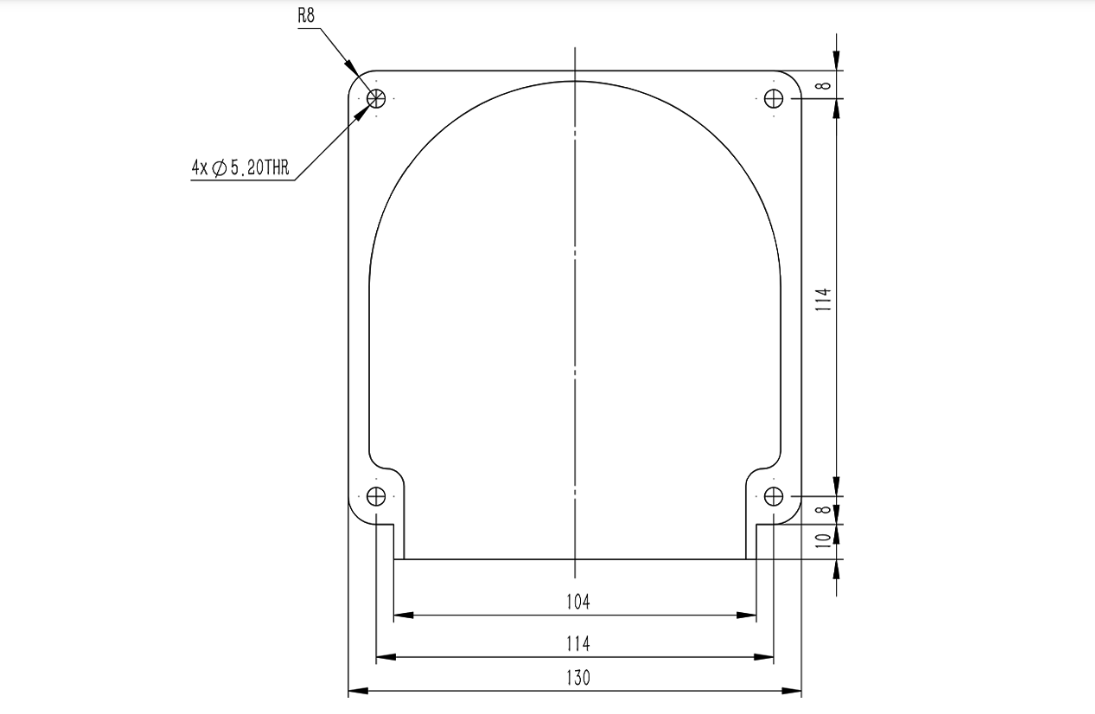
Dimensional Drawin
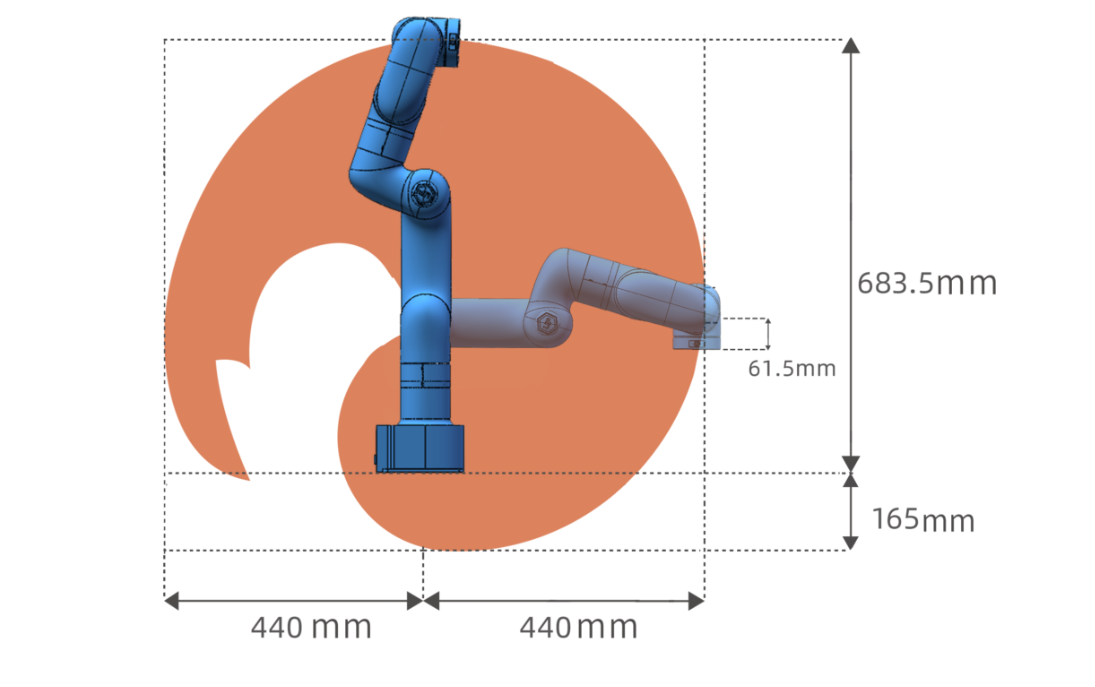
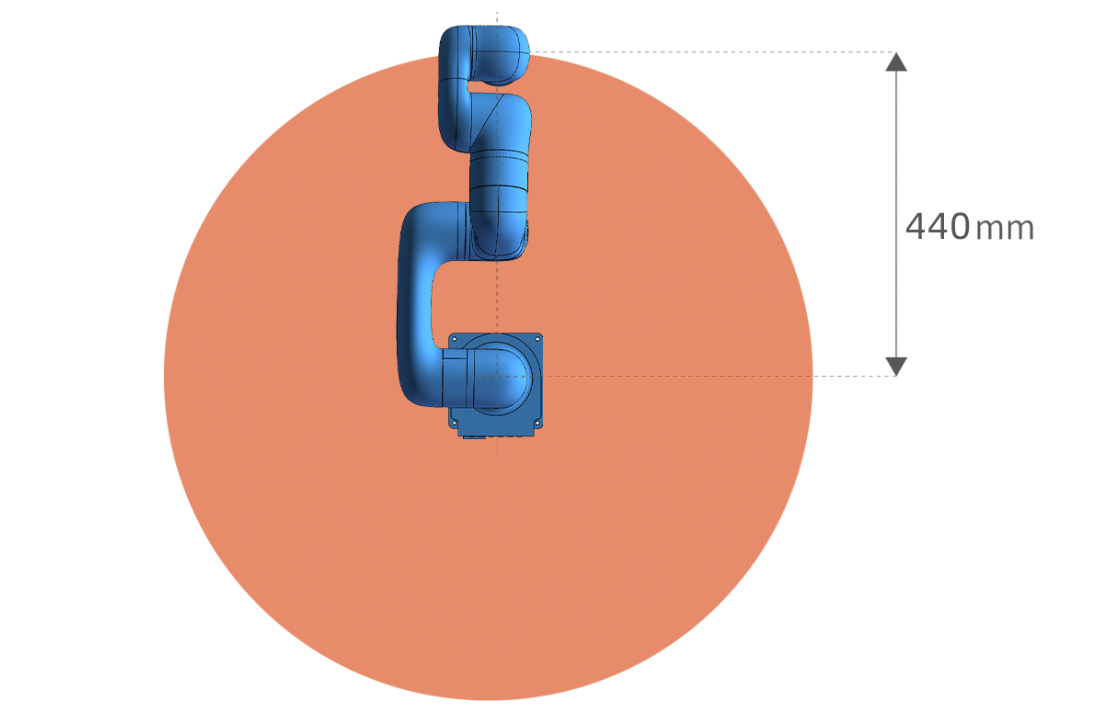
Working Range
Note: The following working range diagrams are only for safety assessment.
Dimension
Product parameters
Parameter | Value |
Performance | |
Operating temperature | 0-50 °C |
Power consumption | Typical 150 W, max 350 W |
Input power | 24 V DC, 14.66 A |
Repeatability | ±0.5 mm |
Specifications | |
Degrees of freedom | 6 |
Payload | 600 g |
Reach | 440 mm |
Communication | |
Arm communication protocol | Modbus TCP |
Communication | Ethernet, RS485 (master) ×1 |
Development environment | Python/C++/ROS/ROS2 |
Software | UFACTORY Studio |
I/O Ports | |
Control box | CI×8, CO×8, AI×2, AO×2 |
End-effector | TI×2, TO×2, AI×2/RS485×1 (either-or) |
Motion | |
Max joint speed | 180°/s |
Max end speed | 500 mm/s |
Physical Parameters | |
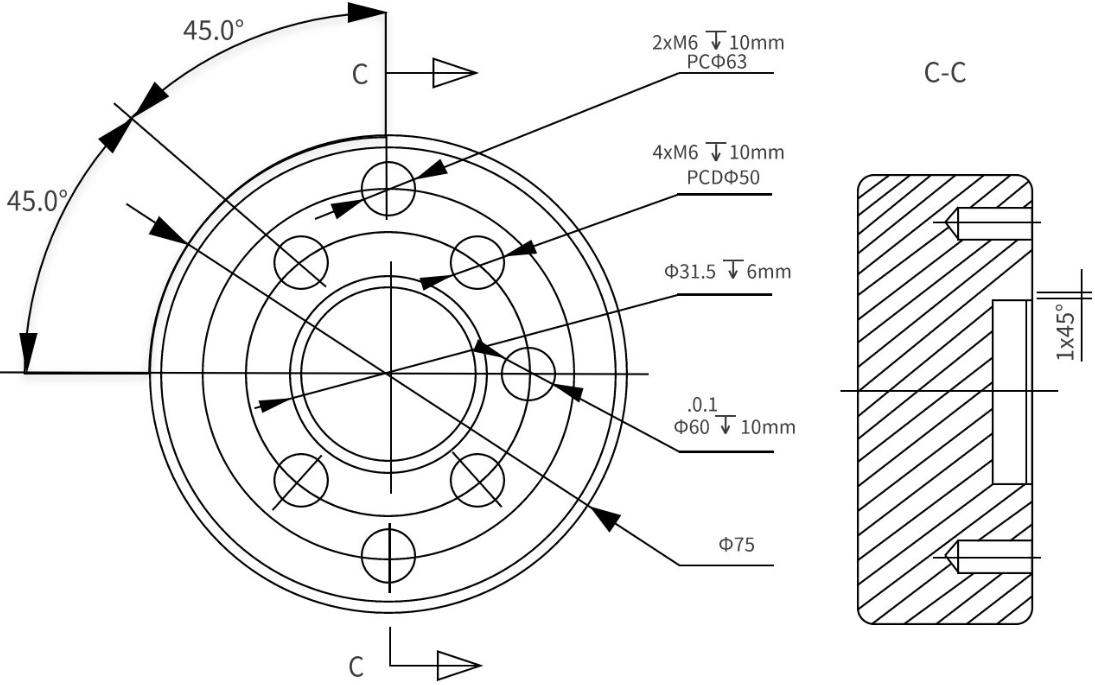
End flange | ISO 9409-1-50 |
Footprint | 130×140 mm |
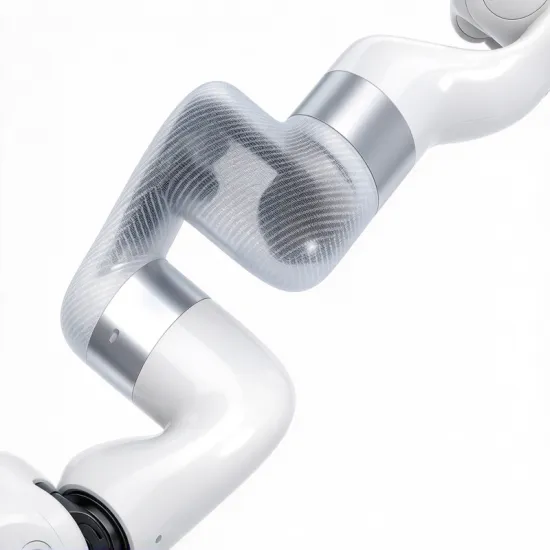
Material | Aluminum alloy, carbon fiber |
Base mounting holes | M5×4 (114×114 mm) |
Reducer | Harmonic Drive |
Motor type | BLDC |
Control box | Built-in |
Weight | 8 kg |
Joint Motion | |
Joint 1 | ±360°; 180°/s |
Joint 2 | ±150°; 180°/s |
Joint 3 | -3.5° to 300°; 180°/s |
Joint 4 | ±360°; 180°/s |
Joint 5 | ±124°; 180°/s |
Joint 6 | ±360°; 180°/s |