

|
|
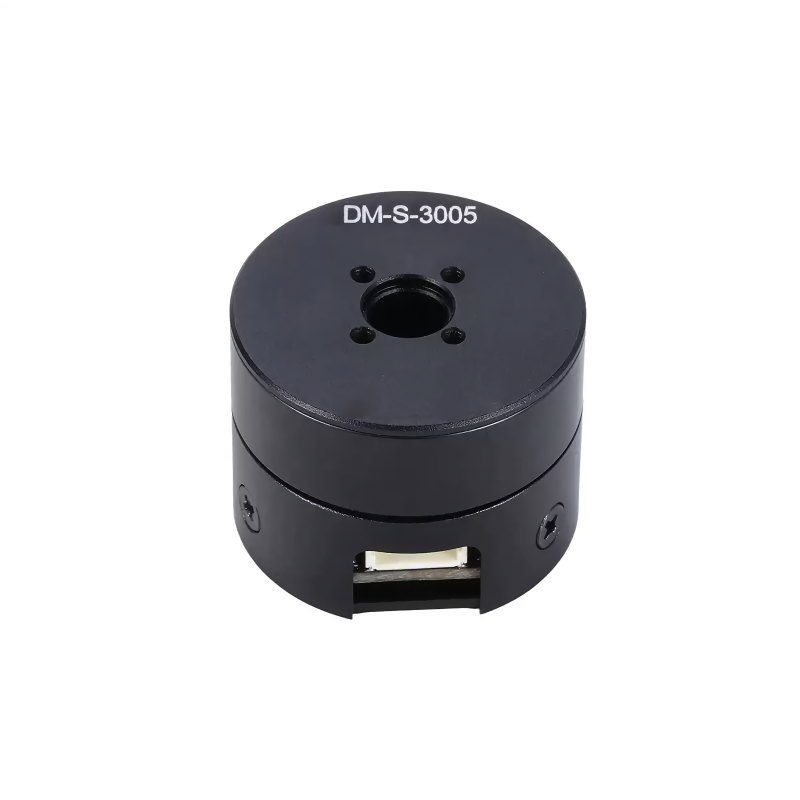
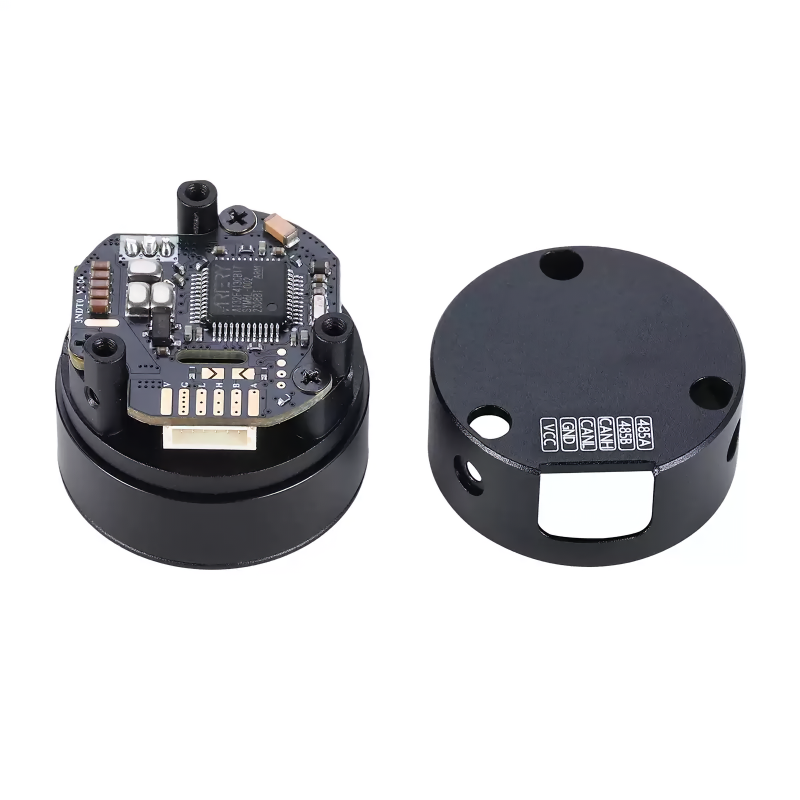
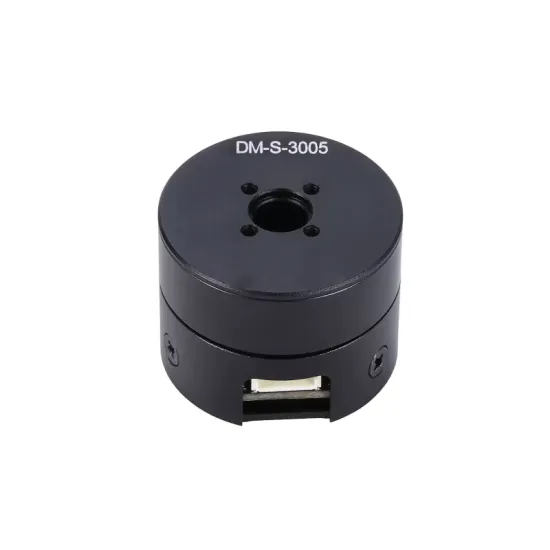
Parments | Unit | DM-S-3005 |
Nominal voltage | V | 12 |
Voltage Range | V | 10~28 |
Nominal current | A | 0.4 |
Nominal Power | W | 9.6 |
Nominal torque | N.M | 0.02 |
Nominal Speed | RPM | 800 |
No-load Max Speed | RPM | 6000 |
Peak torque | N.M | 0.05 |
Peak current | A | 1.9 |
Speed constant | rpm/v | 500 |
Torque constant | N.M/A | 0.023 |
Rotor inertia | gcm^2 | 21 |
Number of pole pairs | Pairs | 7 |
Phase resitance | Ω | 1.7 |
Phase inductance | mH | 0.24 |
Motor weight | g | 35 |
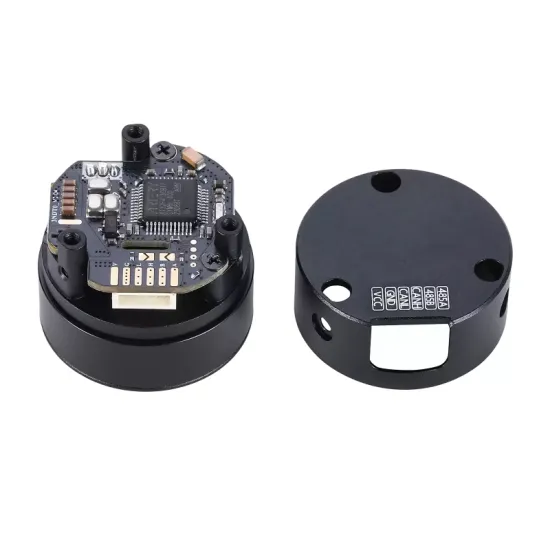
Communication | / | RS485/CAN |
Encoder type | / | Single-turn absolute value |
Resolution | bit | 14 |
Working temperature | °C | -20~80 |
Encoder magnetic steel inner diameter | mm | 5 |
Motor Size | mm | Φ28*22*Φ4 |
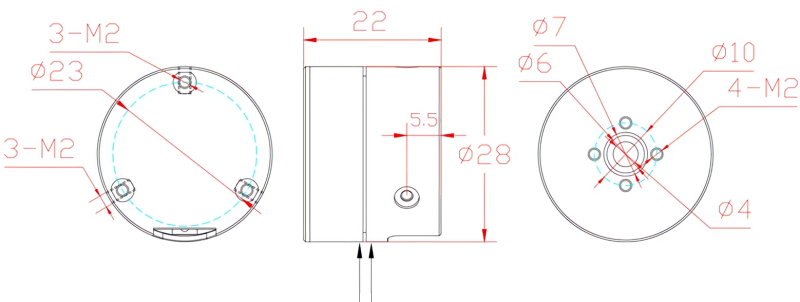
DM-S-3005 Motor Mounting Dimensions Drawing
| Rotor | stator |
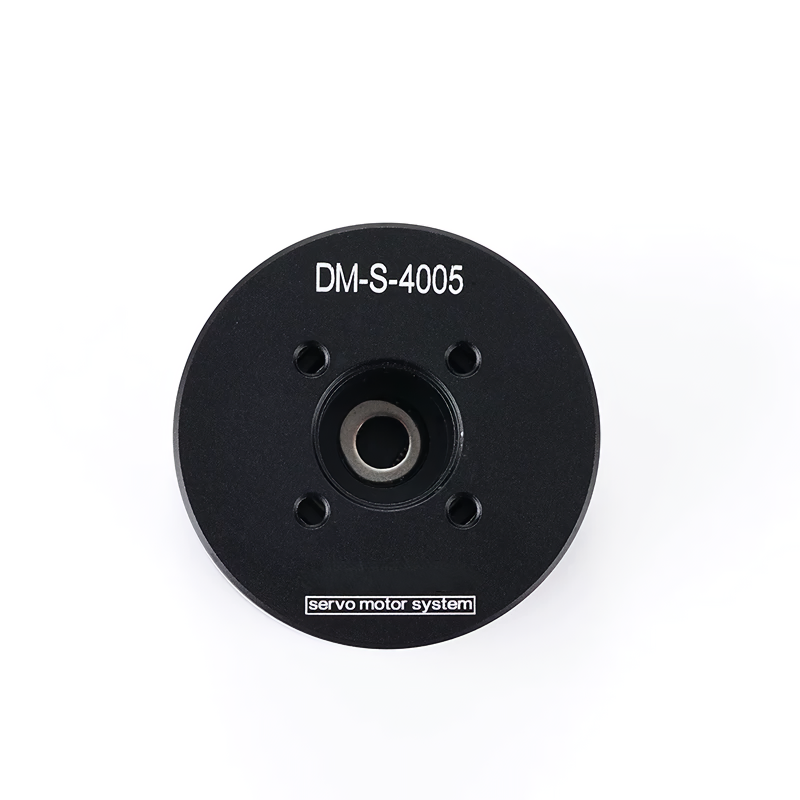
Host computer software
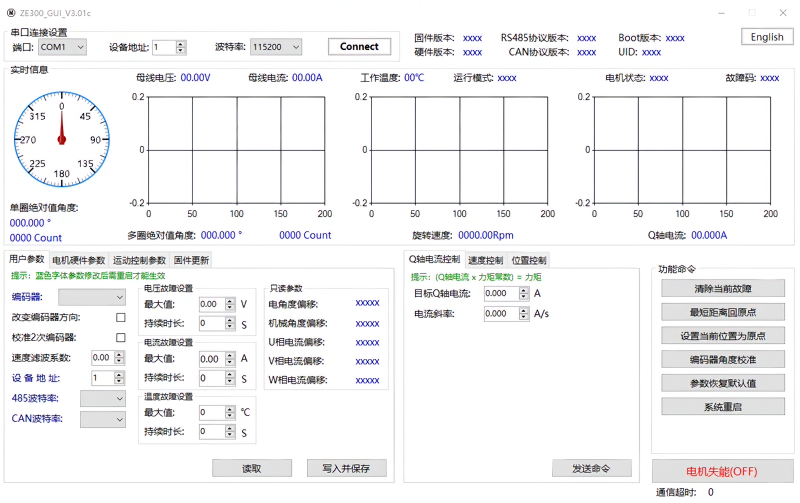
Motor Installation Dimension Drawing
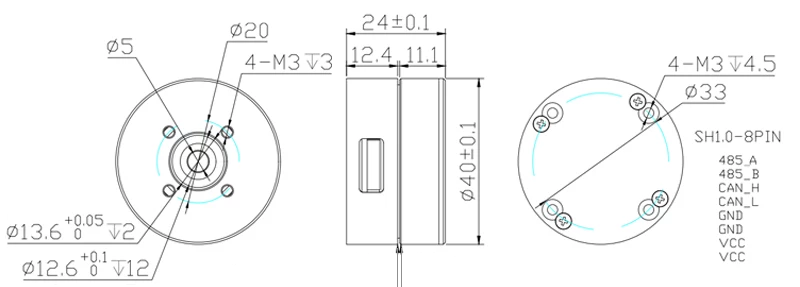
| stator | Rotor |
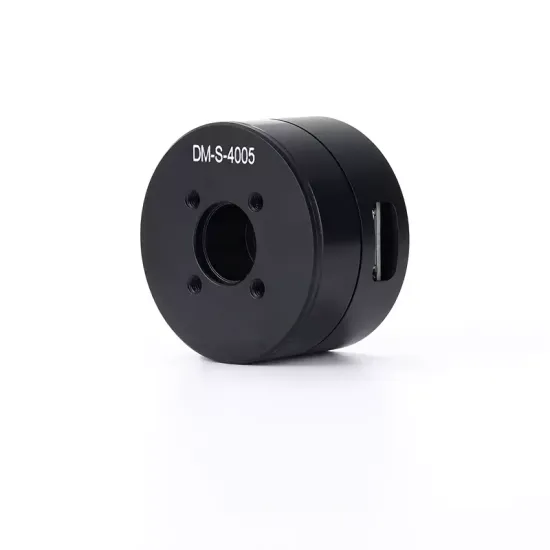
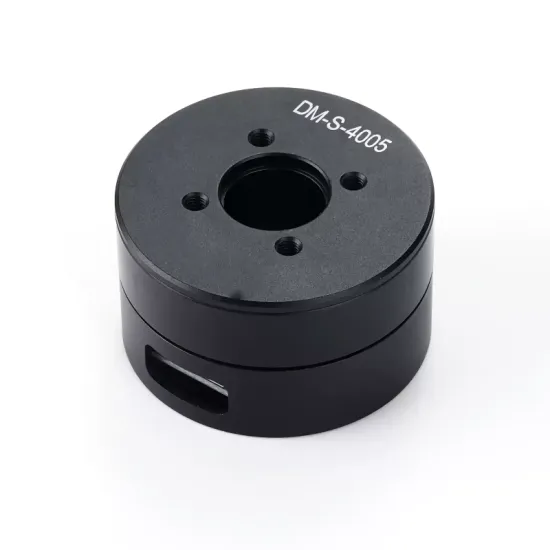
Parameters | Unit | DM-S-4005 |
Nominal voltage | V | 12 |
Voltage range | V | 10~28 |
Nominal current | A | 1.1 |
Nominal power | W | 13.2 |
Nominal torque | N.M | 0.09 |
Nominal speed | rpm | 467 |
No-load max speed | rpm | 1412 |
Peak torque | N.M | 0.15 |
Peak current | A | 1.9 |
Speed constant | rpm/v | 117 |
Torque constant | N.M/A | 0.08 |
Number of pole pairs | Pairs | 11 |
Phase resistance | Ω | 3.17 |
Phase inductance | Mh | 0.54 |
Rotor inertial | gcm^2 | 65 |
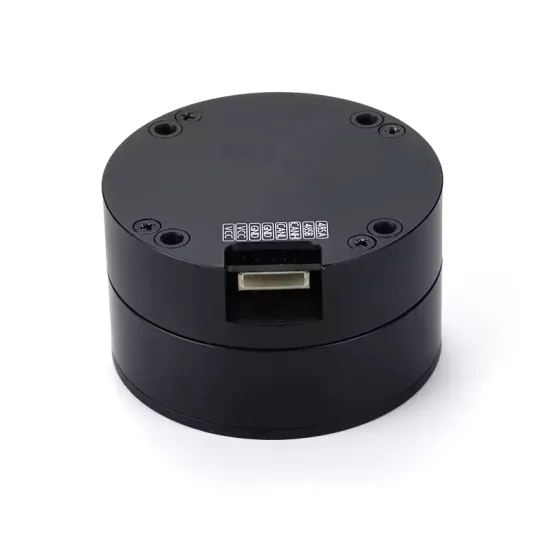
Communication | / | RS485/CAN |
Encoder type | / | Single-turn absolute |
Resolution | bit | 14 |
Motor weight | g | 70 |
Working temperature | °C | -20~80 |
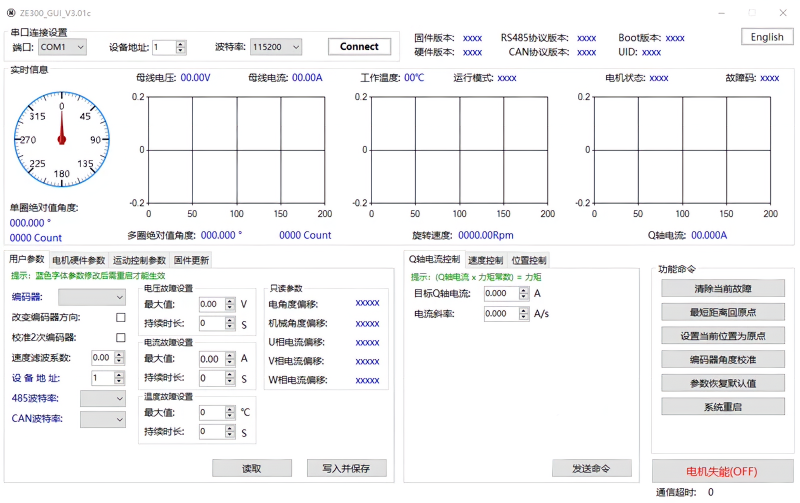
Host computer software
Motor Installation Dimension Drawing
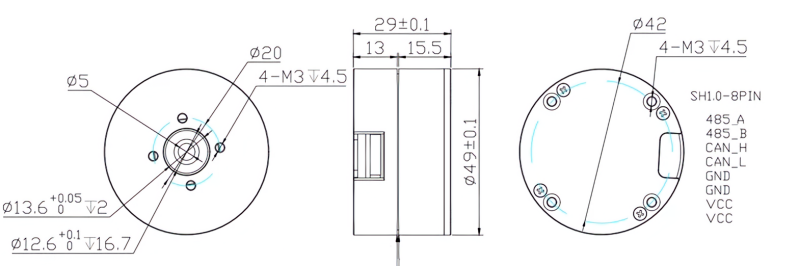
| stator | Rotor |
Parameters | Unit | DM-S-5010 |
Nominal voltage | V | 24 |
Voltage range | V | 10~28 |
Nominal current | A | 0.9 |
Nominal power | W | 21.6 |
Nominal torque | N.M | 0.2 |
Nominal speed | rpm | 504 |
No-load max speed | rpm | 828 |
Peak torque | N.M | 0.49 |
Peak current | A | 1.9 |
Speed constant | rpm/v | 34.4 |
Torque constant | N.M/A | 0.23 |
Number of pole pairs | Pairs | 14 |
Phase resistance | Ω | 5.16 |
Phase inductance | Mh | 1.63 |
Rotor inertial | gcm^2 | 195 |
Communication | / | RS485/CAN |
Encoder type | / | Single-turn absolute |
Resolution | bit | 14 |
Motor weight | g | 134 |
Working temperature | °C | -20~80 |
The product has a wide range of applications.
Widely used in legged robots, robotic arms, and SCARA robots.
|
|
|
| Humanoid robot | Robotic arm | Exoskeleton robots |
|
|
|
| Quadruped robot | AGV Smart Truck | ARU Robot |