

Product Description
Mini Pupper & MangDang An open-source robotics platform supporting ROS1 & ROS2 (Humble) and OpenCV.
Mini Pupper: Open-source, ROS & OpenCV Compatible
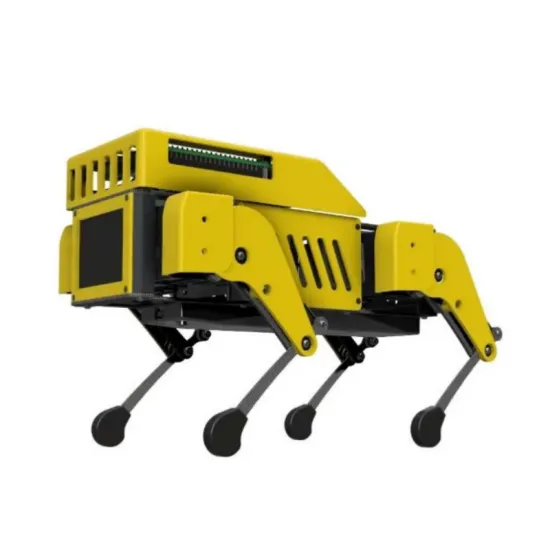
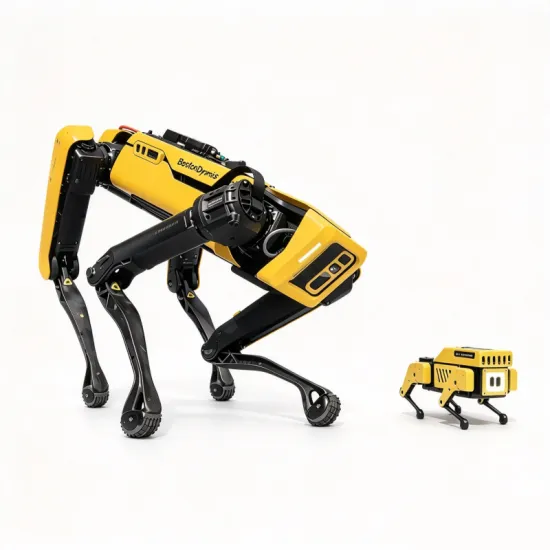
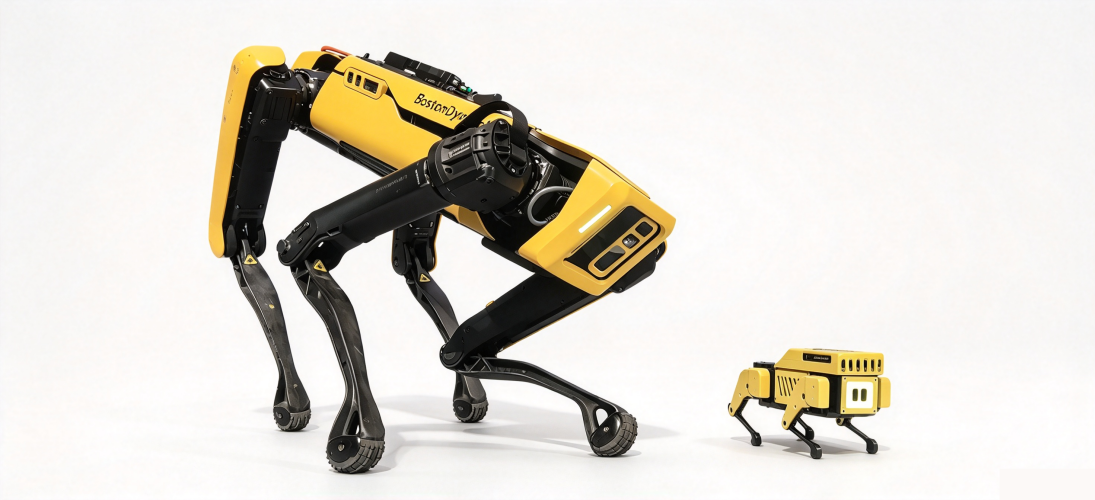
MangDang Mini Pupper is an upgraded version of Stanford Pupper.
It is independently developed by MangDang with strong support from Nathan of Stanford University.
It is a compact quadruped robot capable of running, jumping and roaming.
Its user-friendly design enables K12 and senior robotics enthusiasts to build a fun, movable quadruped robot by DIY.
After its launch on Kickstarter (the world’s largest crowdfunding platform) and Makuake (Japan’s leading crowdfunding platform), it was featured by dozens of renowned international media and TV stations, and has won widespread praise from customers.
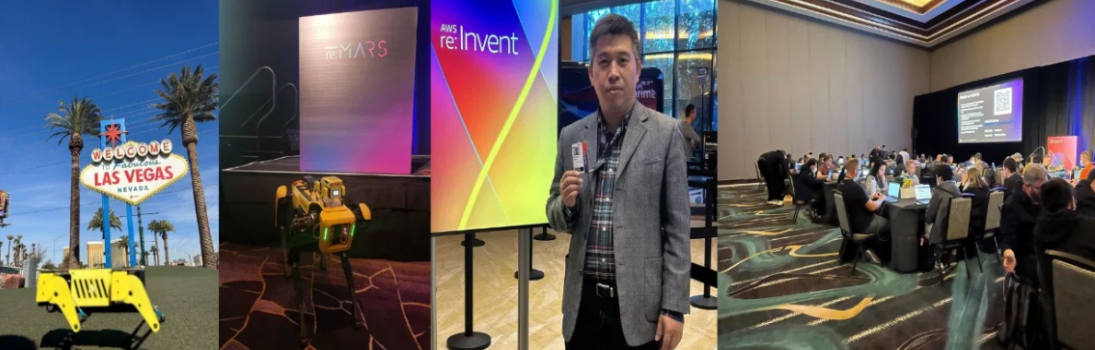
We have been invited to host workshops at many global exhibitions, including Amazon’s re:MARS and re:Invent in Las Vegas (USA), ROSCon hosted by ROS in Japan, and Ubuntu Summit held in Europe. It is highly recognized by users worldwide.
MangDang’s mission is to bring robots into ordinary households across the globe and make life better for everyone!
Functional Features
Intelligent "Hack Mode" Design
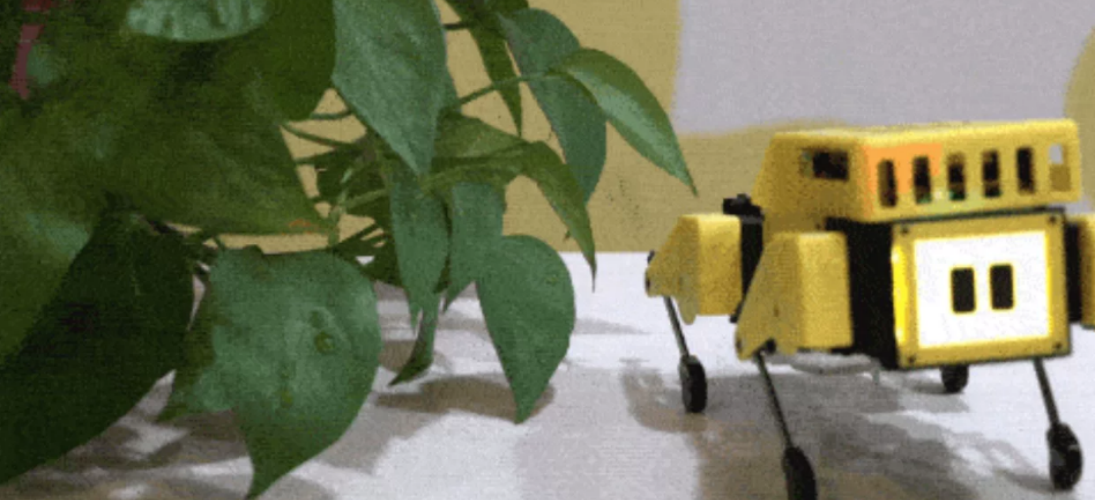
Users can adjust and extend robot behaviors according to their own needs.
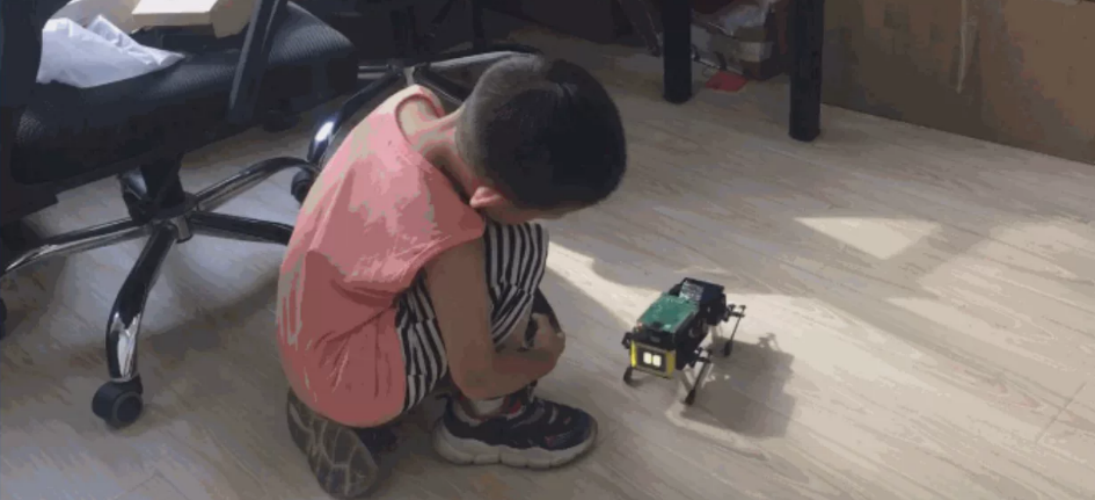
Mini Pupper is also a great helper for kids to learn robotics.
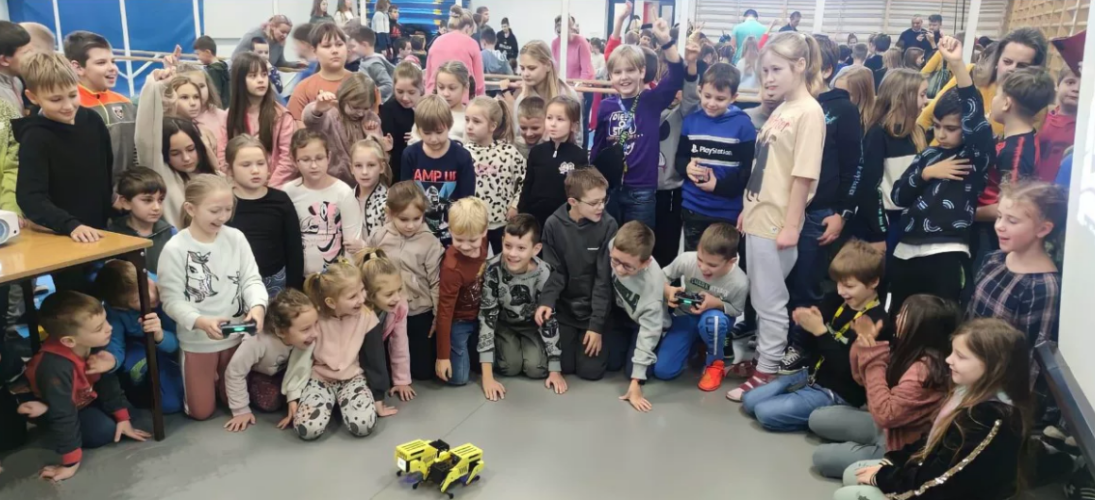
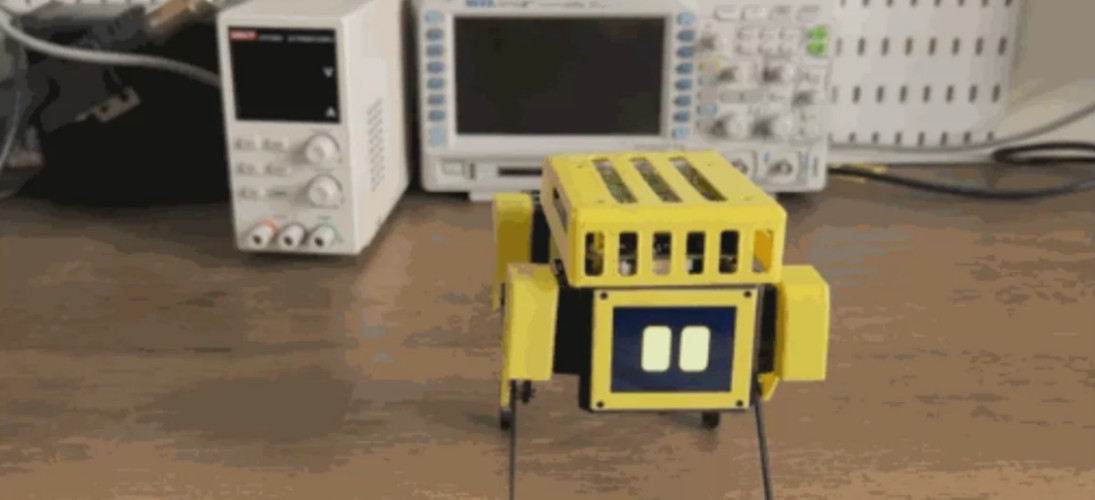
Open Source for Unlimited Creation
Supported features include diverse gaits (trot, run, etc.)
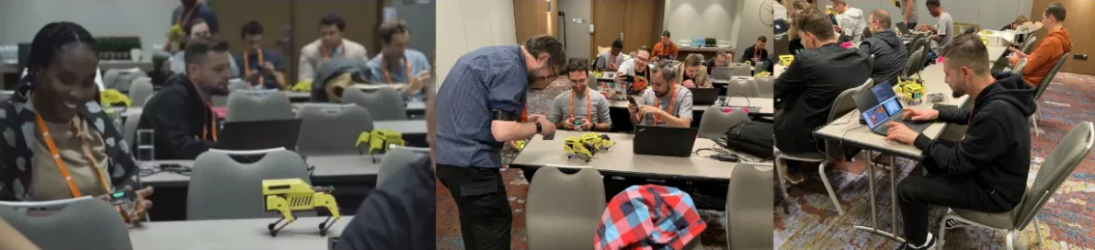
Mini Pupper Workshop Shines at Ubuntu Summit 2022
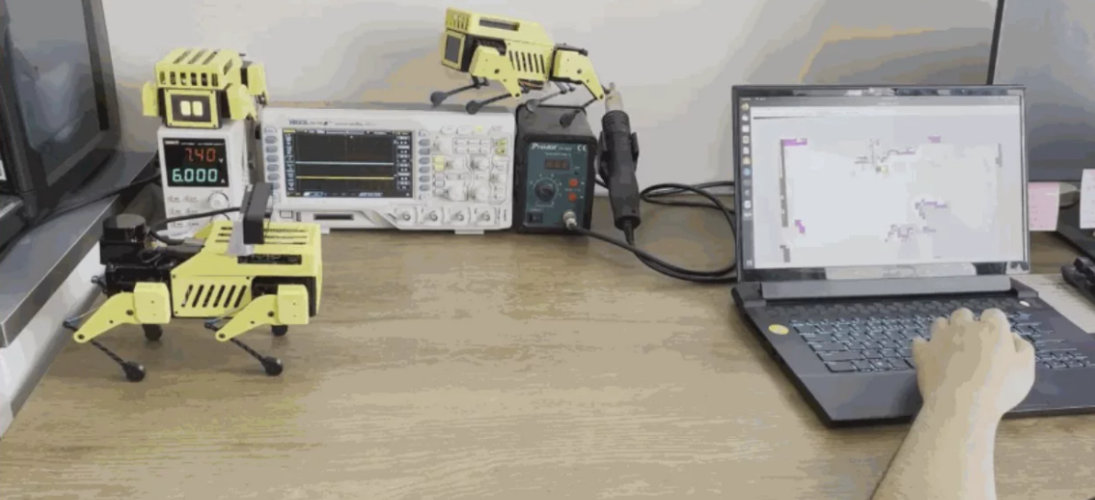
ROS SLAM & Navigation
Compatible with both ROS1 and the latest ROS2 Humble
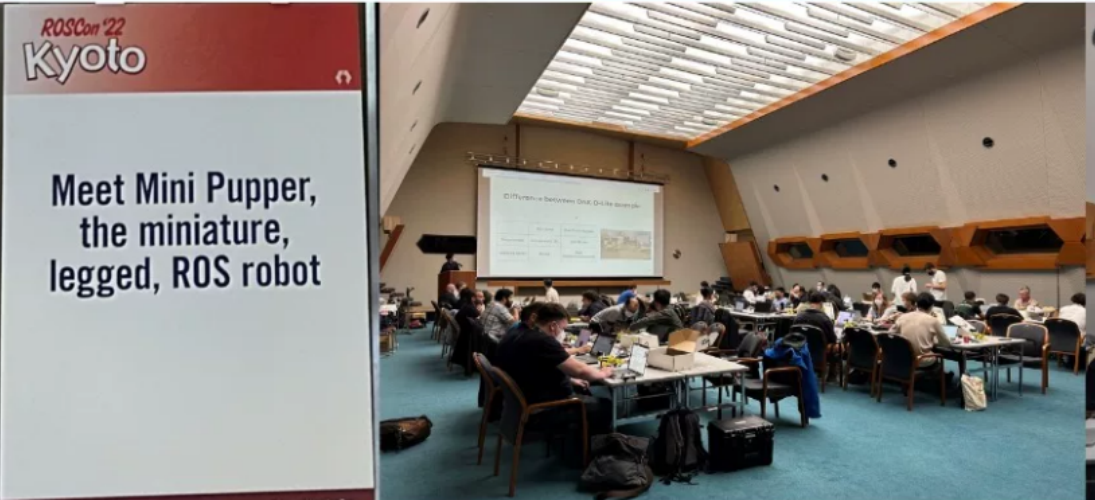
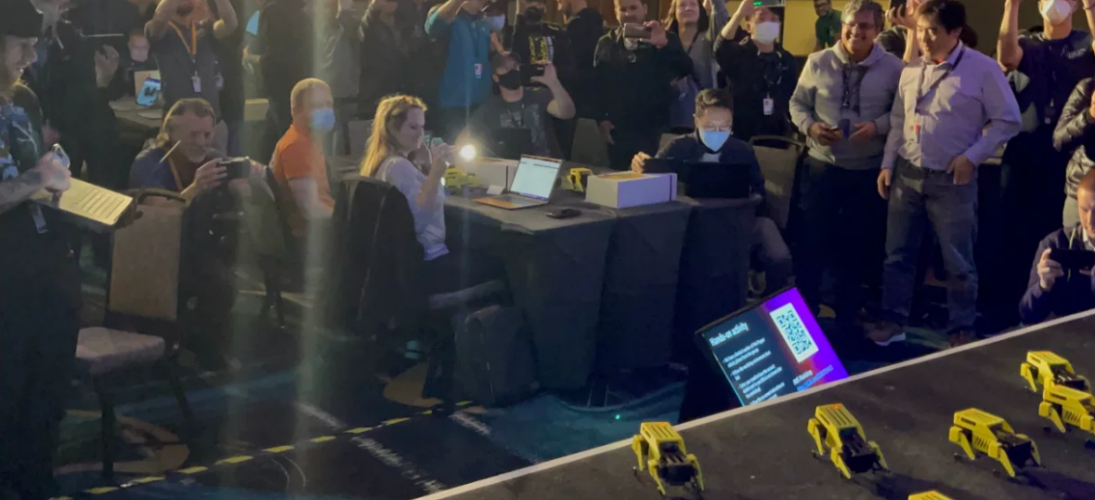
Mini Pupper Workshop at ROS Developers Conference 2022 Hosted by MangDang, we invited AWS, Luxonis and Japanese Makers to join us.
Thanks for the strong support from the official ROS team!
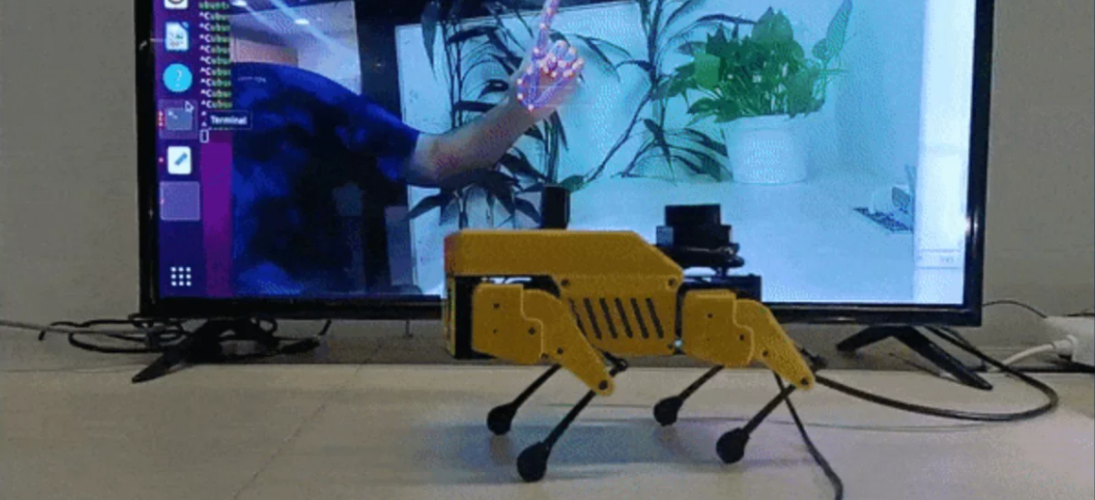
OpenCV Visual Artificial Intelligence
Unleash multiple potentials of AI
Discussed OpenCV AI features based on Mini Pupper with Satya (CEO of OpenCV) and Brandon (Person in charge of OpenCV AI Kit, CEO of Luxonis)
Sim-to-Real
AWS cloud service supported for easier learning……
At AWS re:MARS and re:Invent 2022, many enthusiasts enjoyed the fun of Sim-to-Real via Mini Pupper Workshop.
Product Display
Diverse Gameplays Waiting to Be Unlocked
Each leg is driven by 3 servos, with 12 degrees of freedom in total to realize various postures and movements.
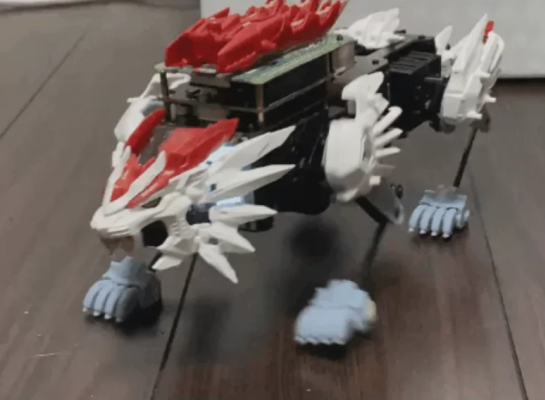
Change Its Shell by Itself
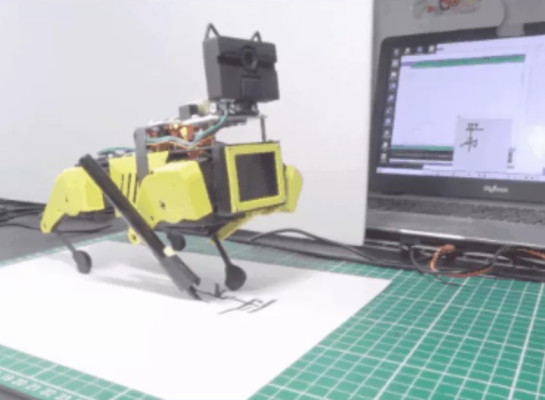
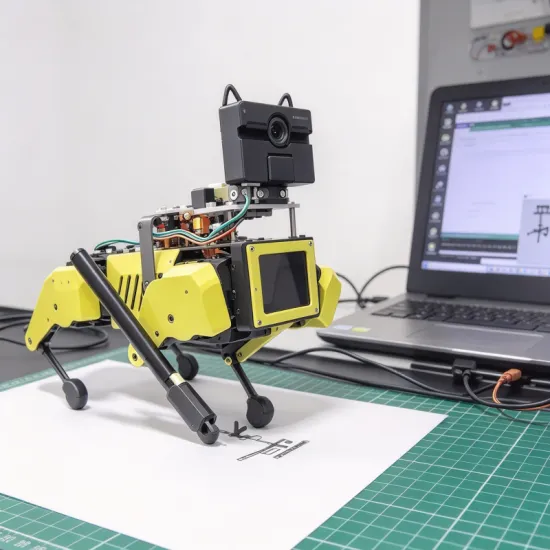
Learning to Write
Product parameters
Parameter | Value |
Dimensions | 209x165x145mm |
Weight | 560g |
Payload | 150g |
CPU | Raspberry Pi 4B |
Servo | Powerful PWM Servo |
Mic/Speaker | External modules |
I/O interfaces | Pi4B I/O interfaces |
USB3 | x2 |
USB2 | x2 |
HDMI output | x2 |
Gigabit Ethernet | x1 |
MCU | N/A |
IMU | N/A |
Touch sensor | N/A |
Reserved pins | Yes |
Screen | 320x240 |
Battery | 1000mAh |
OS | Ubuntu 22.04 |
ROS | ROS2 Humble |
Generative AI | ChatGPT@OpenAI / Gemini@Google / Claude@AWS / openClaw |
FAQ
1. Assembly
Documentation: https://minipupperdocs.readthedocs.io/en/latest/index.html Code: https://github.com/mangdangroboticsclub
2. Returns & Exchanges
This product is sold as unassembled parts. First-time users may leave marks during assembly which prevent resale. Returns or exchanges will NOT be accepted once the package is opened. If individual components get damaged during later use, replacement parts are available at the original component price.
3. One-on-one technical support?
We mainly provide online documentation. One-on-one technical support is not offered. Customers with limited assembly skills are advised to purchase the kit with caution.
4. Secondary development allowed?
Both software and hardware are fully open-source for secondary development. Great for quadruped robot enthusiasts!