Reverse Roller Screw: Motor-Integrated Actuator Delivering Hydraulic-Level Thrust
Roller screws are often considered the standard planetary gear design, but in reality, several variations exist, including differential, cyclic, and inverted types. Each design has its own advantages in terms of performance—load capacity, torque, and positioning accuracy—but the main advantage of inverted roller screws lies in their ease of integration into actuators and other sub-components.

Standard roller screws (also known as planetary roller screws) use threaded rollers with teeth at the ends that mesh with gear rings at both ends of the nut. In inverted roller screws, the functions of the screw and nut are interchanged, or reversed. The nut is essentially a threaded tube with a length equal to the stroke length, instead of just enough to accommodate the rollers and meshing gear rings. Furthermore, the screw shaft is not threaded along its entire length; it is the same length as the roller.
For an inverted roller screw, the nut length determines the stroke, while the threaded portion of the screw is only equal to the roller length.
Therefore, when the screw shaft rotates, the nut and roller do not translate along the length of the screw, but remain axially stationary on the screw (i.e., the roller and nut do not move along the length of the screw). Conversely, rotating the screw shaft causes the roller—and the screw itself—to translate along the length of the nut. Alternatively, with the design of an inverted roller screw, the nut can be driven and the screw (and roller) can be kept axially stationary.
Since the gear ring, which is usually located at the end of the nut, is now moved to the end of the threaded portion of the screw, the nut diameter can be slightly smaller than that of a planetary roller screw of the same size. While machining threads inside a relatively long nut body can be challenging, reverse roller screws can have fewer thread initiation points than standard planetary roller screws. This means they can use larger threads, providing a higher load-carrying capacity than standard designs.
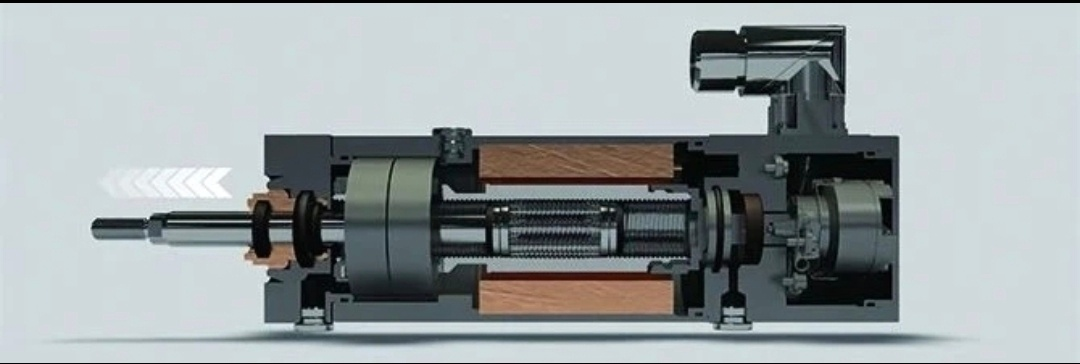
Reverse roller screws are well-suited for pushrod actuators, where the pushrod extends and retracts from the actuator housing. Because most of the screw shaft is unthreaded (only the portion containing the rollers is threaded), the shaft can be customized to meet actuator design and application requirements. The reverse design also allows actuator manufacturers to relatively easily attach magnets to the roller screw nut and use it as the rotor of an integrated motor-screw assembly.
The roller ends of reverse or inverted planetary roller screws also have gears, but these gears mesh with gears on the screw shaft (rather than meshing with gears at the nut end as in standard products). This allows the rollers to move axially within the nut, thus requiring an extended nut to accommodate the entire stroke of the assembly. In effect, the nut is essentially a long tube with a threaded inner diameter. Because the roller array is always fixed to a small section of the lead screw shaft, only this small section is threaded; the rest of the lead screw shaft is smooth steel or other material bar stock. Depending on the motor connection and design, the output can be from either the lead screw shaft or the nut.
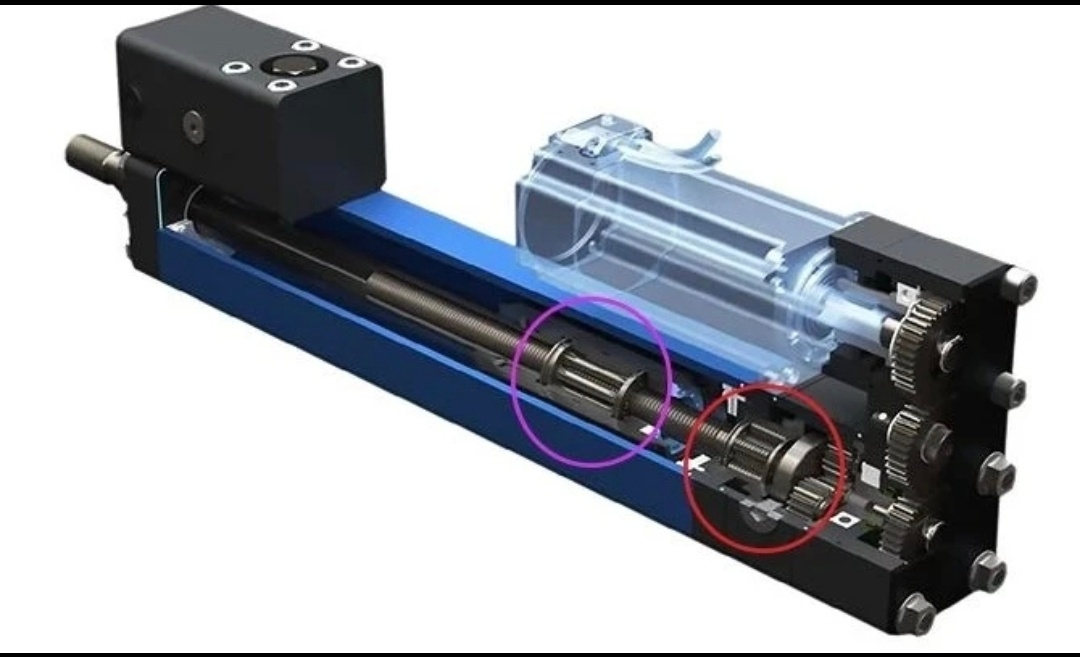
Inverted roller screws can be more expensive than other types of roller screws because precision threading is required within the long inner diameter of the nut. In some cases, these threads are also relatively less stiff, which can reduce the rated load to some extent; furthermore, they may require special lubrication procedures. However, inverted screws are generally more compact than other roller screw designs.
Other standard roller screw actuators, which prioritize compactness, fix the motor magnet to the outer diameter of the nut. The motor stator windings are then incorporated into the inner diameter of the actuator housing, surrounding the nut and interacting electromagnetically with the magnet. This, in turn, drives the nut to rotate, which in turn propels the actuator shaft forward via the rollers.
While manufacturers often tout the compactness of inverted roller screws as their primary advantage, the ability to customize the threadless portion of the screw shaft gives them a significant advantage over other screw designs for pushrod actuator applications.
In high-force applications, actuators using ball screws or roller screws offer numerous advantages over hydraulic actuators. These advantages include higher energy efficiency, better accuracy and repeatability, smaller system footprint, lower operating noise, less environmental impact, lower maintenance costs, lower lifecycle costs, and the potential to increase throughput and reduce unit costs through process improvements.
Higher Energy Efficiency – Electric actuator systems typically achieve efficiencies between 75% and 80%. In contrast, pneumatic systems typically achieve efficiencies between 10% and 25%. Hydraulic systems typically achieve efficiencies between 40% and 55%. Many factors affect hydrodynamic efficiency, including temperature, seal integrity, leakage, and more. An important factor is that electric actuators only supply power to the drive motor when needed. When stationary, electric actuators require only a tiny current to maintain their position. Hydraulic actuators, on the other hand, require a power unit or compression system to constantly pressurize the fluid medium, resulting in low energy efficiency. Over time, energy savings significantly improve.
Higher Precision and Repeatability – Actuators using electric ball screws or roller screws offer significant advantages in applications requiring precise control of motion and position. Standard hydraulic actuators are suitable for end-to-end positioning applications, but mid-range positioning is more complex, requiring control valves and operator assistance. More advanced servo hydraulic control systems can provide higher precision and repeatability for hydraulic systems, but cost and complexity increase significantly. Electric actuator systems are much simpler, requiring almost no manual intervention or maintenance once programmed.
Quiet Operation – Noisy power units operating hydraulic cylinders can cause noise pollution and pose hazards to operators working near the machine.
Minimal Environmental Impact – Hydraulic system leaks can create a messy production environment and pose safety hazards if someone slips on the leak. Pneumatic system leaks generate noise and waste energy. Hydraulic leaks can cause serious contamination of critical processes and products, such as in the food processing, pharmaceutical, and medical device industries. Electric actuator systems, however, do not have these drawbacks.
Smaller System Footprint – Electric actuator systems are not only energy-efficient but also space-saving. Hydraulic systems require cylinders, a power unit to provide hydraulic pressure, control valves, filters, and many other components. Electric systems require only the actuator itself and a control cabinet – which can typically be conveniently placed near the point of use.
Extremely Low Maintenance – Properly sized electric actuators generally require almost no maintenance. In applications with higher performance requirements, electric actuators may require some maintenance, such as degreasing, but this is usually an infrequent, simple, and inexpensive procedure. While hydraulic units are generally robust and easy to deploy, they require significant maintenance as a trade-off. Seal leaks can contaminate the work area and reduce working power. Additional air and oil maintenance is also required to prevent moisture or contaminants from prematurely damaging seals and other components in the system.
Enabling Process Improvements – In many applications, electric actuators cycle faster than hydraulic cylinders. For example, a hydraulic lever actuator may need to move six inches forward or backward. Perhaps an application only requires a six-inch stroke for setup, while production operations only require three inches. However, hydraulic actuators have poor positioning capabilities, moving only six inches forward or backward, wasting time with each cycle. Electric actuators, with precise position control, can be programmed to perform three-inch production runs, saving time and increasing production efficiency.
Compared to hydraulic systems, electric actuator systems have lower lifecycle costs—although electric actuator systems are twice as efficient as hydraulic systems, their initial deployment costs may be higher. However, when considering performance improvements, increased system flexibility, reduced maintenance costs, process improvements, and lower utility costs, the overall lifecycle cost can be significantly lower.
video demonstration